anninrobotics/ar4 · spec sheet
Annin AR4 specs
Open-plan, low-cost 6-DOF desktop industrial-style robot arm by Chris Annin, programmable via its HMI, Python or ROS.
Media
3 items · credited and licensed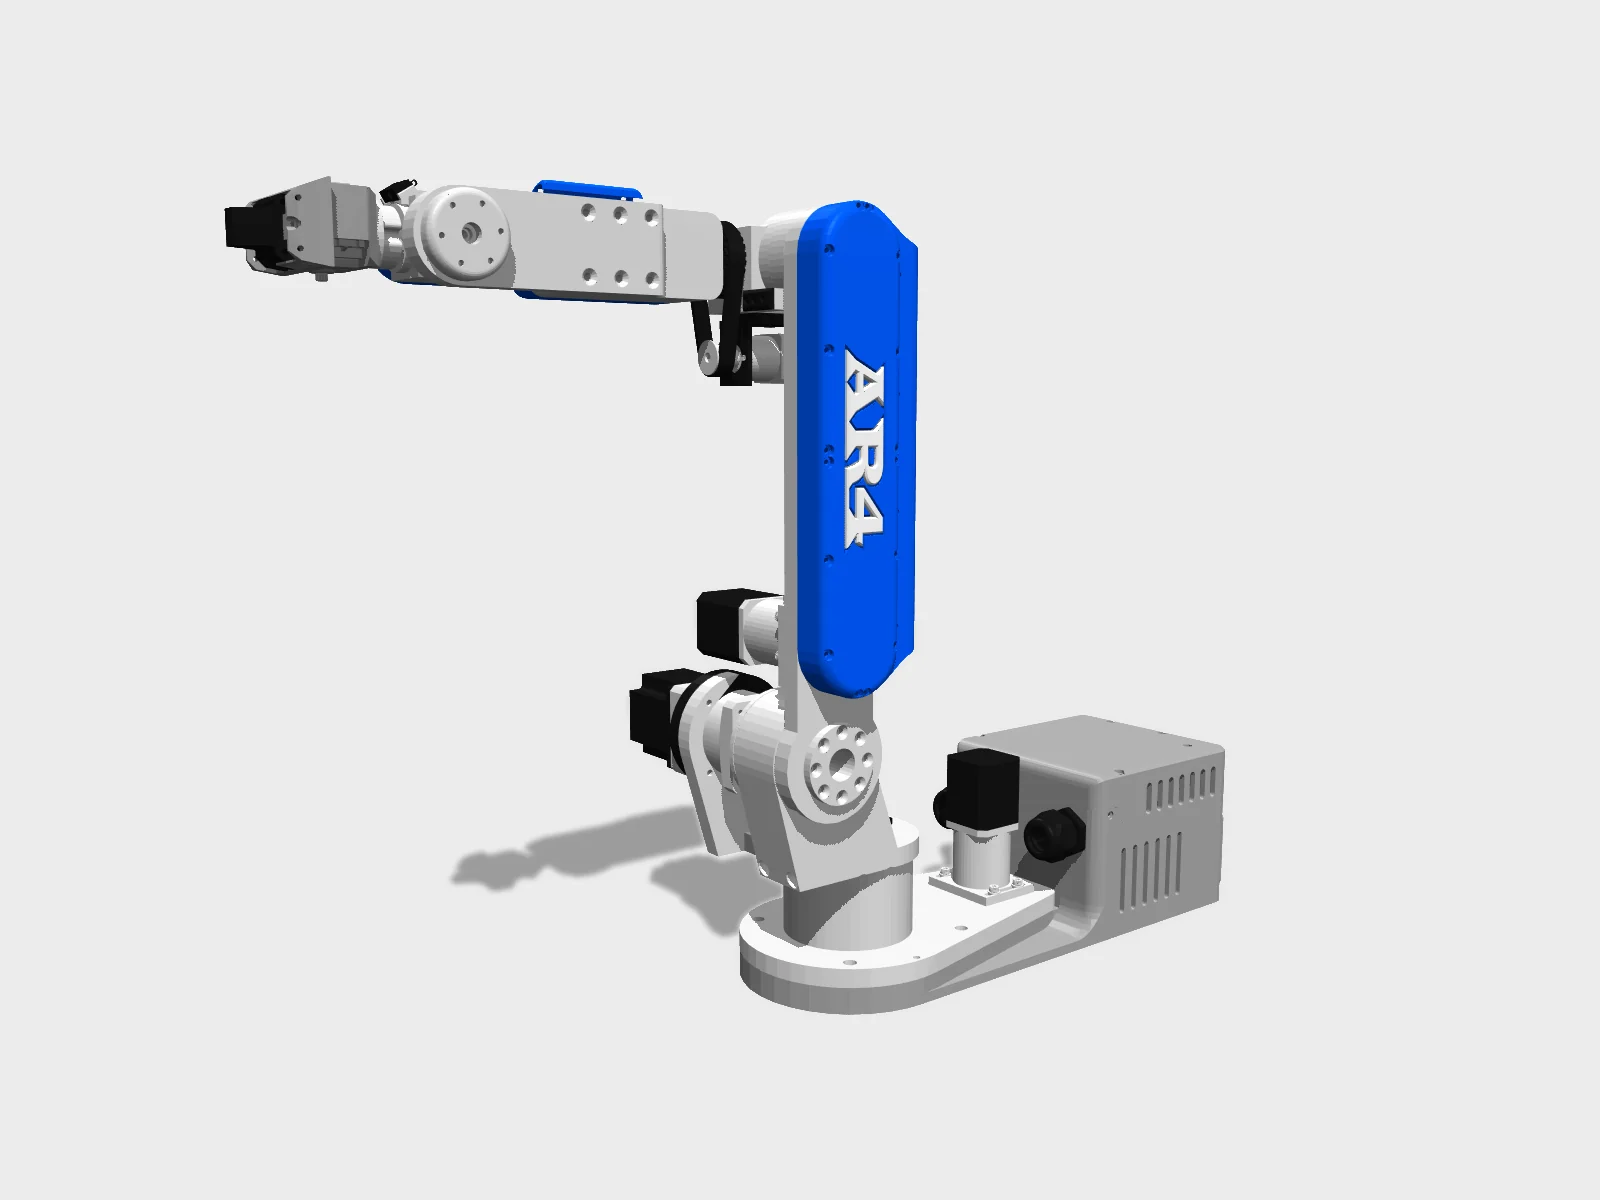 render
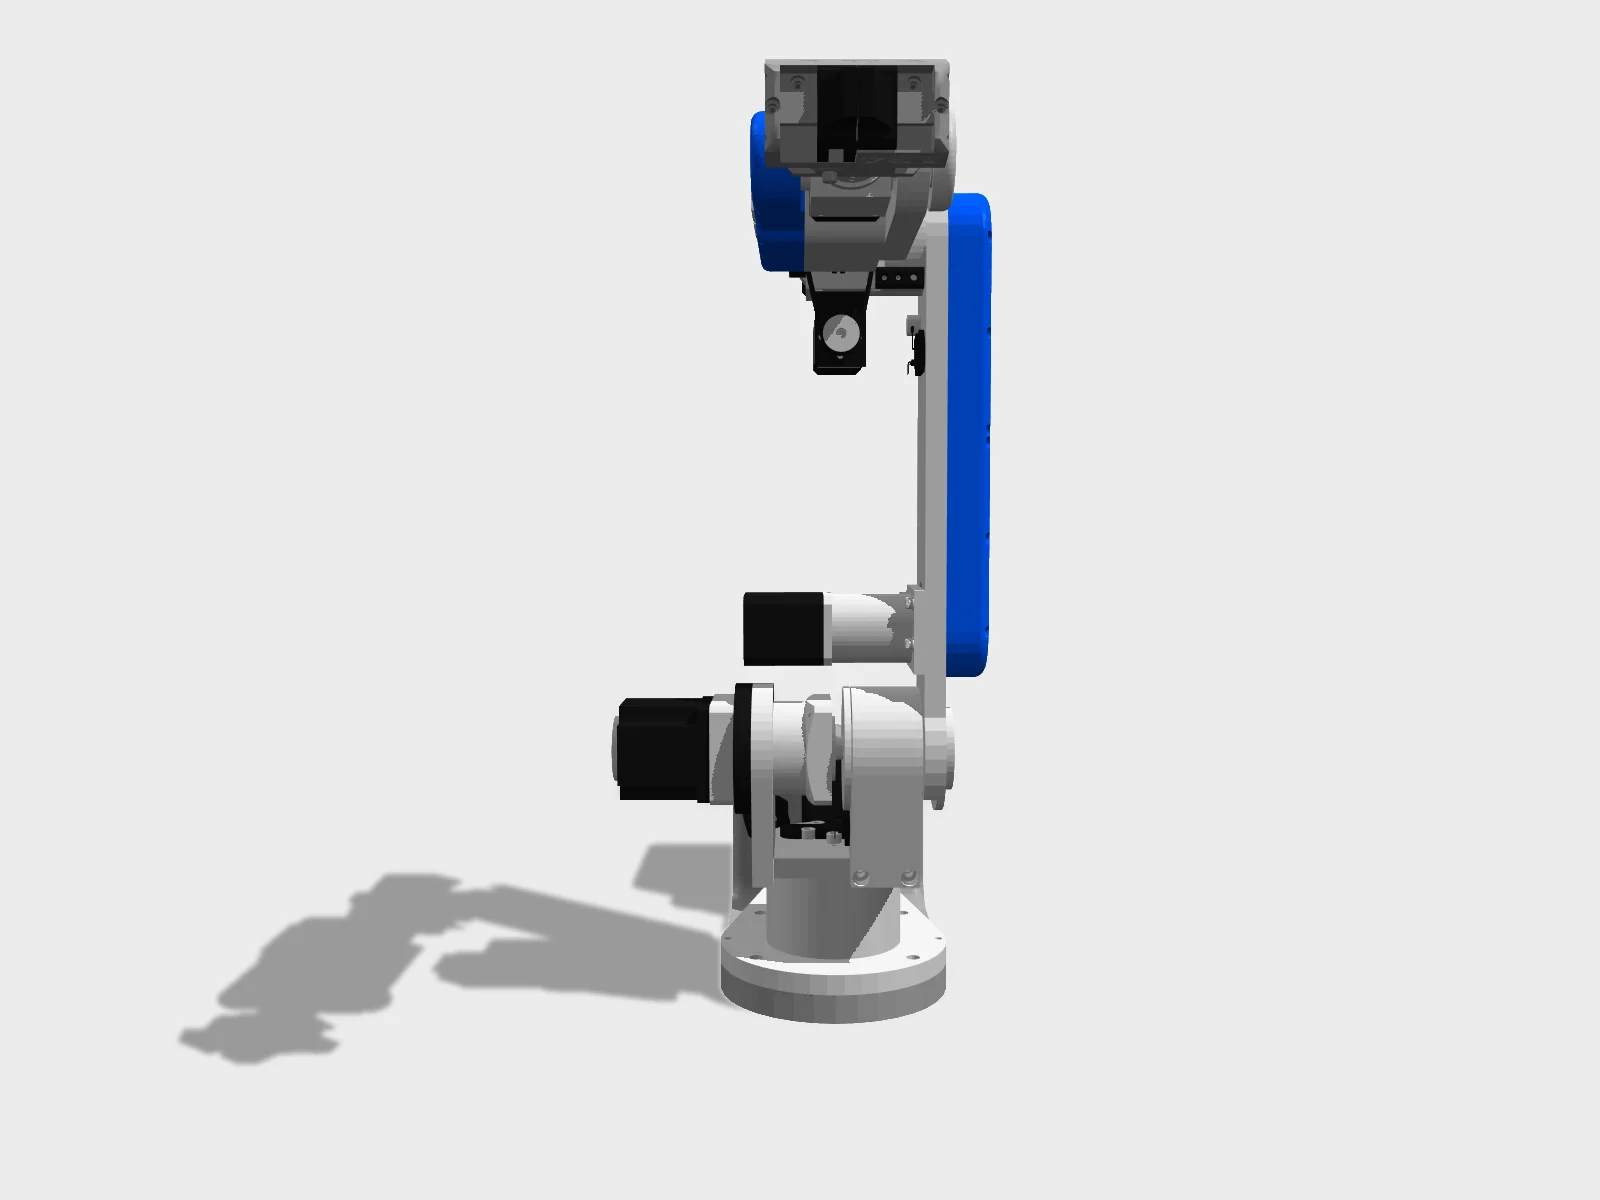 render
Specifications
1/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | 6 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedTotal build cost just over $2,000 USD (varies with part sourcing) |
| Actuatorsspecs.actuators | unsourced |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | unsourced |
| Licenselicense.hw / .sw / .docs | Hardware: LicenseRef-Annin-Robotics-NC-1.1Software: MIT AND LicenseRef-Annin-Robotics-NC-1.1 |
Note · Chris Annin declared the design complete with the final Mark 5 revision. ar4_ros_driver is MIT; ar4-hmi uses the Annin Robotics Open Source Non-Commercial License v1.1 (GitHub NOASSERTION), recorded as LicenseRef-Annin-Robotics-NC-1.1. The design files (STLs in ar4-hmi) fall under the same non-commercial license, so hw is LicenseRef-Annin-Robotics-NC-1.1: no commercial use, no rehosting. The current build is MK5 (AR4-MK5 build manual v1.1 on the downloads page). STL files are free; SolidWorks/STEP CAD for MK5 is sold separately ($99). sim=true refers to URDF in the ROS driver repo.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 90 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Structure | 26 | 39 | 699 |
| Cabling | 10 | 25.12 | — |
| Fasteners | 7 | 32 | — |
| Actuators | 6 | 6 | — |
| Electronics | 6 | 10 | — |
| Power | 3 | 3 | — |
| Sensors | 3 | 9 | — |
| Other | 2 | 2 | — |
| Compute | 1 | 1 | — |
Offers in GLOBAL · US from 2 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 2 | — | — |
| Base enclosure | 4 | — | 2 |
| J1 base | 3 | — | — |
| Arm | 5 | — | — |
| Firmware | 2 | — | — |
| First motion | 3 | — | 3 |
| Calibration | 2 | — | 1 |
| Software | 1 | — | 1 |
Fabrication: CNC ×26 · FDM print ×25
Firmware
- Targets
- Teensy 4.1 (arm: step/dir to 3x DM332T + 3x DM320T, 6 motor encoders, calibration inputs pins 26-31, E-stop pin 39), Arduino Nano or Mega (optional gripper / IO board, 5 V)
- Repo
- github.com/Annin-Robotics/ar4-hmi
- Calibrate
- AR4 HMI, Config Settings tab: 'Calibrate J1 Only' ... 'Calibrate J6 Only' or 'Auto Calibrate' drive each joint to its Hall sensor (J1-J3) or limit switch (J4-J6) and back to zero; trim per-joint calibration offsets (degrees, opposite sign of the measured error) and save. 'Force Cal Home' / 'Force Cal Rest' exist for setup only. ROS 2: `ros2 launch annin_ar4_driver driver.launch.py ar_model:=mk5 calibrate:=True` and `/calibrate_mask` service; offsets via CAL_OFFSET_DEG in the ROS Teensy sketch.
- Notes
- Two firmware lines: the Annin HMI sketch (AR4_teensy41_sketch; v7.0 on the downloads page, v6.3 in Annin-Robotics/ar4-hmi, needs Encoder, ModbusMaster, ArduinoJson) and the ROS driver sketch (annin_ar4_firmware/AR4_teensy v2.1.0, needs Bounce2). They are not interchangeable; reflash when switching. Steps per degree for MK4/MK5 per the step-calculation sheet: J1 88.89 (10:1 x 4), J2 111.11 (50:1), J3 111.11 (50:1), J4 99.56 (16:1 x 2.8), J5 43.72 (8 mm lead screw, 1600 microsteps), J6 44.44 (20:1). Servo gripper runs on an Arduino Nano sketch (AR4_nano_sketch).
Caveats · stated by the package
- Upstream pins: AR4-MK5 Robot Manual v1.1 (version log 6/8/26; PDF at anninrobotics.com, 390 pages) as of 2026-09-25; AR4-MK5-3D-Print-Files.zip (2026-06 upload); AR4-MK5-motor-step-calculations.xlsx; downloads and robot-kits pages as of 2026-09-25 (Teensy sketch v7.0, HMI 7.0); Annin-Robotics/ar4-hmi@ed2abfd3a33340745dd4e2e114a7b1ac6761fc29 (2025-11-19, HMI 6.3.1, Teensy sketch v6.3); Annin-Robotics/ar4_ros_driver@6a3ebb11cedab12cd1d29b41d63aa270a008ab8b (2026-06-09, Teensy firmware 2.1.0, ar_model mk1-mk5)
- Only kit-level USD prices are published: MK5 Combo Kit $1,189, Aluminum Parts Kit $699, Hardware Kit $319, Electrical Parts Kit $229, Pneumatic Gripper Parts Kit $139, Servo Gripper Parts Kit $74.50, MK5 CAD (SolidWorks/STEP) $99. Individual parts, the StepperOnline motor/driver/PSU package and printed parts are unpriced here. Only the aluminium kit line carries a price, so any computed total is far below the real cost (robots.ts note: just over $2,000).
- The main robot BOM does not list a power supply. The 24 V 8 A adapter appears in the pneumatic gripper BOM and ships in the StepperOnline package; it is a mains brick feeding a 5.5 mm jack.
- Motor part numbers disagree inside the manual: the motor BOM pages list J2 23HS22-2804D-YGS50-AR4 and J6 14HS11-1004D-EGS20-AR4, while the DIP-switch table lists 23HS22-2804D-HG50 and 14HS13-0804D-PG19 (0.92 A). The BOM SKUs are used here; set the J6 driver current for the motor you actually receive.
- The manual cover says Version 1.0 but its version log records 1.1 (6/8/26: new J3 sensor mount, belt tension text). Build-manual PDFs are replaced on the downloads page without changelogs beyond that log.
- GitHub lags the website: ar4-hmi holds HMI 6.3.1 and Teensy sketch v6.3 (2025-11), while anninrobotics.com offers HMI 7.0 and sketch v7.0 (2026-07). The sketch and HMI versions must match.
- The ROS driver README still lists ar_model options up to mk4, but driver.launch.py accepts mk5 and defaults to it. ROS use needs the separate annin_ar4_firmware sketch.
- Licensing: ar4-hmi and the design files are under the Annin Robotics Open Source Non-Commercial License v1.1 (no commercial use; design files may not be redistributed or rehosted). Only ar4_ros_driver is MIT. STL files are free; SolidWorks/STEP CAD for MK5 is sold ($99).
- Fully printed builds are possible but the J4 main shaft must be aluminium tube, several large parts must be split and epoxied, and the manual notes belt tension cannot reach aluminium-build levels.
- Fastener table lists 'M3 x 6 Button Head screw' and 'M3x6 Button head' as separate one-off lines; both are kept. The page 28 table is grouped here into sets, counts unchanged.
- No trained policies or datasets for AR4 were found on Hugging Face (search 2026-09-25).
Package anninrobotics/ar4@0.1.0 · upstream AR4-MK5 Robot Manual v1.1 (version log 6/8/26; PDF at anninrobotics.com, 390 pages) as of 2026-09-25; AR4-MK5-3D-Print-Files.zip (2026-06 upload); AR4-MK5-motor-step-calculations.xlsx; downloads and robot-kits pages as of 2026-09-25 (Teensy sketch v7.0, HMI 7.0); Annin-Robotics/ar4-hmi@ed2abfd3a33340745dd4e2e114a7b1ac6761fc29 (2025-11-19, HMI 6.3.1, Teensy … (full pins in caveats) · 16 package sources
Models, repositories, links
7 links- URDFgithub.com/Annin-Robotics/ar4_ros_drivermodel
- Repogithub.com/Annin-Robotics/ar4_ros_drivergithub.com
- Repogithub.com/Annin-Robotics/ar4-hmigithub.com
- Siteanninrobotics.com/anninrobotics.com
- Docsanninrobotics.com/downloads/anninrobotics.com
- Buyanninrobotics.com/anninrobotics.com
- Videoyoutube.com/watch?v=EwWnPqnSizQyoutube.com
Videos
2 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning AR4
Papers using AR4
Sources
last checked 2026-09-25- [1]Annin downloads: AR4-MK5 build manual, STLs, softwareanninrobotics.com/downloads/checked 2026-09-25
- [2]ar4-hmi LICENSE.txt (Annin Robotics Open Source Non-Commercial License v1.1)github.com/Annin-Robotics/ar4-hmi/blob/main/LICENSE.txtchecked 2026-09-25
- [3]Annin Robotics siteanninrobotics.com/checked 2026-09-24
- [4]Hackster: AR4 Mark 5 final revisionhackster.io/news/chris-annin-calls-the-open-source-ar4-robot-arm-done-with-the-new-final-mark-5-revision-62b51e0ae555checked 2026-09-24
- [5]Annin: ~$2000 build costanninrobotics.com/docs/what-6-axis-robot-arm-models-do-you-recommend-for-around-2000-usd/checked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “Annin AR4 specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/anninrobotics/ar4
Machine-readable: /data.json (record anninrobotics/ar4).