berkeley/humanoid-lite · spec sheet
UC Berkeley Humanoid Lite specs
Open-source sub-$5,000 humanoid built from desktop-3D-printed cycloidal gearboxes and off-the-shelf parts; 0.8 m, 16 kg, 22 DOF.
Media
3 items · credited and licensed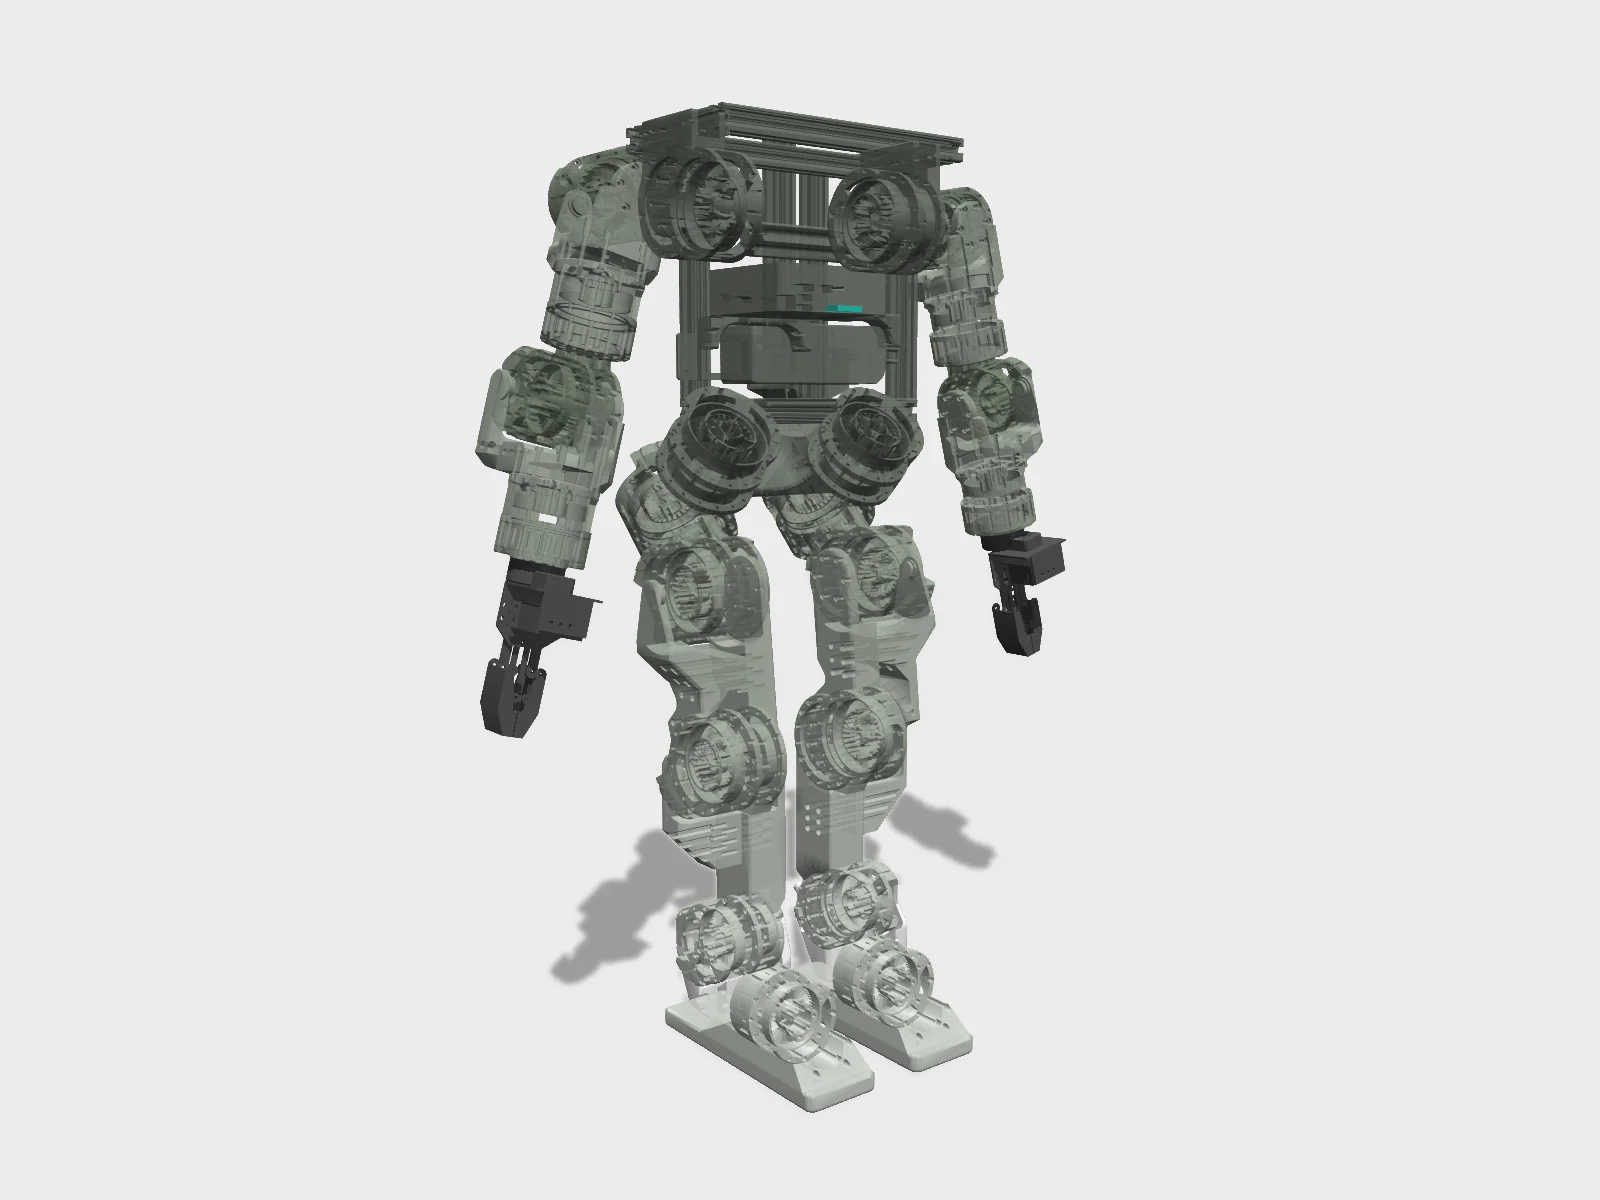 render
 render
Specifications
5/12 fields sourced| Heightspecs.heightCm | 80cm |
|---|---|
| Massspecs.massKg | 16kg |
| Degrees of freedomspecs.dof | 22 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedBuild cost under $5,000 (self-build; not sold) |
| Actuatorsspecs.actuators | BLDC motors with 3D-printed cycloidal gearboxes |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2025 |
| Licenselicense.hw / .sw / .docs | Hardware: CC-BY-SA-4.0Software: MIT |
Note · 6 DOF per leg, 5 DOF per arm. Paper arXiv:2504.17249. L2 on the same basis as other maker-published MJCF + policy packages: MJCF in berkeley-humanoid-lite-assets, ONNX policies in the main repo's checkpoints/.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 100 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 2 | 22 | 2,298 |
| Electronics | 3 | 28 | 521 |
| Structure | 10 | 415 | 516 |
| Sensors | 3 | 24 | 175 |
| Cabling | 2 | 23 | 160 |
| Fasteners | 8 | 899 | 158 |
| Power | 6 | 6 | 148 |
| Compute | 1 | 1 | 129 |
| Other | 1 | 2 | 72 |
| Printed | 1 | 1 | 26 |
Offers in CN · US from 6 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| fabrication | 1 | — | — |
| actuator | 4 | — | 1 |
| firmware | 4 | — | 2 |
| assembly | 2 | — | — |
| electrical | 1 | — | 1 |
| software | 1 | — | — |
| bring-up | 1 | — | 1 |
Fabrication: FDM print ×5
Firmware
- Targets
- STM32G431 on ST B-G431B-ESC1 (x22)
- Repo
- github.com/T-K-233/Recoil-Motor-Controller-BESC
- Calibrate
- Per actuator: berkeley_humanoid_lite_lowlevel scripts/motor/calibrate_electrical_offset.py -c canN -i ID (encoder flux offset stored in Flash). Per power-cycle: calibrate_joints.py (move joints to mechanical limits; writes calibration.yaml), since only a motor-side single-turn encoder is used.
- Notes
- Flash via STM32CubeIDE over the ESC's Micro-USB (onboard ST-LINK). Config in Core/Inc/motor_controller_conf.h: FIRST_TIME_BOOTUP, DEVICE_CAN_ID (1-63), LOAD_*_FROM_FLASH, MOTORPROFILE_MAD_M6C12_150KV / MOTORPROFILE_MAD_5010_110KV. CAN 2.0 at 1 Mbps, 4 buses (can0 L-arm, can1 R-arm, can2 L-leg, can3 R-leg). Low-level: https://github.com/HybridRobotics/Berkeley-Humanoid-Lite-Lowlevel (C real_humanoid + Python).
Policies
- Velocity-Berkeley-Humanoid-Lite-v0 (22-DoF full humanoid velocity tracking) · Isaac Lab 2.1.0 / Isaac Sim 4.5.0 + rsl_rl PPO; ONNX deploy (policy_dt 0.04 s = 25 Hz) · github.com
- Velocity-Berkeley-Humanoid-Lite-Biped-v0 (12-DoF legs only) · Isaac Lab + rsl_rl PPO; ONNX (policy_dt 0.02 s = 50 Hz); also policy_biped_25hz_a/b.onnx · github.com
- Humanoid legs-only policy · Isaac Lab + rsl_rl; ONNX · github.com
- Video demo policy · Isaac Lab + rsl_rl; ONNX · github.com
- Sim2sim validation in MuJoCo · MuJoCo · berkeley-humanoid-lite.gitbook.io
- VR teleoperation of arms (SteamVR bridge) · SteamVR-Bridge (Windows) + IK solver · github.com
Caveats · stated by the package
- Robot-level quantities for actuator internals (bearings, screws, inserts, ESCs, encoders) are computed as per-actuator qty from the 6512/5010 BOM tabs x actuator count (10 and 12). The humanoid tab itself lists actuators only as sub-assemblies.
- Prices come from the public Google Sheet as example reference prices (US Amazon/DigiKey in USD, CN Taobao/Tmall in RMB given as priceCny, not converted). The sheet total is $4,350.59, while the paper says $4,312 (US) and $3,236 (CN).
- The sheet's 'BNO085' line links to an Amazon listing titled GY-ICM20948V2, so the link does not match the part name. The docs now strongly recommend the Hiwonder IM10A USB IMU instead, but the IM10A is excluded from the sheet total.
- Misc fasteners ($40) and cables & connectors ($50 robot + $5 per actuator) are lump sums with no itemised list. XT30/XT60, WAGO connectors, 14/30 AWG silicone wire and heat shrink are named in the docs but not itemised.
- Print time and per-part grams are not published in the docs (the MakerWorld pages returned 403). The only mass figures are the sheet's 0.12 kg PLA per 6512 actuator and 0.10 kg per 5010, plus $100 of filament each for legs and arms.
- Assembly steps are mostly video-only (YouTube) for the actuator, arm, leg and full robot, so step bodies summarise the written text plus the video titles. Per-step minutes are not published; the paper gives about 3 days of assembly total.
- The AS5600 resistor modification is documented on an external page (notes.tk233.xyz/electrical/as5600-modification) that I did not retrieve.
- The on-board computer page says 'press XXXX' to enter BIOS (placeholder in the docs). Its script paths (berkeley_humanoid_lite_lowlevel/motor/ping.py) differ from the later scripts/motor/ping.py paths.
- USB-CAN case print qty (4) assumes one per adapter; the docs do not state a count.
Package berkeley/humanoid-lite@0.1.0 · upstream docs last update 2025-11-10 (release log); main repo tag v1.1.0, main@984741a3623c93b0583ccfdc479f1f8b1c4d900e; lowlevel@652777cc7c49884e7cd7ddfada758dc1979bf627; firmware Recoil-Motor-Controller-BESC@3571ab60a05951561abbab2e27c816b67b315bb0 · 16 package sources
Models, repositories, links
7 links- URDFgithub.com/HybridRobotics/berkeley-humanoid-lite-assetsmodel
- MJCFgithub.com/HybridRobotics/berkeley-humanoid-lite-assets/blob/main/data/robots/berkeley_humanoid/berkeley_humanoid_lite/mjcf/berkeley_humanoid_lite.xmlmodel
- Repogithub.com/HybridRobotics/berkeley-humanoid-litegithub.com
- Repogithub.com/HybridRobotics/berkeley-humanoid-lite-assetsgithub.com
- Sitelite.berkeley-humanoid.org/lite.berkeley-humanoid.org
- Docsberkeley-humanoid-lite.gitbook.io/docsberkeley-humanoid-lite.gitbook.io
- Videoyoutube.com/watch?v=dIdJGkMDFl4youtube.com
Videos
1 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Berkeley Humanoid Lite
Papers using Berkeley Humanoid Lite
20251
- Open source
Berkeley Humanoid Lite released
UC Berkeley researchers published Berkeley Humanoid Lite, an open-source humanoid with 3D-printed gearboxes and a parts cost under $5,000.
UC Berkeley Hybrid Robotics LabUC Berkeley Humanoid Litearxiv.orggithub.com
Sources
last checked 2026-09-24- [1]Official repogithub.com/HybridRobotics/berkeley-humanoid-litechecked 2026-09-24
- [2]arXiv paperarxiv.org/abs/2504.17249checked 2026-09-24
- [3]3D Printing Industry3dprintingindustry.com/news/uc-berkeley-unveils-5000-customizable-humanoid-robot-for-open-source-collaboration-239369/checked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Also by UC Berkeley Hybrid Robotics Lab
Compare
- Berkeley Humanoid Lite vs UC Berkeley Humanoid
- Berkeley Humanoid Lite vs Booster K1
- Berkeley Humanoid Lite vs Noetix Bumi
- Berkeley Humanoid Lite vs Unitree R1
- Berkeley Humanoid Lite vs Hyperspawn Dropbear
- Berkeley Humanoid Lite vs Kepler Forerunner K2 "Bumblebee"
- Berkeley Humanoid Lite vs PUDU D9
- Berkeley Humanoid Lite vs Unitree G1
Cite this page
humanoidrobots.systems. “UC Berkeley Humanoid Lite specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/berkeley/humanoid-lite
Machine-readable: /data.json (record berkeley/humanoid-lite).