agility/cassie · spec sheet
Agility Cassie specs
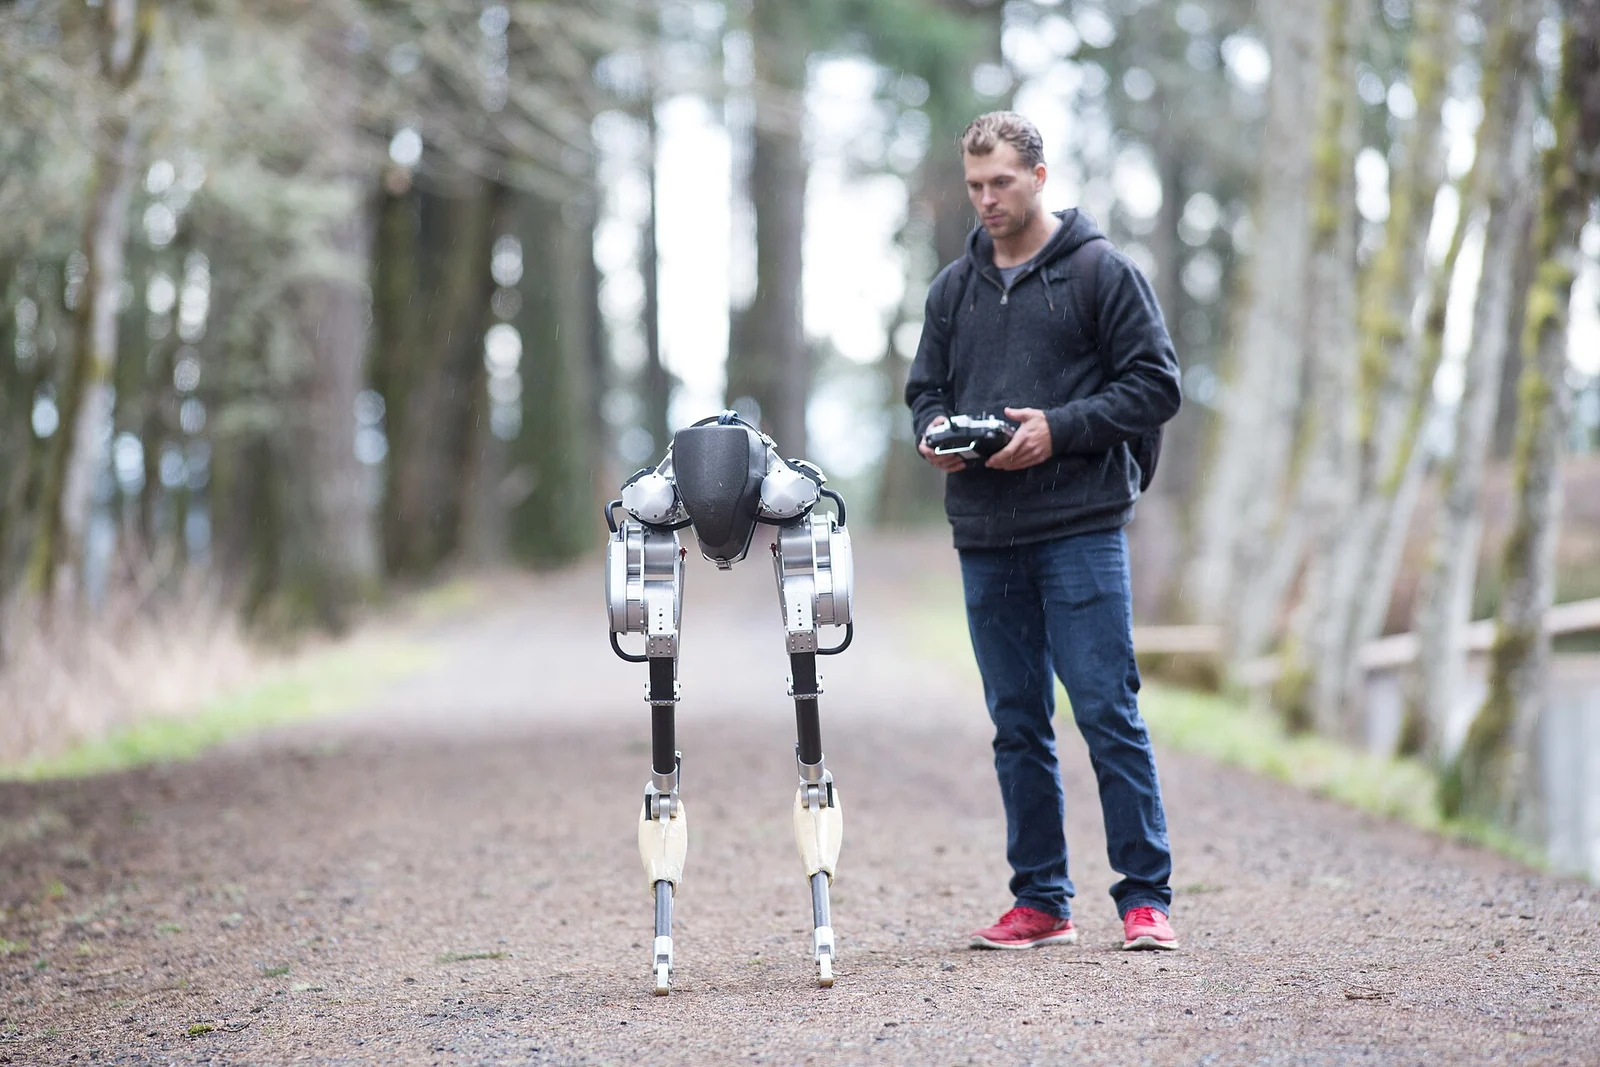
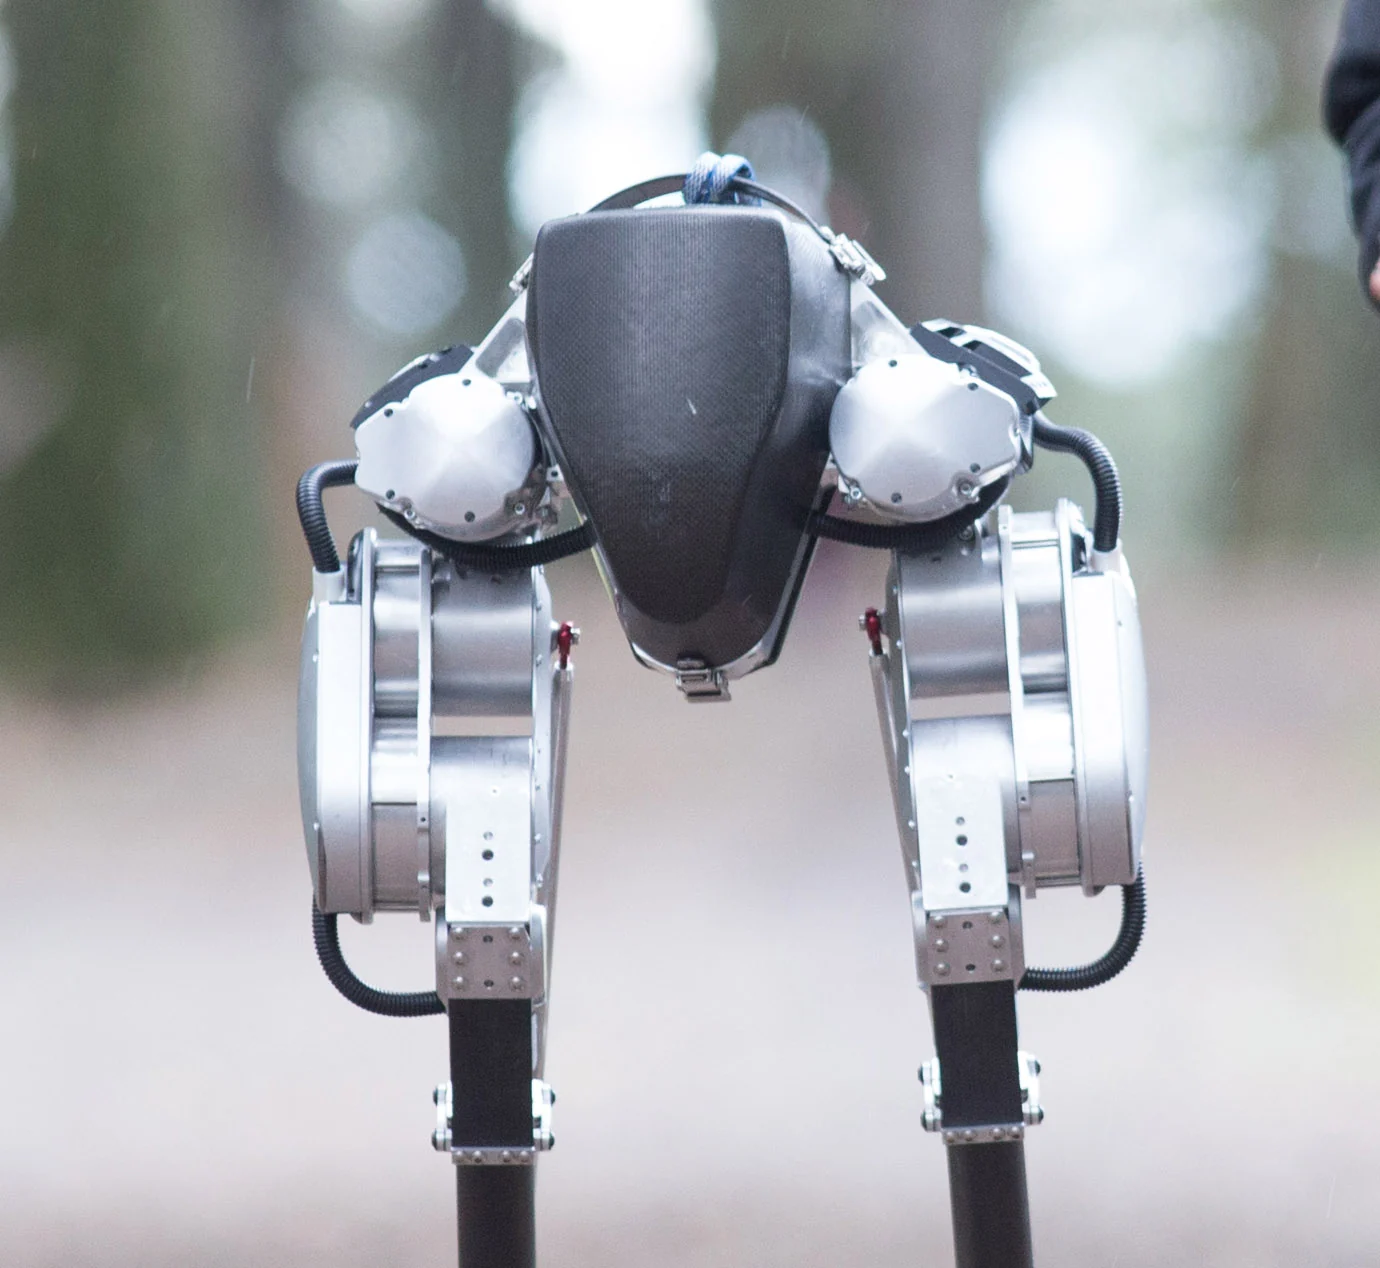
Torso-less bipedal research robot spun out of Oregon State University and sold to research labs. Superseded by Digit, which reuses its leg design.
Media
5 items · credited and licensed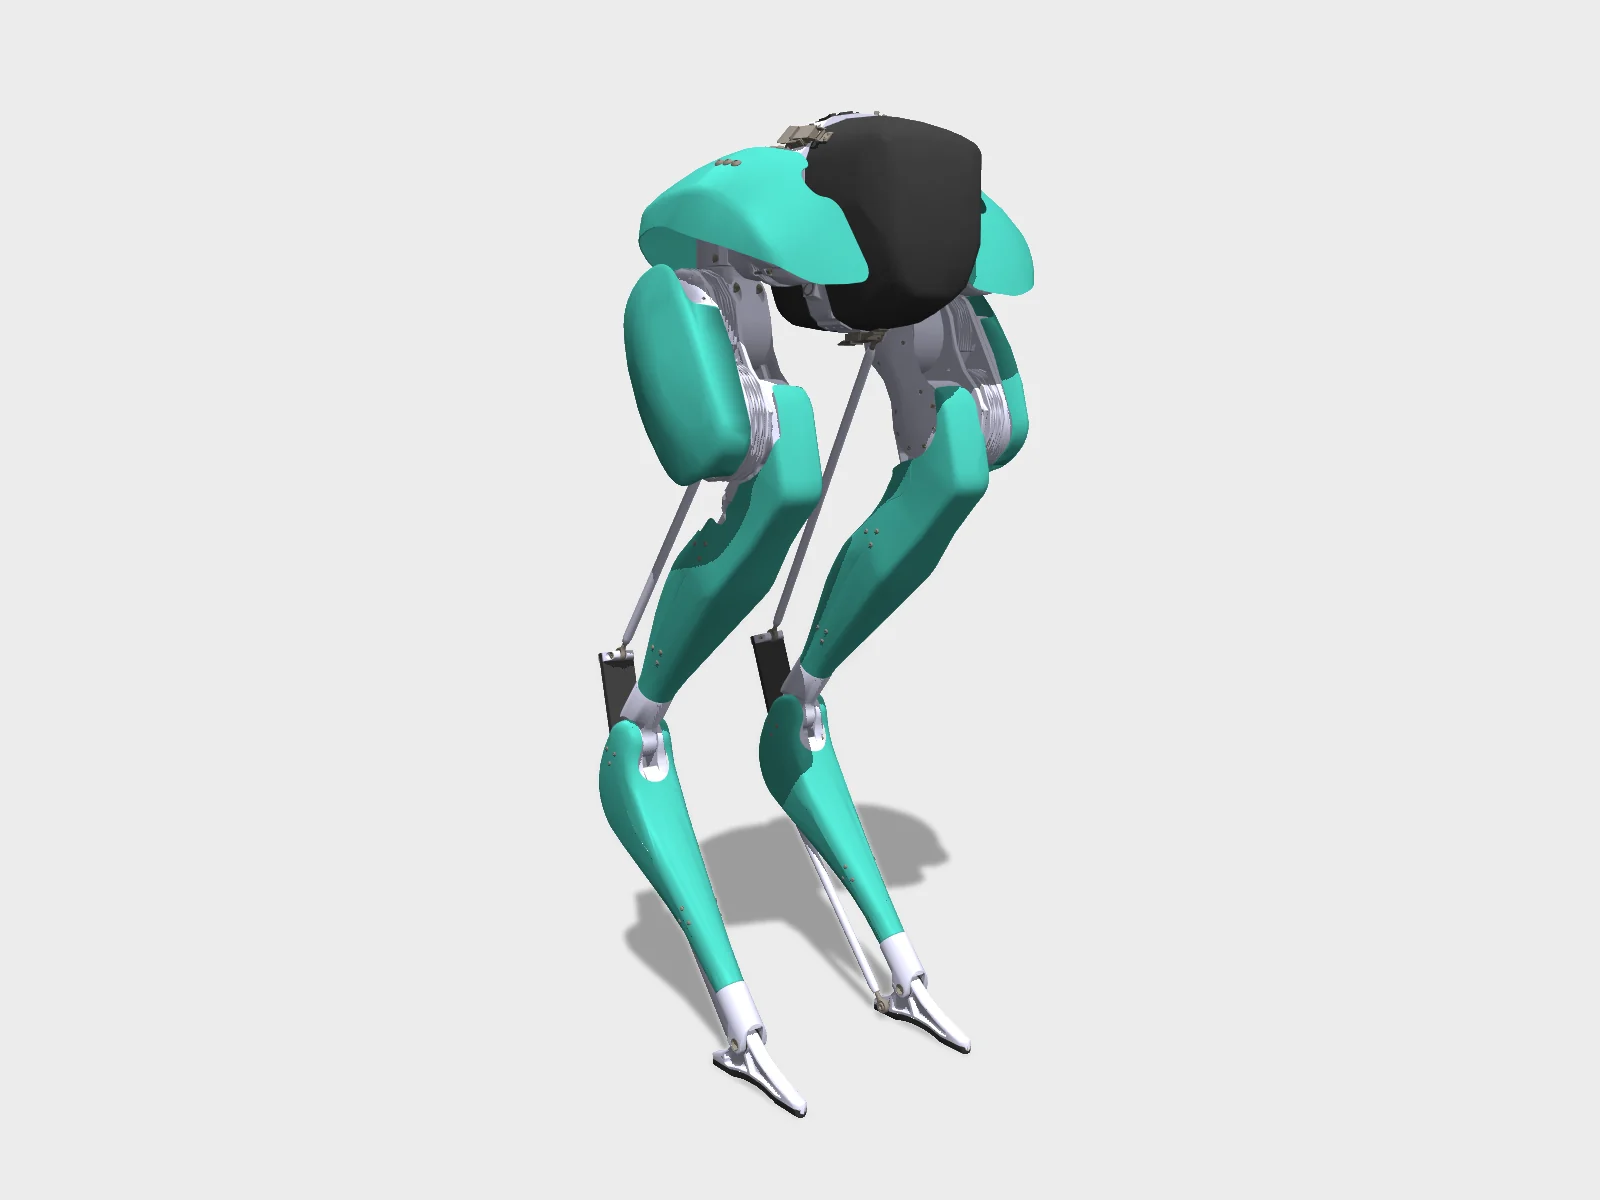 render
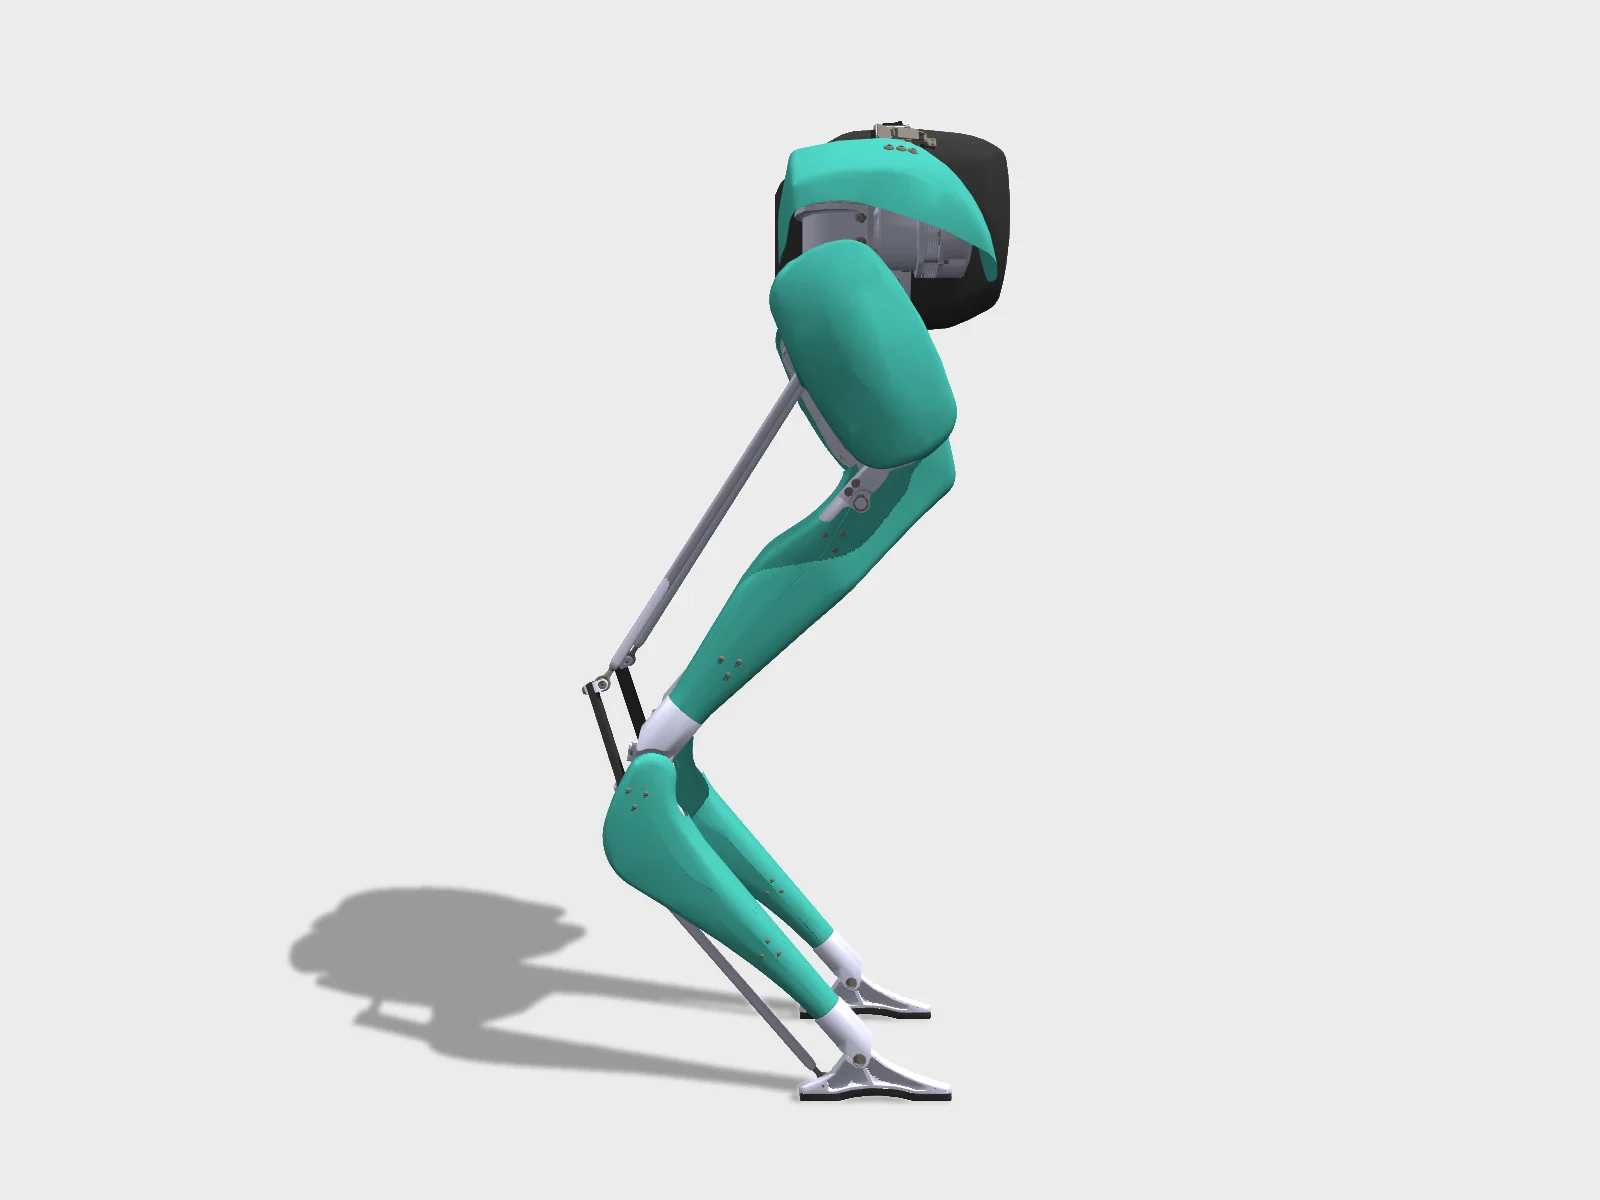 render


Specifications
3/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | 10 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | Not for saleNo longer sold. |
| Actuatorsspecs.actuators | unsourced |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2017 |
| Licenselicense.hw / .sw / .docs | unsourced |
Note · Ran an untethered 5K (2021) and set a Guinness record for fastest 100 m by a bipedal robot, 24.73 s (2022, OSU). agilityrobotics/cassie-doc is archived; osudrl/cassie-mujoco-sim last pushed 2023. DOF = actuated joints in menagerie model (5 per leg).
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | no | 25 | 0 |
| Bill of materialsopenness.bom | no | 20 | 0 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | no | 15 | 0 |
| Softwareopenness.software | no | 10 | 0 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 20 | ||
Models, repositories, links
5 links- MJCFgithub.com/google-deepmind/mujoco_menagerie/tree/main/agility_cassiemodel
- Menageriemujoco_menagerie/agility_cassiemodel
- Repogithub.com/agilityrobotics/cassie-docgithub.com
- Repogithub.com/osudrl/cassie-mujoco-simgithub.com
- Docsgithub.com/agilityrobotics/cassie-docgithub.com
Videos
3 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Cassie
Papers using Cassie
20211
- Research
Cassie completes a 5 km run
Oregon State University reported that Cassie, trained with reinforcement learning, covered 5 kilometers in just over 53 minutes on a single charge.
Agility RoboticsAgility Cassienews.oregonstate.edu
20171
- Robot
Agility Robotics unveils Cassie
Agility Robotics, an Oregon State University spinout, introduced Cassie, a dynamic bipedal robot designed to walk over rough terrain.
Agility RoboticsAgility Cassiemashable.comece.engin.umich.edu
Sources
last checked 2026-09-24- [1]Wikipedia - Agility Roboticsen.wikipedia.org/wiki/Agility_Roboticschecked 2026-09-24
- [2]OSU - Cassie 5Knews.oregonstate.edu/news/bipedal-robot-developed-oregon-state-makes-history-learning-run-completing-5kchecked 2026-09-24
- [3]MuJoCo Menagerie agility_cassiegithub.com/google-deepmind/mujoco_menagerie/tree/main/agility_cassiechecked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Also by Agility Robotics
Cite this page
humanoidrobots.systems. “Agility Cassie specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/agility/cassie
Machine-readable: /data.json (record agility/cassie).