robotis/openmanipulator-x · spec sheet
ROBOTIS OpenMANIPULATOR-X (RM-X52-TNM) specs
Compact ROS-based 4-DOF arm with a 1-DOF gripper built from Dynamixel XM430 servos, sold as an educational/research manipulator.
Media
3 items · credited and licensed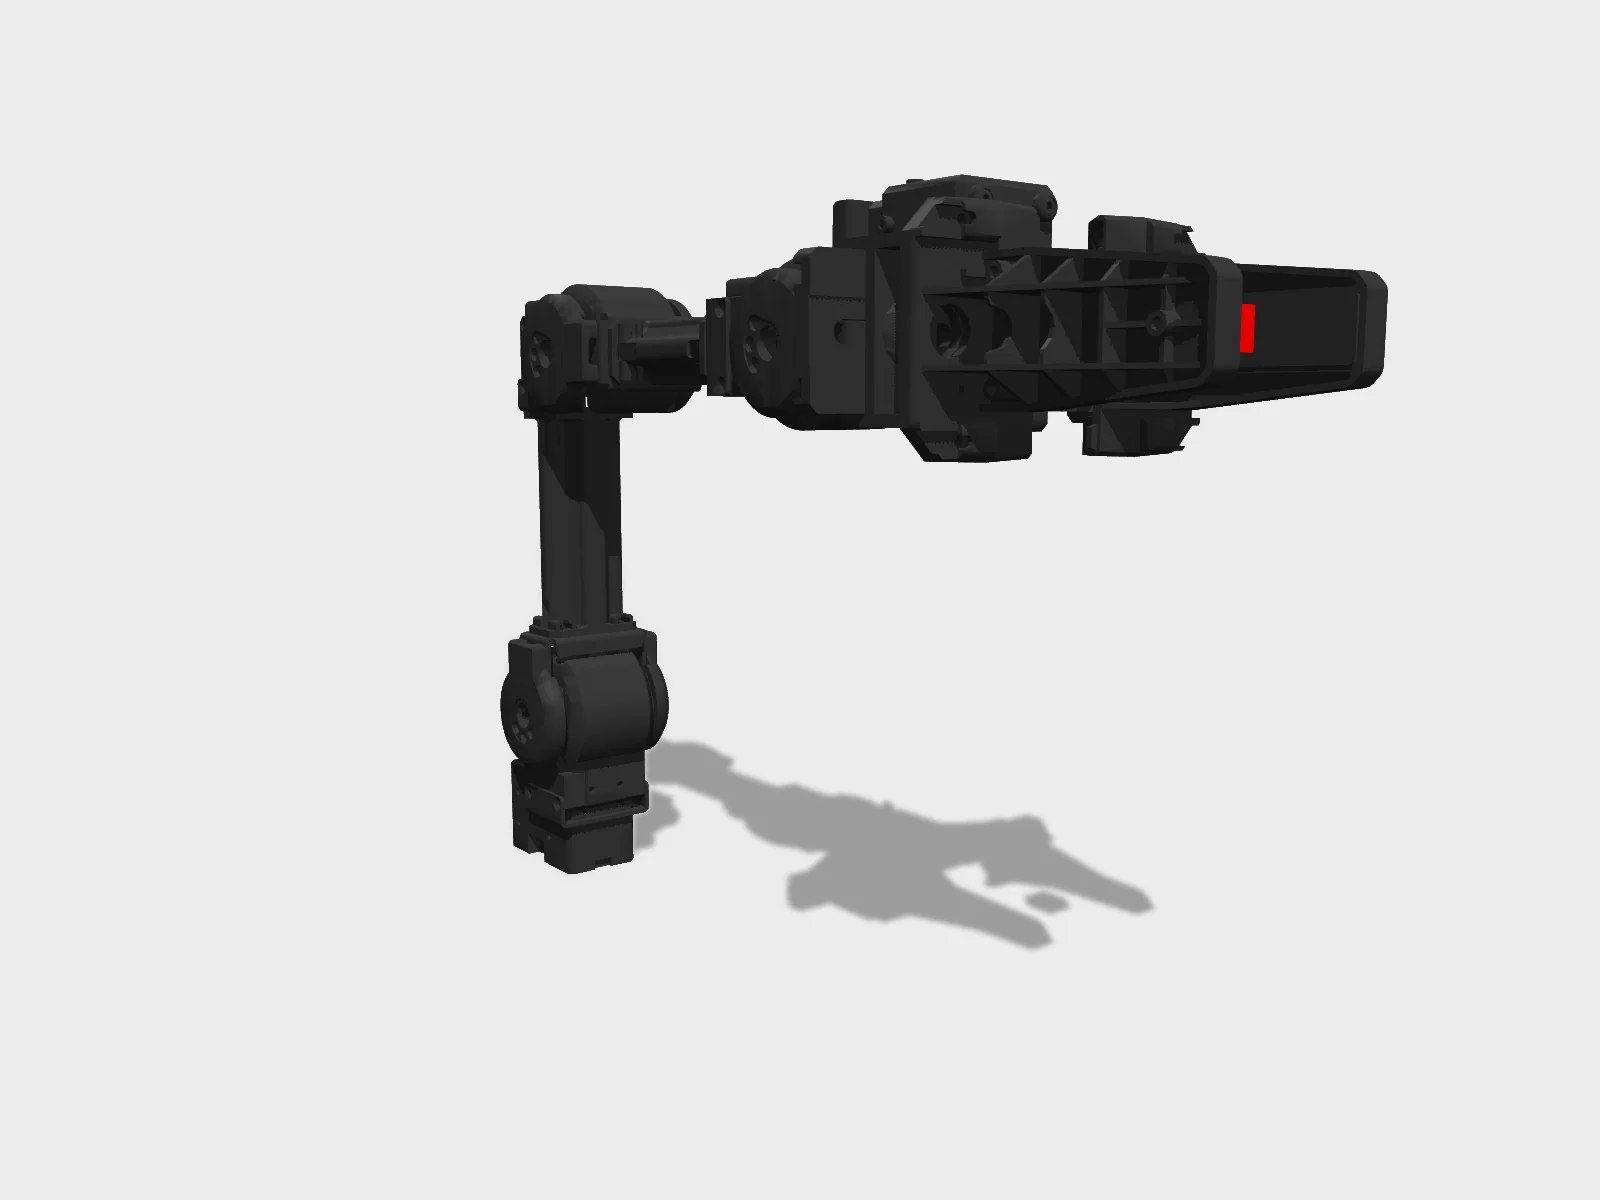 render
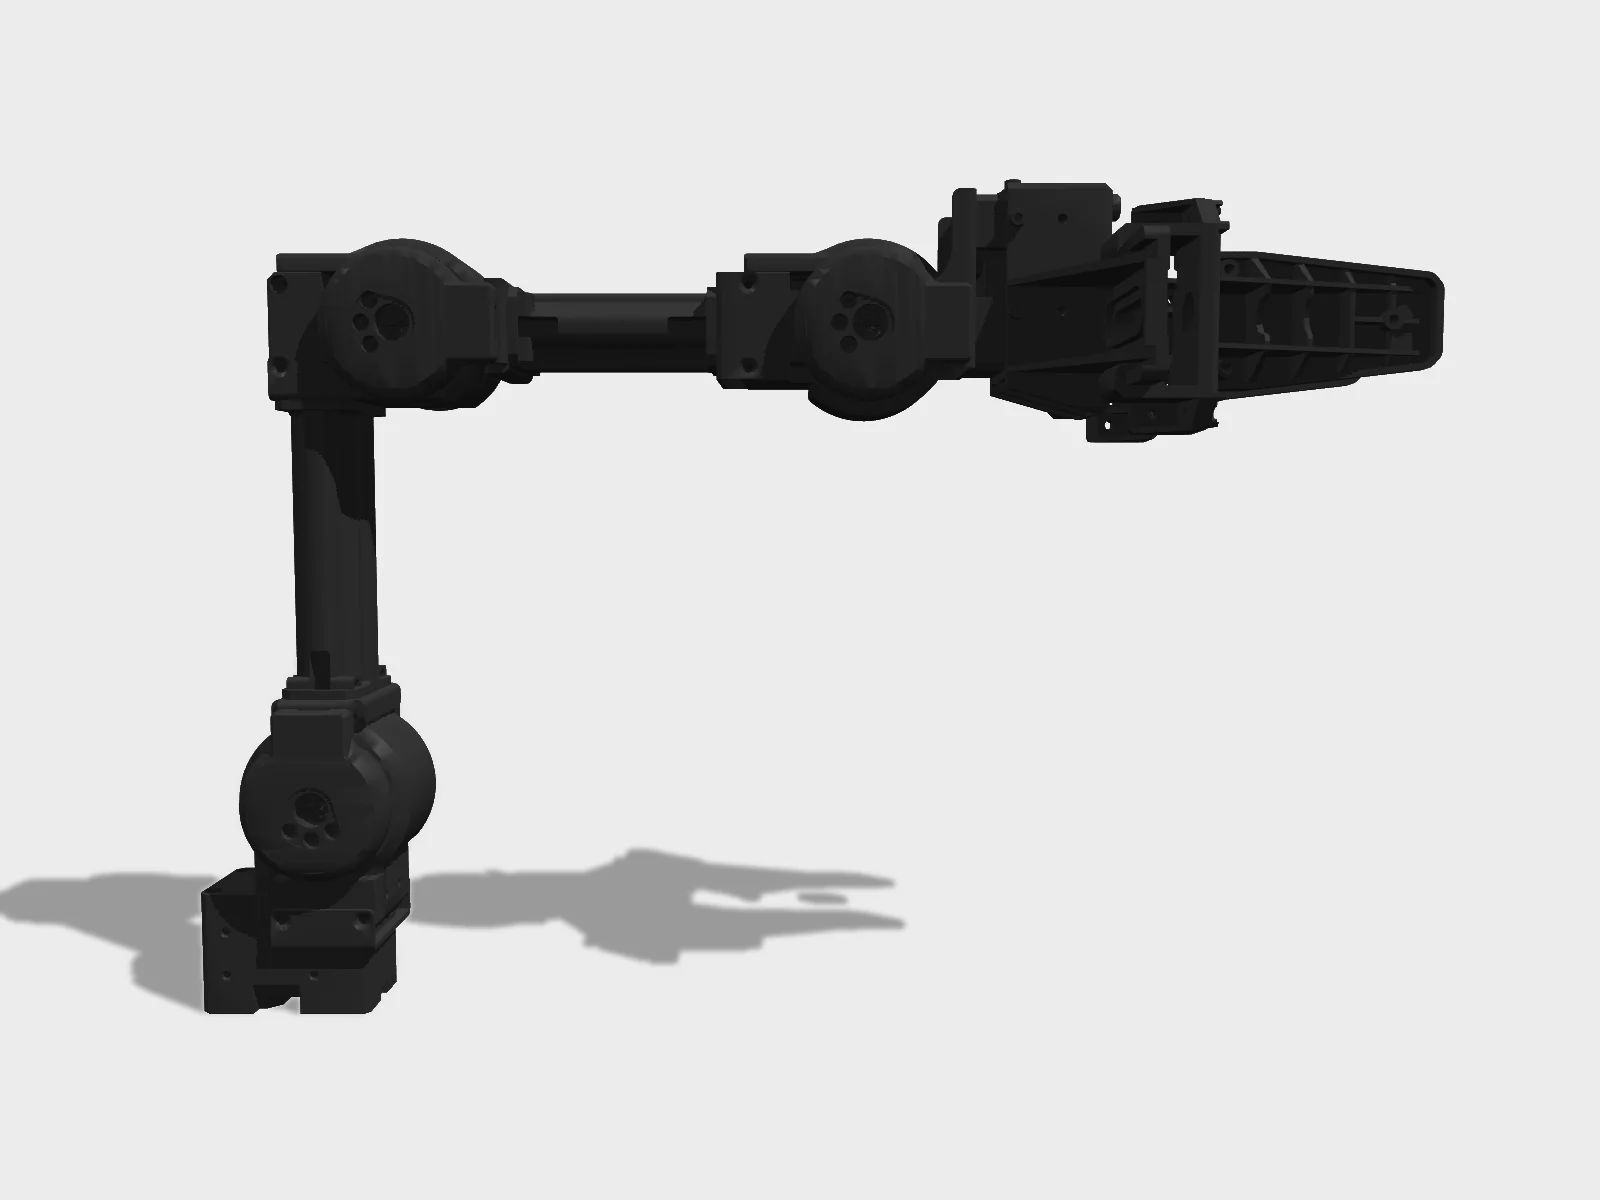 render
Specifications
4/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | 0.7kg |
| Degrees of freedomspecs.dof | 5 |
| Payloadspecs.payloadKg | 0.5kg |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedSold by ROBOTIS and resellers; 12 V PSU sold separately |
| Actuatorsspecs.actuators | 5x Dynamixel XM430-W350-T |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | unsourced |
| Licenselicense.hw / .sw / .docs | Software: Apache-2.0 |
Note · ROBOTIS' newer OMX (OMX-F follower / OMX-L leader) targets LeRobot-style imitation learning and lives in the same repo. CAD/BOM openness not verified, so marked false.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | no | 25 | 0 |
| Bill of materialsopenness.bom | no | 20 | 0 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | no | 15 | 0 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 30 | ||
Models, repositories, links
5 links- URDFgithub.com/ROBOTIS-GIT/open_manipulator/tree/main/open_manipulator_description/urdf/open_manipulator_xmodel
- Repogithub.com/ROBOTIS-GIT/open_manipulatorgithub.com
- Siteemanual.robotis.com/docs/en/platform/openmanipulator_x/overview/emanual.robotis.com
- Docsemanual.robotis.com/docs/en/platform/openmanipulator_x/overview/emanual.robotis.com
- Buyrobotis.us/products/openmanipulator-x-rm-x52-tnmrobotis.us
Videos
2 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning OpenMANIPULATOR-X (RM-X52-TNM)
Papers using OpenMANIPULATOR-X (RM-X52-TNM)
Sources
last checked 2026-09-24- [1]ROBOTIS US product pagerobotis.us/products/openmanipulator-x-rm-x52-tnmchecked 2026-09-24
- [2]ROBOTIS e-Manualemanual.robotis.com/docs/en/platform/openmanipulator_x/overview/checked 2026-09-24
- [3]open_manipulator repogithub.com/ROBOTIS-GIT/open_manipulatorchecked 2026-09-24
- [4]ROBOTIS OMXai.robotis.com/omx/introduction_omx.htmlchecked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
- Stanford ToddlerBot
- Poppy Humanoid
- ROBOTIS OP3
- Noetix Bumi
- UC Berkeley Humanoid
- UC Berkeley Humanoid Lite
Also by ROBOTIS
Compare
Compare OpenMANIPULATOR-X (RM-X52-TNM) with up to three others
Cite this page
humanoidrobots.systems. “ROBOTIS OpenMANIPULATOR-X (RM-X52-TNM) specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/robotis/openmanipulator-x
Machine-readable: /data.json (record robotis/openmanipulator-x).