stanford/umi-gripper · spec sheet
Stanford UMI Gripper (Universal Manipulation Interface) specs
Handheld, trigger-activated 3D-printed parallel-jaw gripper with a GoPro and side mirrors for in-the-wild demonstration collection, with policies deployable on robot-mounted grippers.
Media
3 items · credited and licensed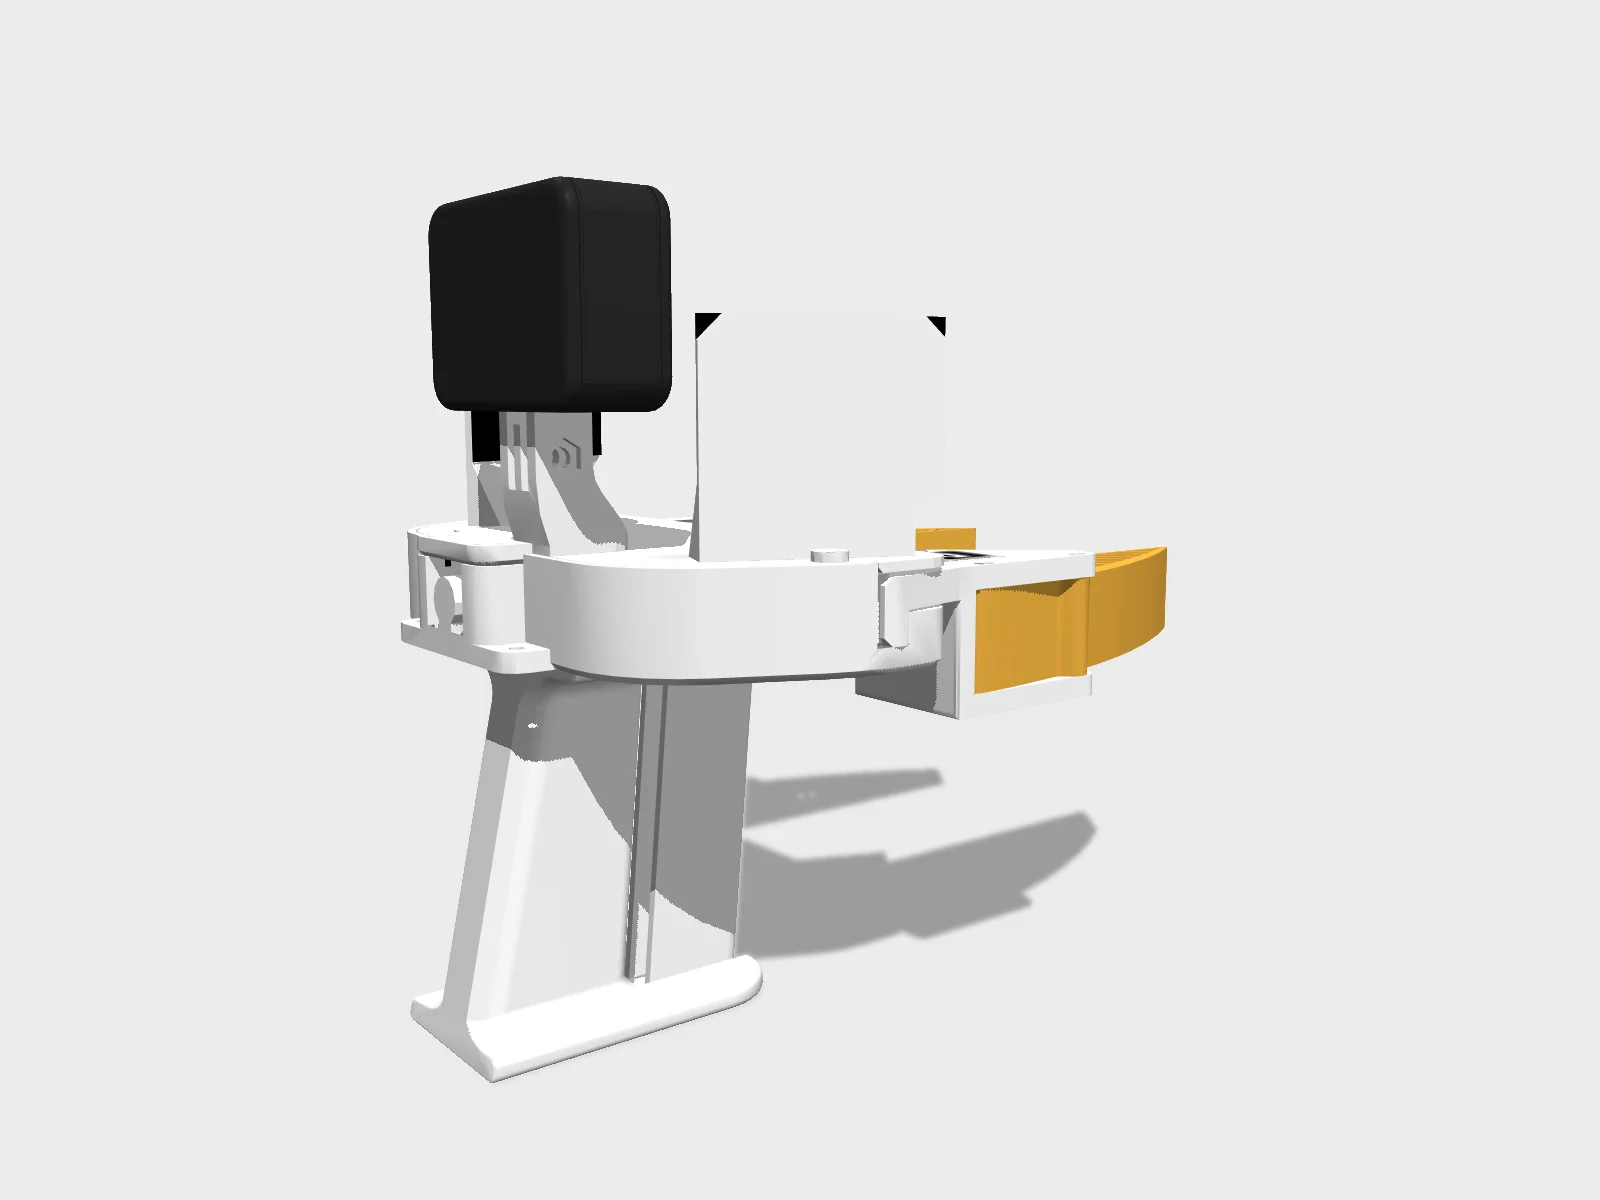 render
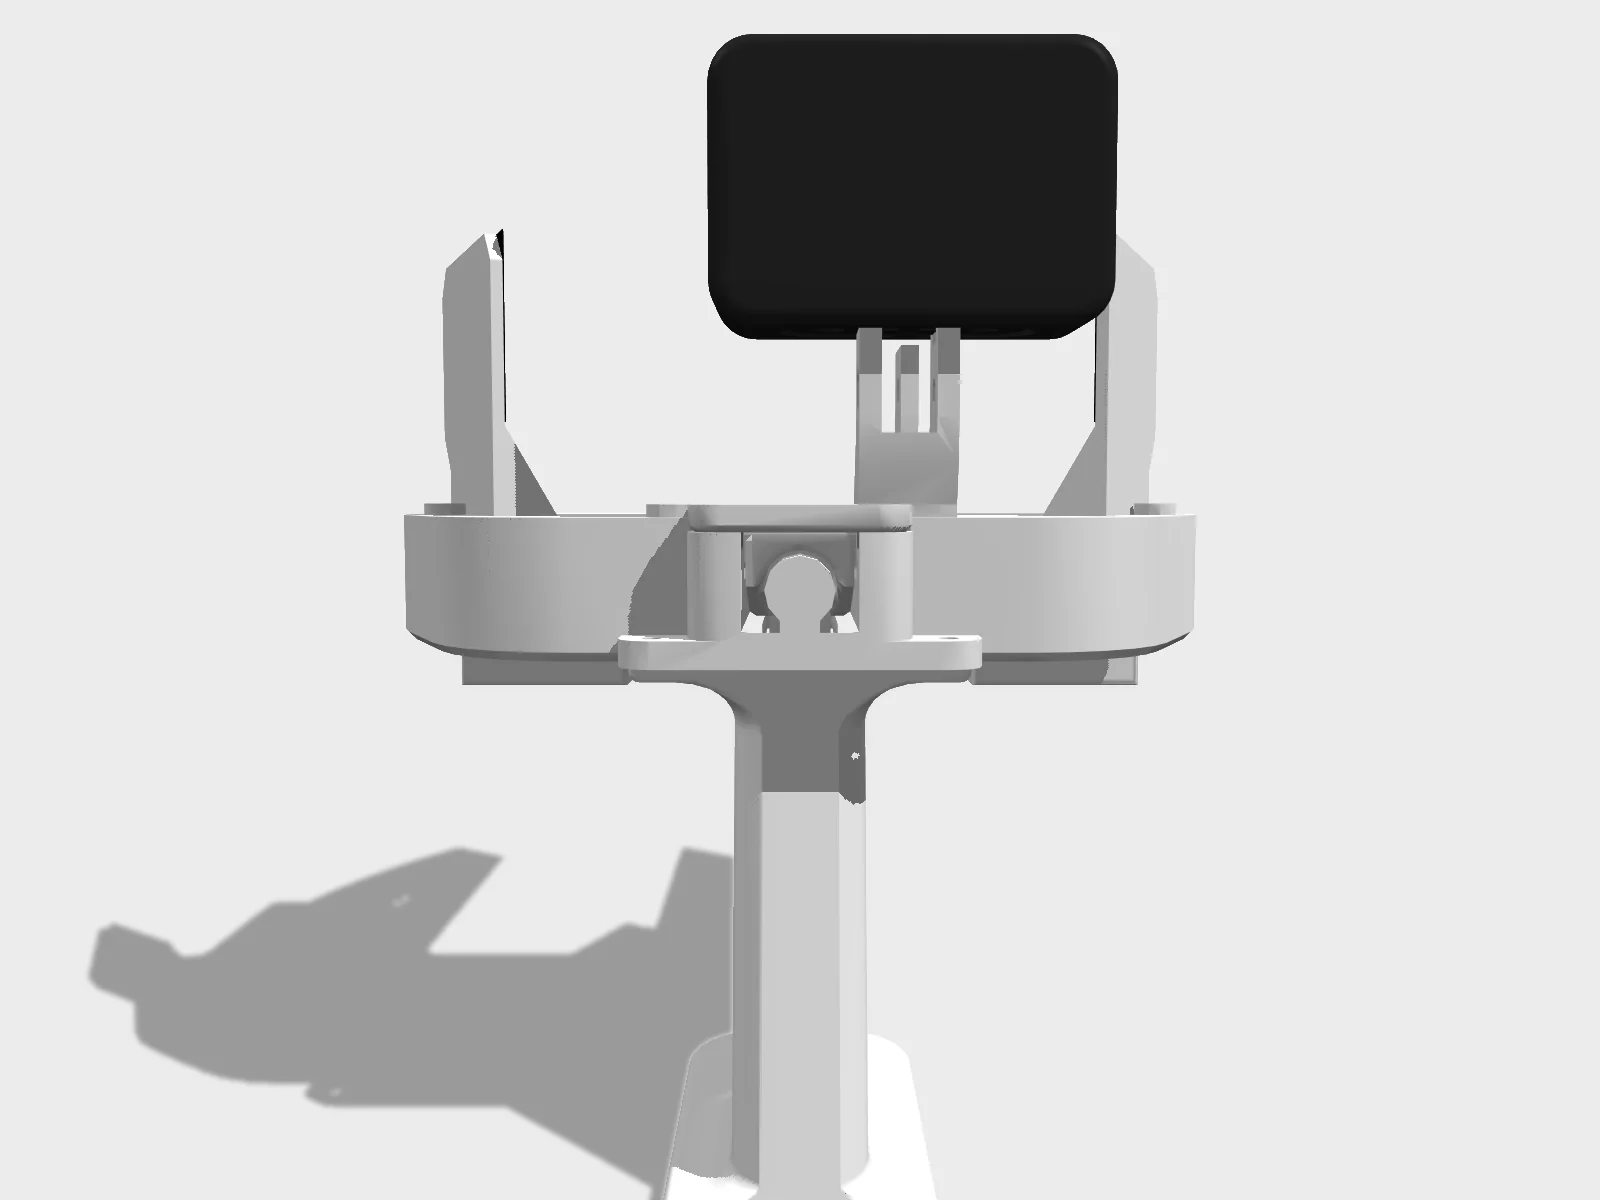 render
Specifications
2/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | unsourced |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourced |
| Actuatorsspecs.actuators | unsourced |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | GoPro camera with side mirrors |
| Year introducedyear | 2024 |
| Licenselicense.hw / .sw / .docs | Software: MIT |
Note · Presented at RSS 2024. Repo provides a pretrained checkpoint (cup arrangement). A simplified MJCF is in MuJoCo Menagerie (umi_gripper). The build guide (BOM, CAD, print settings, deployment) is the UMI Hardware Guide Google Doc; assembly is shown in video only. Code is MIT; the gripper mechanism and soft finger are adapted from third-party designs whose licenses are not stated.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | no | 15 | 0 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 85 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Sensors | 5 | 5 | 569 |
| Electronics | 5 | 5 | 245 |
| Cabling | 2 | 3 | 40 |
| Structure | 2 | 2.2 | 37 |
| Other | 4 | 3.07 | 24 |
| Printed | 2 | 0.75 | 20 |
| Fasteners | 2 | 1.5 | 11 |
| Actuators | 2 | 2 | — |
| Power | 1 | 1 | — |
| Compute | 1 | 1 | — |
Offers in EU · GLOBAL · US from 4 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 2 | — | — |
| Handheld gripper | 4 | — | — |
| Camera | 1 | — | — |
| Software | 1 | — | — |
| Data collection | 4 | — | — |
| Processing | 1 | — | — |
| Policy | 1 | — | — |
| Deployment | 7 | — | 2 |
Fabrication: FDM print ×10
Firmware
- Targets
- GoPro HERO9 (GoPro Labs firmware + UMI settings QR), Weiss WSG-50 (Lua startup script umi/real_world/cmd_measure.lua), UR5e / UR5-CB3 (stock controller, remote control mode)
- Repo
- github.com/real-stanford/universal_manipulation_interface
- Calibrate
- Per session: record a gripper calibration video (open/close 5 times) and a mapping video with the 16 mm table marker; `python run_slam_pipeline.py <session>` runs 04_detect_aruco and 05_run_calibrations. GoPro intrinsics ship as example/calibration/gopro_intrinsics_2_7k.json (calibrated with OpenImuCameraCalibrator).
- Notes
- SLAM uses the authors' ORB_SLAM3 fork (github.com/cheng-chi/ORB_SLAM3) via the chicheng/orb_slam3 Docker image. Time sync uses the umi-gripper.github.io/qrlocal QR timecode.
Policies
- In-the-wild cup arrangement (rotate espresso cup, place on saucer) · Diffusion Policy (UMI), fine-tuned CLIP ViT-L backbone · real.stanford.eduTrained on handheld UMI data from 30 locations; deployed on UR5e + WSG-50 with a GoPro. Real-world checkpoint, about 3.05 GB. README warns it does not work well in direct sunlight.
Caveats · stated by the package
- BOM prices are the Hardware Guide's Jan 2024 Amazon US figures; some quantities are fractions of a pack (0.5 PLA spool, 0.25 TPU spool, 0.07 grip tape roll). Mirror, grease, double-sided tape and tag quantities are blank upstream and set to 1 here.
- Every gripper vendor link is Amazon US (reduced here to /dp/ASIN); there are no EU, CN or IN sources upstream. The guide specifies a GoPro HERO9 with Max Lens Mod 1.0; HERO9 and Max Lens Mod 1.0 availability may be limited now.
- BOM is per gripper; bimanual collection needs two grippers with different ArUco tag sets.
- Assembly steps come from the assembly video; there is no written step-by-step assembly doc, so screw placement per step is not documented in text.
- Deployment hardware is expensive and partly unpriced: UR5e is by quote, the WSG-50 is €3875 (EUR, not converted). Franka and ARX X5 deployments are documented in separate files and repos.
- The README's download command fetches cup_wild_vit_l_1img.ckpt but its eval command passes cup_wild_vit_l.ckpt (that URL returns 404).
- SLAM (ORB_SLAM3) is the most fragile stage per the README; scene choice and marker size matter.
- The software is only tested on Ubuntu 22.04. Code is MIT; the gripper mechanism is adapted from a Thingiverse Push/Pull Gripper and the soft finger from TRI, whose licenses are not stated in the repo.
- The MuJoCo Menagerie umi_gripper model is a simplified model and is not referenced by the UMI repo.
Package stanford/umi-gripper@0.1.0 · upstream real-stanford/universal_manipulation_interface@d095ba9590df789df5189eea5ee7e431689038a6 (2026-05-26); UMI Hardware Guide (Google Doc) and UMI Data Collection Instruction (Notion) as of 2026-09-25; pretrained checkpoint cup_wild_vit_l_1img.ckpt (Last-Modified 2024-03-16) · 13 package sources
Models, repositories, links
5 links- MJCFgithub.com/google-deepmind/mujoco_menagerie/tree/main/umi_grippermodel
- Menageriemujoco_menagerie/umi_grippermodel
- Repogithub.com/real-stanford/universal_manipulation_interfacegithub.com
- Siteumi-gripper.github.io/umi-gripper.github.io
- Docsdocs.google.com/document/d/1TPYwV9sNVPAi0ZlAupDMkXZ4CA1hsZx7YDMSmcEy6EU/edit?usp=sharingdocs.google.com
Videos
1 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning UMI Gripper (Universal Manipulation Interface)
Papers using UMI Gripper (Universal Manipulation Interface)
20241
- Research
Universal Manipulation Interface (UMI) published
Researchers presented UMI, a handheld gripper and policy-learning framework for collecting manipulation demonstrations in the wild without a robot.
Stanford UniversityStanford UMI Gripper (Universal Manipulation Interface)arxiv.org
Sources
last checked 2026-09-25- [1]MuJoCo Menagerie umi_grippergithub.com/google-deepmind/mujoco_menagerie/tree/main/umi_gripperchecked 2026-09-24
- [2]UMI project pageumi-gripper.github.io/checked 2026-09-24
- [3]arXiv paperarxiv.org/abs/2402.10329checked 2026-09-24
- [4]Code repo (MIT)github.com/real-stanford/universal_manipulation_interfacechecked 2026-09-24
- [5]UMI Hardware Guide (BOM, CAD, print settings, deployment)docs.google.com/document/d/1TPYwV9sNVPAi0ZlAupDMkXZ4CA1hsZx7YDMSmcEy6EU/edit?usp=sharingchecked 2026-09-25
- [6]UMI pretrained checkpointsreal.stanford.edu/umi/data/pretrained_models/checked 2026-09-25
Suggest a correction
Related
Nearest by size (height, mass)
Also by Stanford / Columbia / Toyota Research Institute
Compare
Compare UMI Gripper (Universal Manipulation Interface) with up to three others
Cite this page
humanoidrobots.systems. “Stanford UMI Gripper (Universal Manipulation Interface) specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/stanford/umi-gripper
Machine-readable: /data.json (record stanford/umi-gripper).