menlo/asimov · spec sheet
Menlo Asimov 1 specs
1.2 m, 35 kg open-source biped with 25 actuated DOF, sold as an unassembled DIY kit or self-sourced from the published BOM and CAD.
Media
4 items · credited and licensed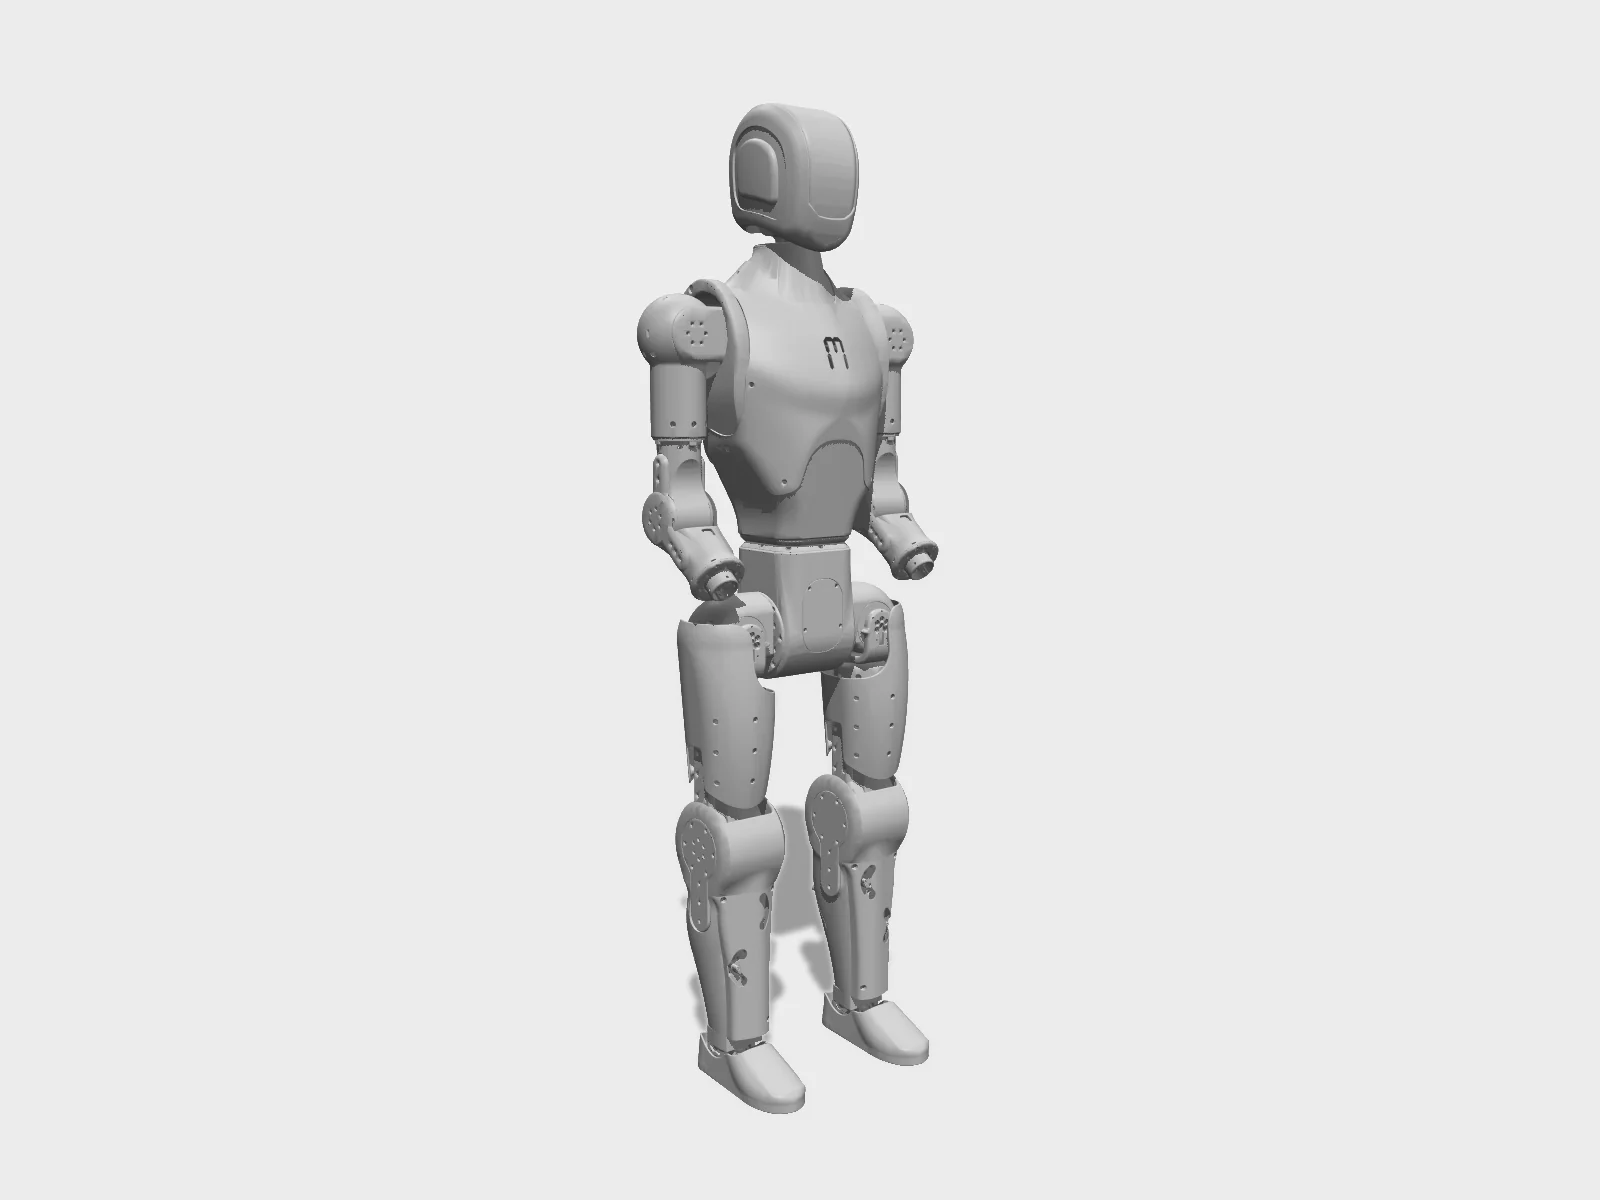 render
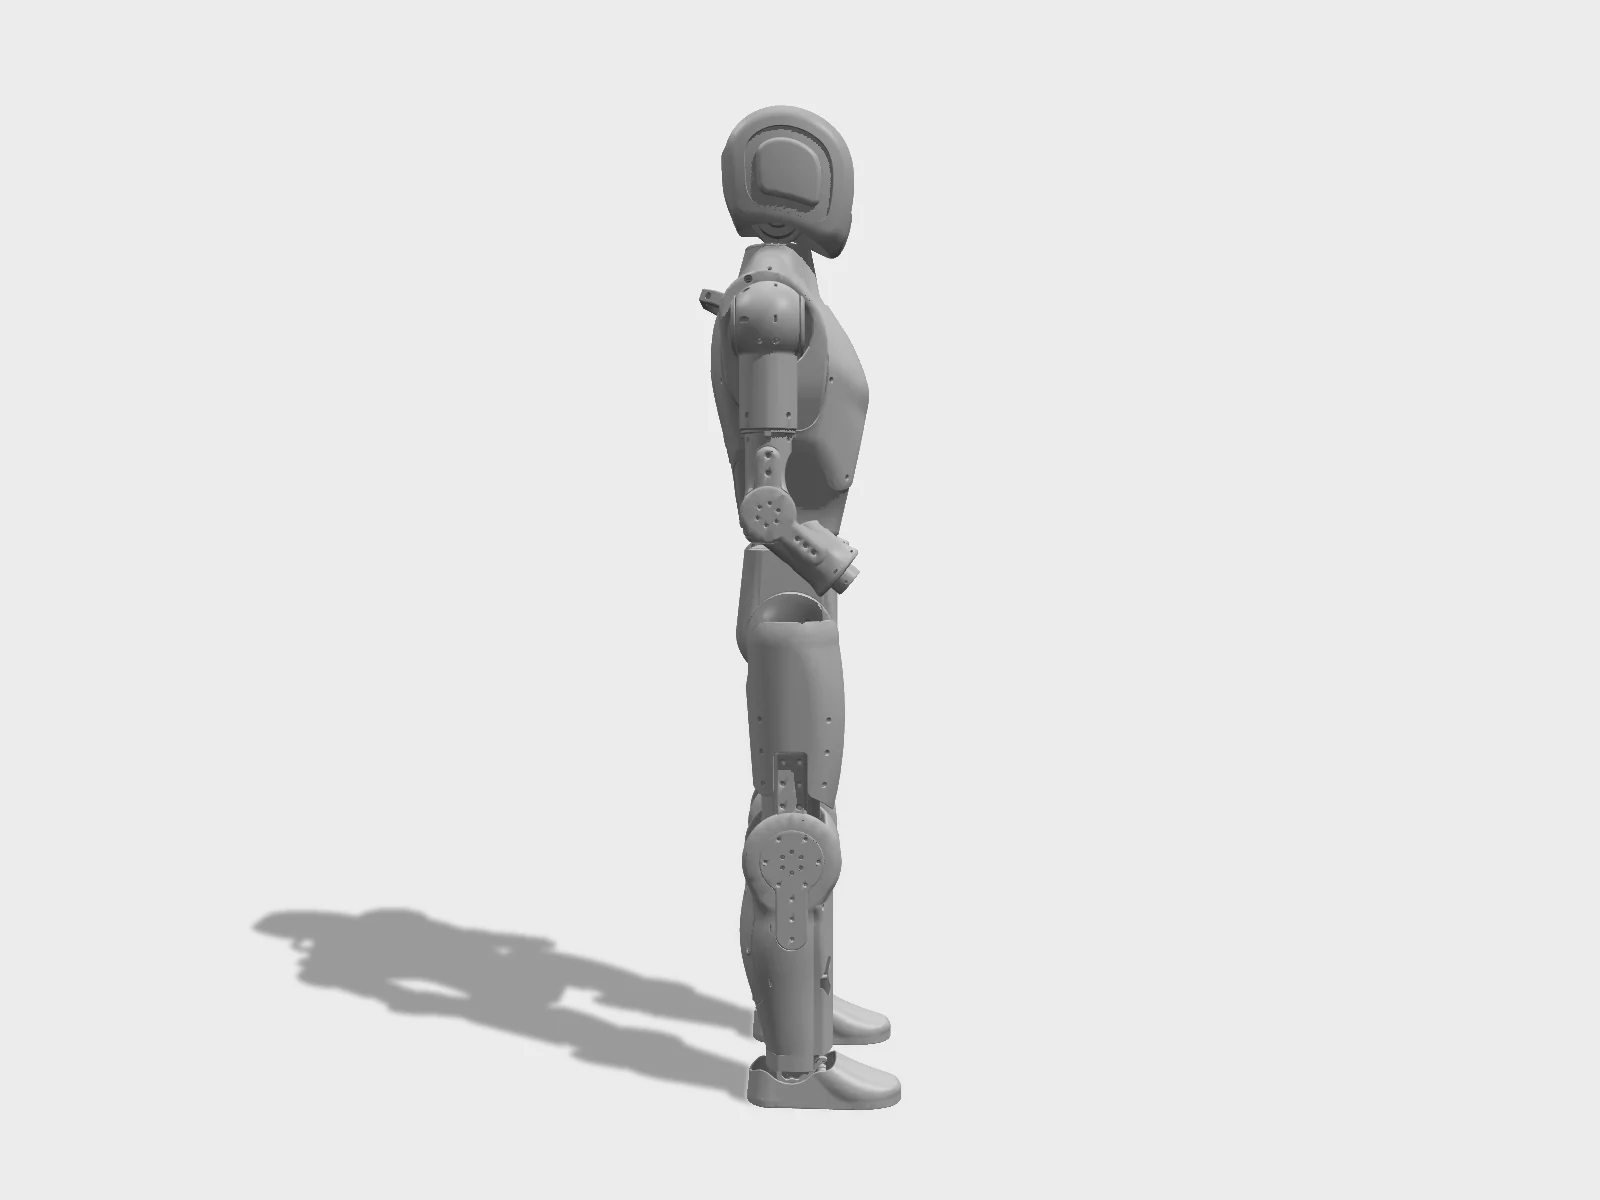 render
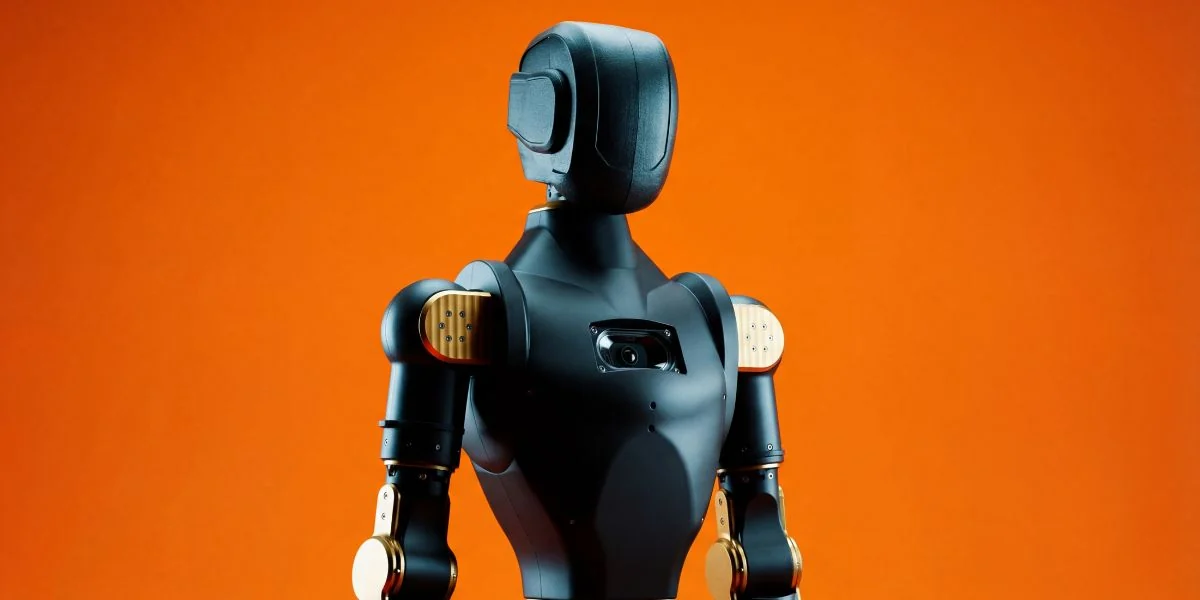

Specifications
8/12 fields sourced| Heightspecs.heightCm | 120cm |
|---|---|
| Massspecs.massKg | 35kg |
| Degrees of freedomspecs.dof | 25 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | 20,000USDDIY kit $20,000 shipping (README); announced Mar 2026 at $15,000 target with $499 deposit |
| Actuatorsspecs.actuators | CAN-bus actuators; 6 DOF/leg, 5 DOF/arm, 1 waist, 2 neck; RSU ankle with passive toes |
| Computespecs.compute | Raspberry Pi 5 (media/network) + Radxa CM5 (motion control) |
| Sensorsspecs.sensors | 2MP monocular camera, stereo mic array, 6-DOF IMU, joint states |
| Year introducedyear | 2026 |
| Licenselicense.hw / .sw / .docs | Hardware: CERN-OHL-S-2.0Software: GPL-2.0 |
Note · Kit announced Mar 2026; CAD and sim model open-sourced Apr 2026; shipments reported from Aug 2026. Hands not included in the kit. Build pages send buyers to the maker's own kit first. Repo asimovinc/asimov-v1 redirects to menloresearch/asimov-1. bom=false: docs gate the BOM behind a request form. policies=false: the locomotion policy ships inside the RPU firmware image, not as a separate published file.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | no | 20 | 0 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 70 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Fasteners | 33 | 751 | — |
| Cabling | 18 | 47 | — |
| Structure | 8 | 34 | — |
| Actuators | 5 | 25 | — |
| Electronics | 5 | 5 | — |
| Sensors | 3 | 3 | — |
| Other | 3 | 3 | — |
| Compute | 2 | 2 | — |
| Power | 1 | 1 | — |
Offers in GLOBAL from 1 vendor
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| preparation | 1 | — | — |
| software | 4 | 120 | 3 |
| electrical | 3 | — | 3 |
| legs | 2 | — | — |
| pelvis | 1 | — | 1 |
| arms | 1 | — | — |
| torso | 1 | — | — |
| bring-up | 1 | — | 1 |
Fabrication: SLS print ×55 · CNC ×43
Firmware
- Targets
- Radxa CM5 on RPU (asimov-rpu-v<version>.img.xz via rkdeveloptool, RK3588 SPL loader v1.15.113), Raspberry Pi 5 (asimov-rpi-v<version>.img.xz via Raspberry Pi Imager manifest), 25 Encos EC-A actuators (CAN ID assignment via dashboard)
- Repo
- github.com/menloresearch/asimov-1
- Calibrate
- Dashboard Robot Setup: apply asimov_1_biped profile, assign IDs 1-25 one motor at a time on port LL. Powered verification/first-boot procedure is 'coming soon' in docs.
- Notes
- Firmware images are distributed via 'the release channel provided with your kit'; the public docs say firmware download is 'Coming soon'. RPU runs locomotion policy, motor control, IMU, BMS; RPi5 runs media/network; LiveKit/WebRTC API, telemetry 10 Hz, trajectory stream ~50 Hz, states DAMP/STAND/MOVE. CAN: 5 @ 1 Mbps + 1 @ 500 kbps (docs flag bus assignment 'under confirmation').
Policies
- Full-body velocity locomotion (23-DOF, neck locked) · Isaac Lab or MJLab templates (per docs); MuJoCo/URDF models in repo · docs.menlo.aiWeights are bundled in the RPU firmware image and not published separately.
- Sim model for training · MuJoCo 3.x · github.comURDF variant: sim-model/urdf/asimov_1.urdf.
- Asimov v0 12-DOF biped velocity tracking (legs-only predecessor) · mjlab (MuJoCo Warp) RL · github.comVelocity task config in an mjlab fork (rl_cfg.py alongside). No weights file in the repo (checked 2026-09-25).
Caveats · stated by the package
- No full public BOM. The docs landing page offers 'Request the BOM' via a Tally form (https://tally.so/r/jaG0va). The README's BOM links (manual.asimov.inc/v1/bom and docs.menlo.ai/.../select-release-and-bom) returned HTTP 523 and 404 on 2026-09-24. The README-referenced mechanical/FABRICATION_MANIFEST.csv is not committed; it is generated by scripts/generate_fabrication_manifest.py.
- This BOM is reconstructed from public sources: actuator counts from the docs ID table, electronics from the README, system tour and electrical README, cables from the repo wiring CSVs, and fasteners/hardware summed from the 83 'Parts needed' tables in the published assembly steps. Unit prices and vendor URLs are not published, so none are given. The only price is the $20,000 DIY kit.
- Fastener totals are sums of per-step tables. They may be off where the docs reuse or 'carry' bolts between steps (the M4x45 torso bolts were de-duplicated) or where a step omits hardware. 'RPU mounting bolts' has no size.
- The actuator vendor is Encos (docs partner-resources page). The EC-A model numbers come from the docs, but vendor product URLs are not given.
- Fabricated parts: 98 STEP files across CNC 7075 aluminium (A), SLM 316L steel (B) and MJF PA12 (C), per the repo naming_convention.png. The schema's 'sls' is used for both SLM and MJF; see processDetail. Qty is 1 per file because left/right parts have separate part numbers. Part-level quantities, masses and print/machining times are not published.
- The kit comes with some wiring harnesses and the battery 'with attached cable and connector'. Self-sourcing requires building the XT30 (2+2) harnesses from the wiring CSVs. Some joins are made post-assembly with solder or WAGO connectors.
- The powered verification, first boot, kit preparation and module kitting pages are 'coming soon/TBC', so there is no published power-on check yet. The last step is therefore an unpowered integration check.
- The GitHub org shows as both asimovinc and menloresearch; asimovinc/asimov-1 resolves to menloresearch/asimov-1.
Package menlo/asimov@0.1.0 · upstream Asimov 1 (ASV1); repo menloresearch/asimov-1@ccf5326f0adffd65edf930cbbac052454cdd82be (2026-09-21); docs.menlo.ai fetched 2026-09-24 · 16 package sources
Models, repositories, links
6 links- URDFgithub.com/menloresearch/asimov-1/blob/main/sim-model/urdf/asimov_1.urdfmodel
- MJCFgithub.com/menloresearch/asimov-1/blob/main/sim-model/xmls/asimov_1.xmlmodel
- Repogithub.com/menloresearch/asimov-1github.com
- Sitemenlo.ai/asimov-1menlo.ai
- Docsdocs.menlo.ai/asimov/1docs.menlo.ai
- Buymenlo.ai/asimov-1menlo.ai
Videos
1 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Asimov 1
Papers using Asimov 1
20262
- Open source
Menlo Research open-sources Asimov v1
Menlo Research published the Asimov v1 repository, including mechanical designs, electrical wiring and a MuJoCo simulation model.
Menlo ResearchMenlo Asimov 1humanoidsdaily.comopensourceforu.com - Robot
Menlo Research launches Asimov DIY humanoid kit
Menlo Research announced a $15,000 DIY hardware kit for its Asimov open-source humanoid.
Menlo ResearchMenlo Asimov 1humanoidsdaily.com
Sources
last checked 2026-09-24- [1]Official repo READMEgithub.com/menloresearch/asimov-1checked 2026-09-24
- [2]Humanoids Daily kit launchhumanoidsdaily.com/news/asimov-launches-15-000-here-be-dragons-diy-humanoid-kitchecked 2026-09-24
- [3]eWeek (Singapore-based)eweek.com/news/menlo-research-asimov-diy-humanoid-robot-kit/checked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “Menlo Asimov 1 specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/menlo/asimov
Machine-readable: /data.json (record menlo/asimov).