therobotstudio/so-100 · spec sheet
The SO-100 (SO-ARM100) specs
Original Standard Open Arm 100: a 3D-printable 6-DOF low-cost arm that served as the first reference hardware for LeRobot; superseded by the SO-101.
Media
4 items · credited and licensed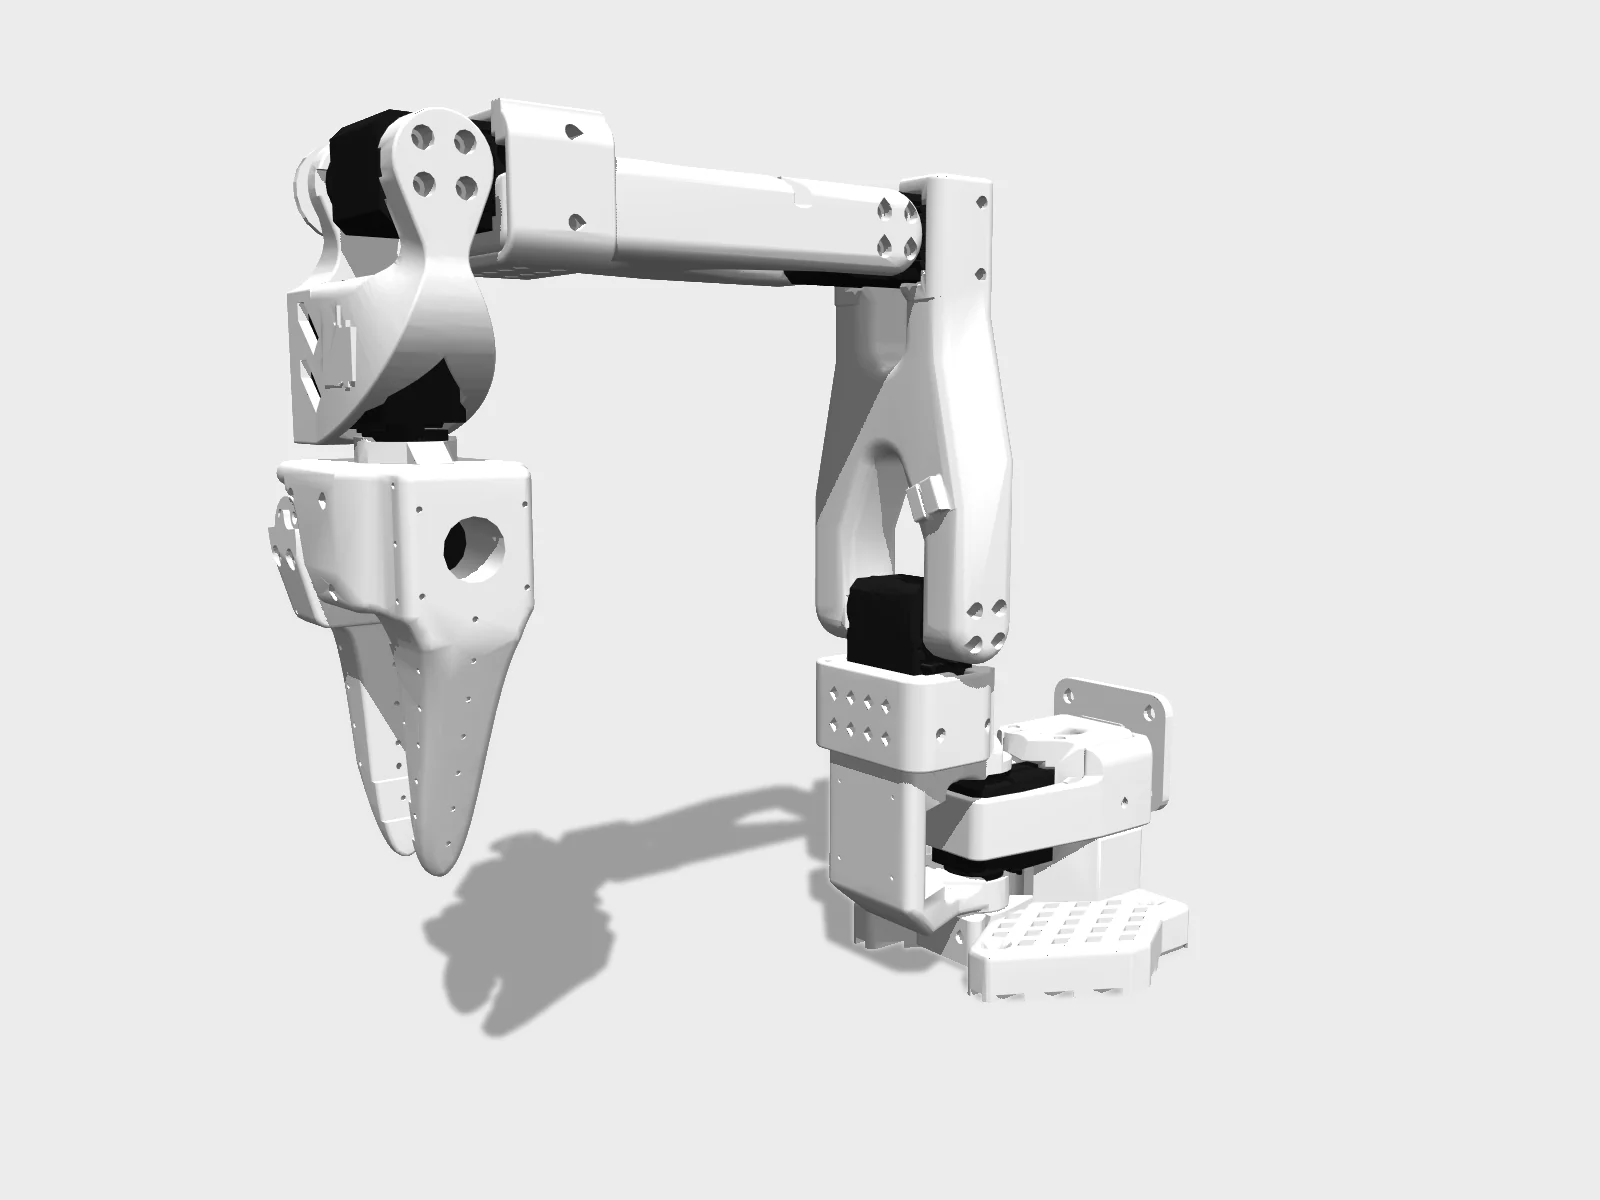 render
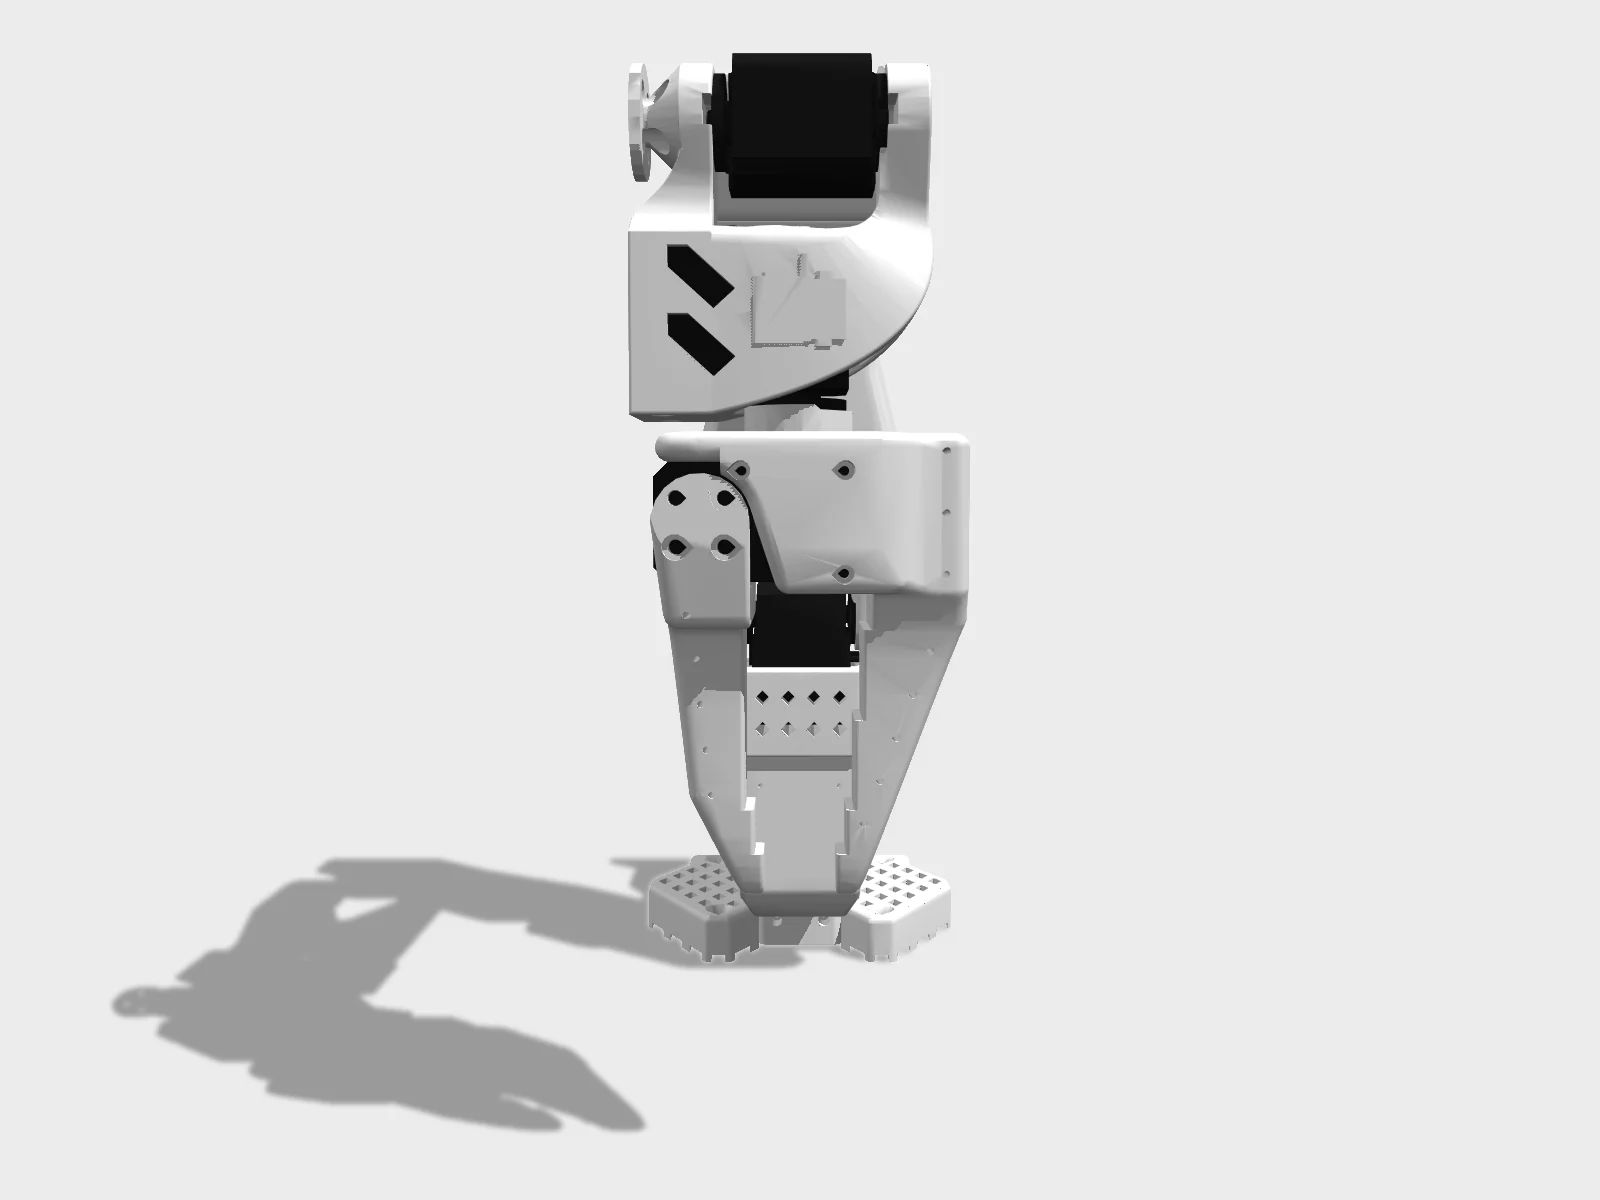 render
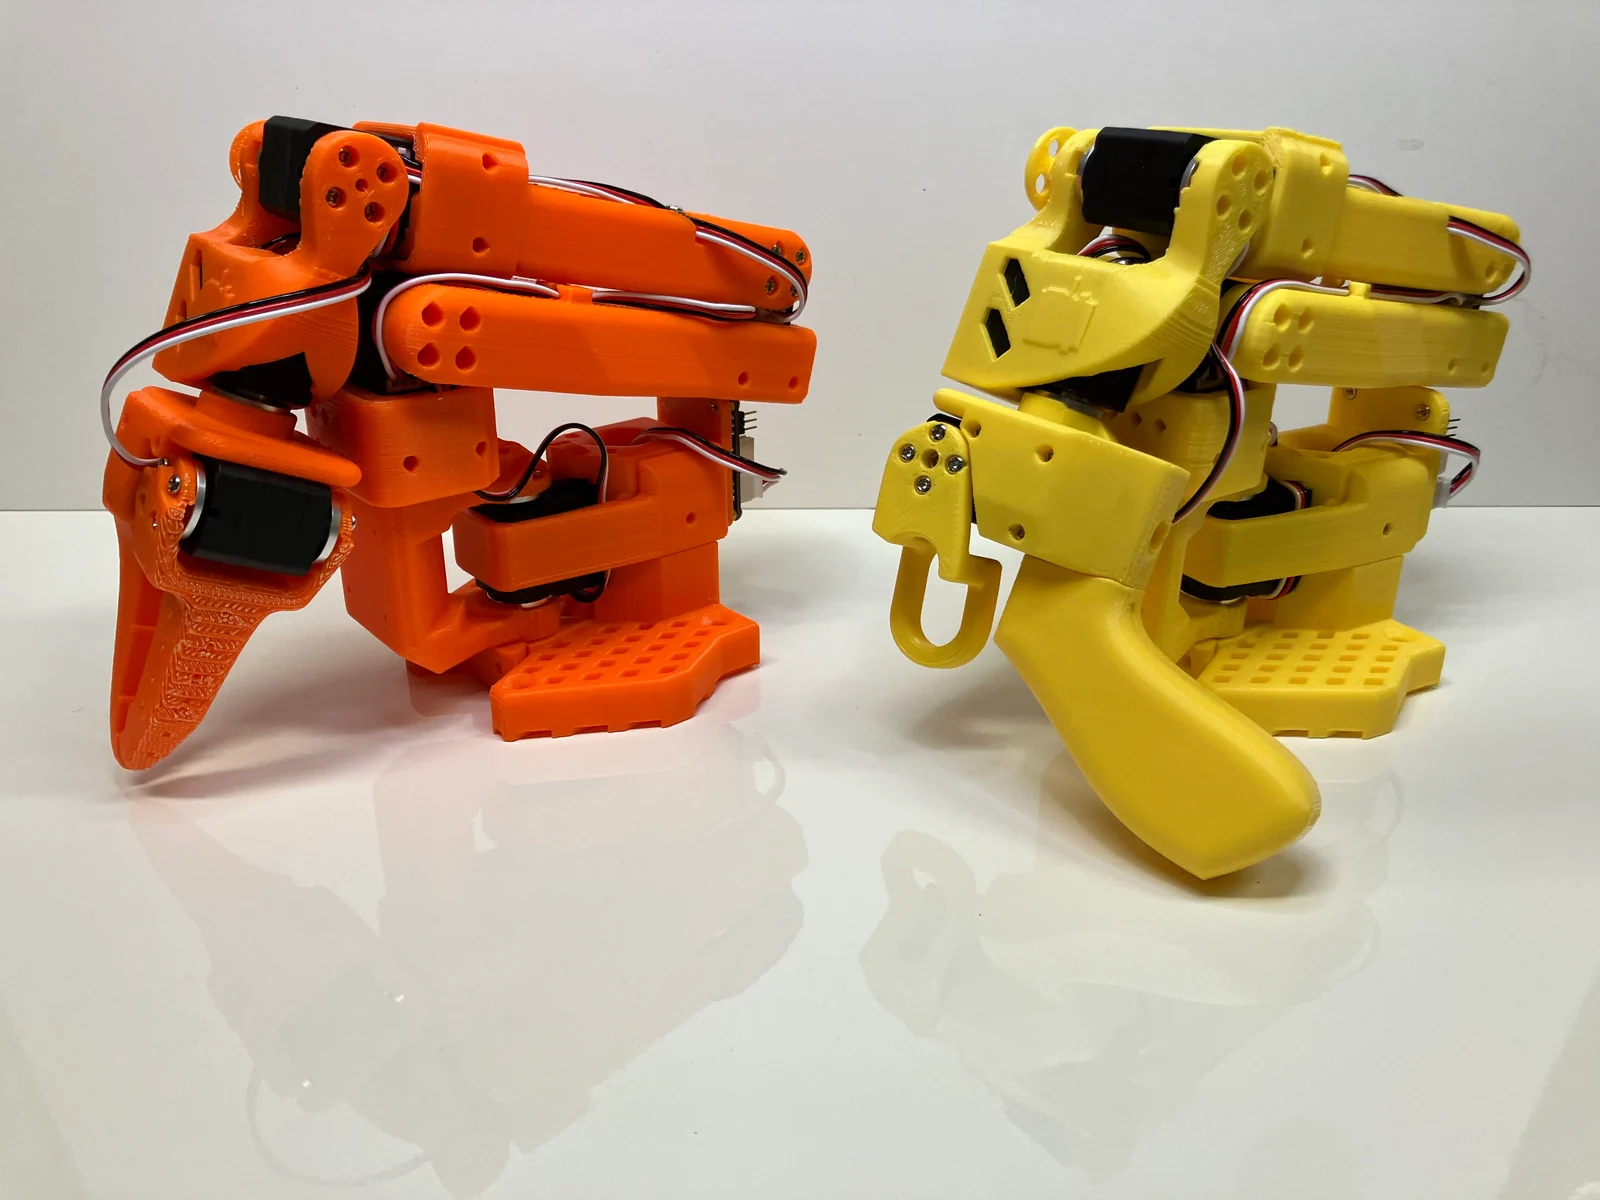

Specifications
2/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | 6 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourced |
| Actuatorsspecs.actuators | Feetech STS3215 serial bus servos |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | unsourced |
| Licenselicense.hw / .sw / .docs | Hardware: Apache-2.0Software: Apache-2.0 |
Note · 'discontinued' = superseded by SO-101 in the same repo (SO100.md kept); files remain available for DIY.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 100 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 1 | 12 | 180 |
| Electronics | 1 | 2 | 22 |
| Power | 1 | 2 | 20 |
| Other | 2 | 2 | 15 |
| Cabling | 1 | 1 | 7 |
| Sensors | 2 | 2 | — |
Offers in CN · EU · US from 6 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 1 | — | — |
| Software | 1 | — | — |
| Motor setup | 3 | — | 3 |
| Leader arm | 2 | — | — |
| Follower arm | 3 | — | — |
| Calibration | 1 | — | 1 |
| First motion | 1 | — | 1 |
| Policy | 1 | — | 1 |
Fabrication: FDM print ×4
Firmware
- Targets
- Feetech STS3215 servo (EEPROM: ID 1-6 and baudrate via lerobot-setup-motors), Waveshare serial bus servo driver (USB bridge, no user firmware)
- Repo
- github.com/huggingface/lerobot
- Calibrate
- lerobot-calibrate --robot.type=so100_follower --robot.port=<port> --robot.id=<id>; lerobot-calibrate --teleop.type=so100_leader --teleop.port=<port> --teleop.id=<id>. Middle pose, Enter, sweep all joints, Enter.
- Notes
- Stock Feetech firmware. In lerobot 0.6.x, so100_follower and so101_follower are registered to the same SOFollower config class (lerobot.robots.so_follower), so SO-100 and SO-101 followers share a driver and calibration flow. Datasets and policies recorded before lerobot 0.5 use a different joint calibration convention (see the LeRobot backward-compatibility guide).
Policies
- SmolVLA base (pretrained VLA to fine-tune on your own SO-100 dataset) · LeRobot (SmolVLA) · huggingface.co450M. Per the SmolVLA paper (arXiv 2506.01844), pretrained on community LeRobot datasets that are mostly SO-100 recordings. The LeRobot docs demo fine-tuning on lerobot/svla_so100_pickplace (50 SO-100 episodes, 5 cube positions). Base model, not zero-shot. Apache-2.0.
- SO-100/101 language-conditioned manipulation (VLA, zero-shot or fine-tune) · LeRobot (MolmoAct2) · huggingface.coLeRobot port of allenai/MolmoAct2-SO100_101 (Ai2), fine-tuned on an SO-100/101 mixture with absolute joint-pose control. The LeRobot docs use an so100_follower example with top and side cameras mapped to cam0/cam1. The processor includes the pre-0.5 calibration sign/offset fix. No license on the model card.
Caveats · stated by the package
- Superseded. The SO-ARM100 README marks the SO-100 docs as deprecated and points new builds to the SO-101 (improved wiring, no gear removal, purpose-geared leader servos). The files remain for existing arms and DIY.
- SO-100 vs SO-101: SO-100 leader servos are standard 7.4 V STS3215 with the gears removed by hand, while the SO-101 leader uses intact 1/191 and 1/147 geared servos. SO-100 motor IDs must be set before assembly because the connectors are hard to reach afterwards. The SO-100 gripper motor takes 3 screws per side, the SO-101 2. The two use different STL sets (SO_ARM100_08k vs *_SO101), and some SO-101 add-ons, such as the hex-nut wrist camera mount, are stated not to fit the SO-100.
- USD prices are the SO100.md figures (two-arm total $232, 244€, ¥1343.16) and exclude printing and cameras. The two-arm servo line links a 6-pack listing while the unit price is per servo.
- The table-clamp row in SO100.md is misaligned: a ¥9.2 TaoBao entry sits in the EU columns and there is no EU link.
- SO100.md footnotes 1-3 (servo, power supply, screwdriver) are referenced but not present in the file. Its printing links point to /stl_files_for_3dprinting/..., which no longer exists; the files are now under STL/SO100/.
- The upstream BOM has no fastener line. Screws are not itemised and the SO-100 assembly text gives no screw sizes (the SO-101 guide uses M2x6 and M3x6).
- Cameras are not in the core BOM; the camera lines come from the optional mount guides and are marked optional.
Package therobotstudio/so-100@0.1.0 · upstream TheRobotStudio/SO-ARM100@5f6d2b876a53a4872e405b991dd925556c9e38a4 (2026-09-23): SO100.md, STL/SO100, STEP/SO100 (CAD version SO_ARM100_08k, CHANGELOG v0.1.13); huggingface/lerobot@e624f3f7f8411ec3a02635d06e79373341e5ef35 (2026-09-24, lerobot 0.6.2): docs/source/so100.mdx, il_robots.mdx; huggingface.co/docs/lerobot/so100 as of 2026-09-25 · 13 package sources
Models, repositories, links
7 links- URDFgithub.com/TheRobotStudio/SO-ARM100/tree/main/Simulation/SO100model
- MJCFgithub.com/google-deepmind/mujoco_menagerie/tree/main/trs_so_arm100model
- Menageriemujoco_menagerie/trs_so_arm100model
- Repogithub.com/TheRobotStudio/SO-ARM100github.com
- Repogithub.com/huggingface/lerobotgithub.com
- Sitegithub.com/TheRobotStudio/SO-ARM100github.com
- Docshuggingface.co/docs/lerobot/so100huggingface.co
Videos
2 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning SO-100 (SO-ARM100)
Papers using SO-100 (SO-ARM100)
20251
- Open source
Hugging Face and The Robot Studio launch SO-101
SO-101 succeeded the SO-100 as the low-cost, 3D-printable leader-follower arm for LeRobot, with improved wiring and easier assembly.
Hugging FaceThe SO-101 (SO-ARM101)The SO-100 (SO-ARM100)hackster.iogithub.com
Sources
last checked 2026-09-25- [1]GitHub repogithub.com/TheRobotStudio/SO-ARM100checked 2026-09-24
- [2]Hackster: SO-101 as next-gen of SO-100hackster.io/news/hugging-face-launches-the-so-101-an-upgraded-low-cost-3d-printable-autonomous-robot-arm-532360f441ebchecked 2026-09-24
- [3]LeRobot SO-100 docshuggingface.co/docs/lerobot/so100checked 2026-09-25
Suggest a correction
Related
Nearest by size (height, mass)
Also by The Robot Studio / Hugging Face
Compare
Cite this page
humanoidrobots.systems. “The SO-100 (SO-ARM100) specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/therobotstudio/so-100
Machine-readable: /data.json (record therobotstudio/so-100).