therobotstudio/so-101 · spec sheet
The SO-101 (SO-ARM101) specs
Low-cost 3D-printable 6-DOF leader/follower arm pair built for Hugging Face's LeRobot framework; successor to the SO-100 with improved wiring and easier assembly.
Media
4 items · credited and licensed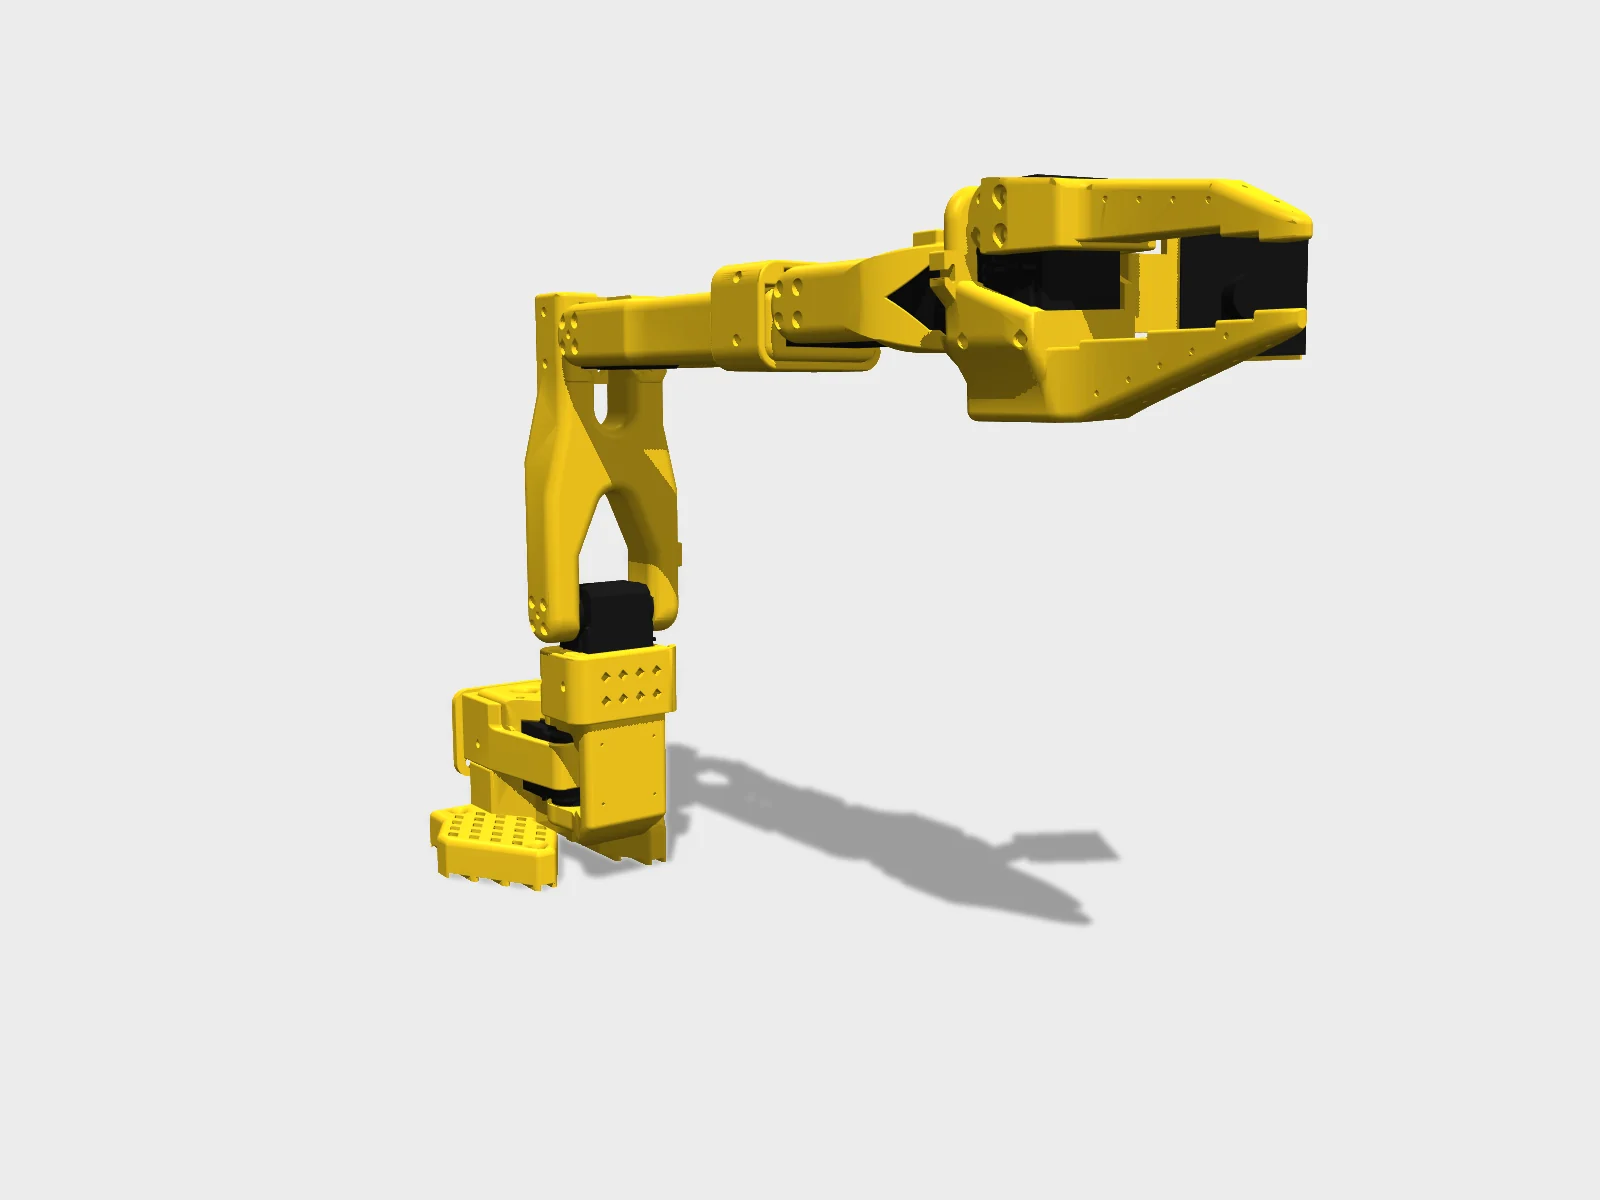 render
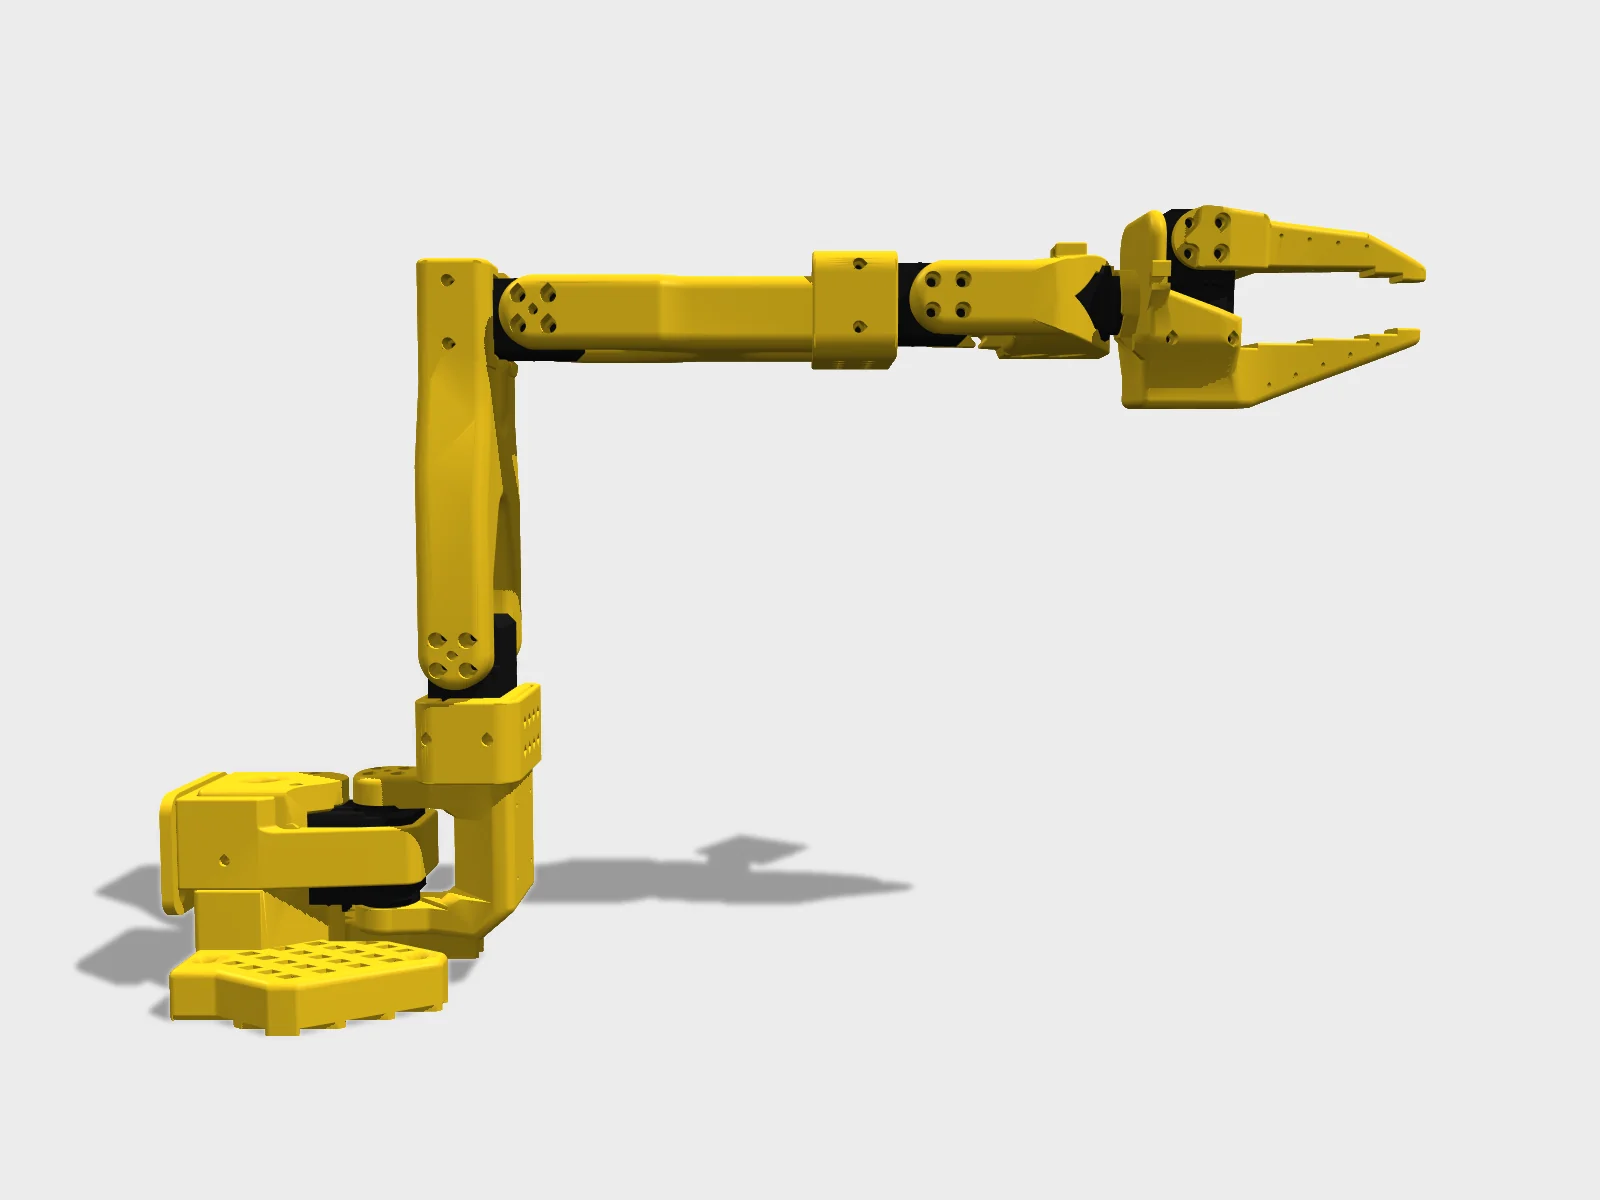 render
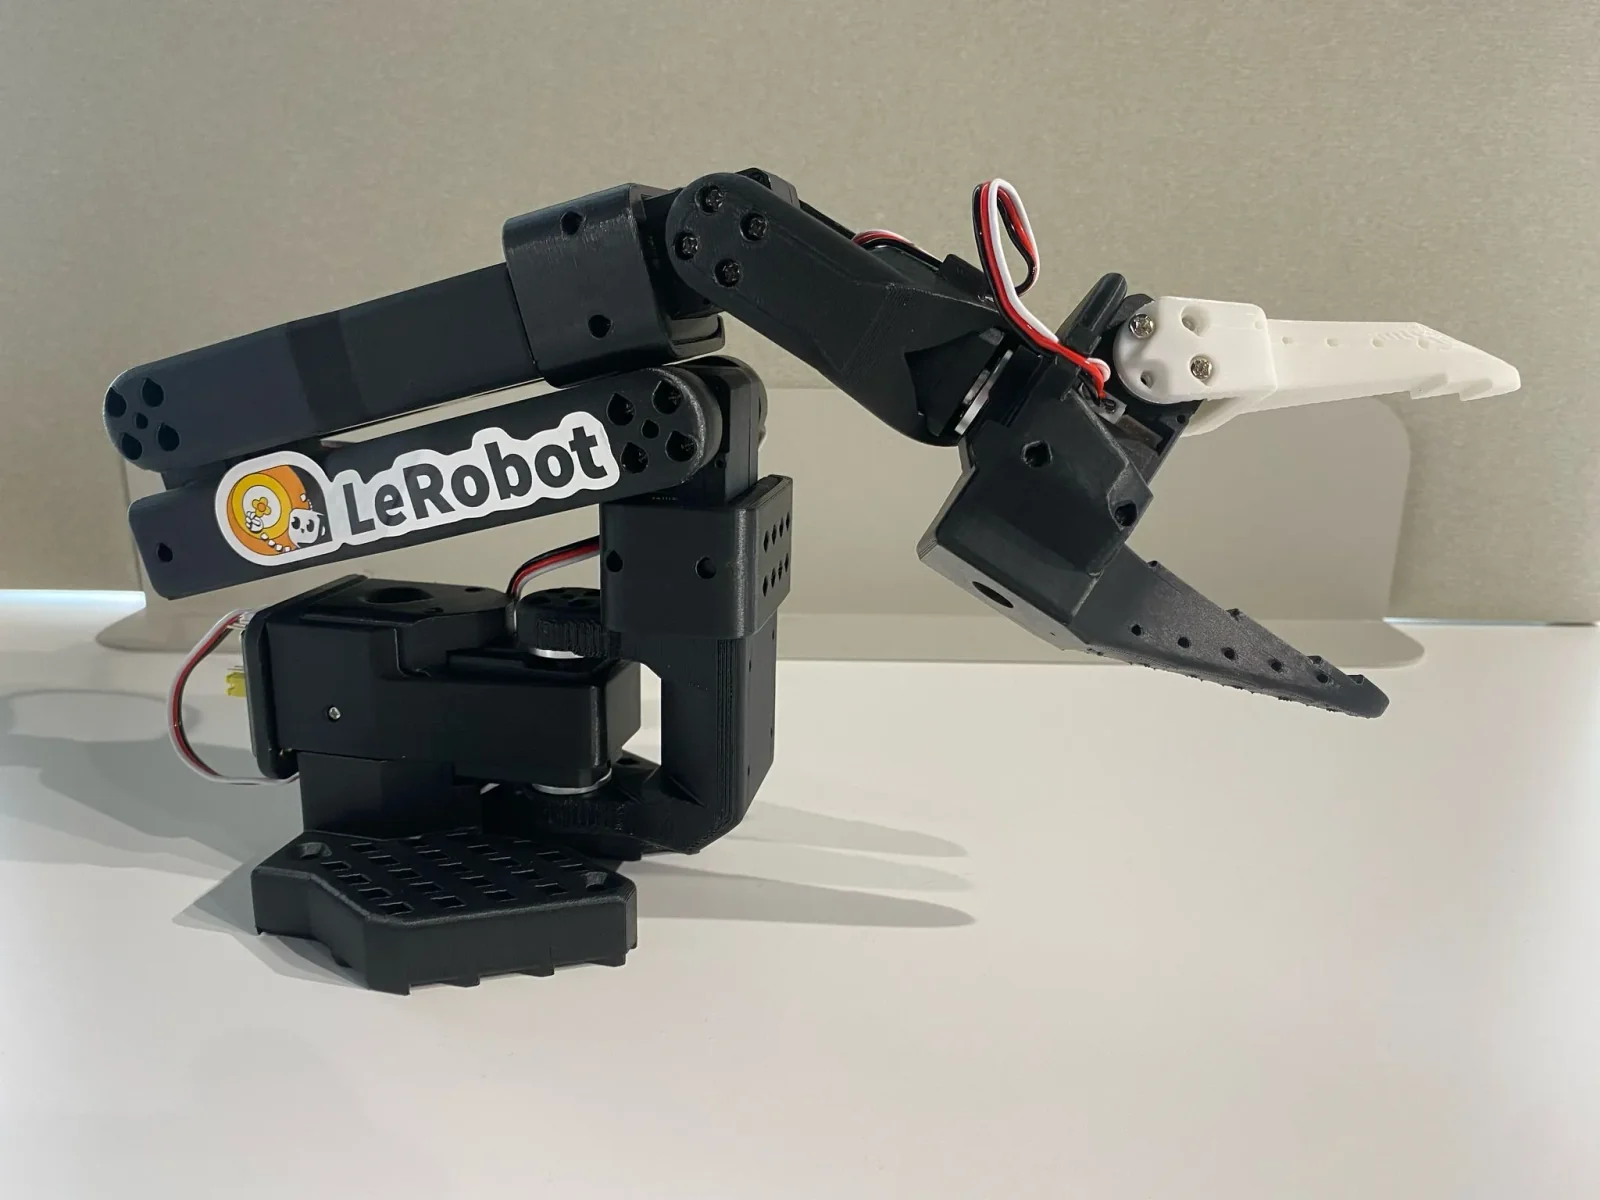

Specifications
4/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | 6 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | 220USDSeeed motor kit $220 (Standard) / $240 (Pro) for a leader+follower pair; printed parts ~$35 extra; DIY from ~$130 |
| Actuatorsspecs.actuators | Feetech STS3215 serial bus servos (7.4 V or 12 V follower options) |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2025 |
| Licenselicense.hw / .sw / .docs | Hardware: Apache-2.0Software: Apache-2.0 |
Note · Reference arm of the LeRobot ecosystem; many community-trained policies for it are on the Hugging Face Hub. Repo very active (pushed Sep 2026). Maker city not public on GitHub (country FR only).
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 100 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 3 | 12 | 167 |
| Electronics | 1 | 2 | 21 |
| Power | 1 | 2 | 20 |
| Other | 2 | 2 | 15 |
| Cabling | 1 | 1 | 7 |
| Sensors | 2 | 2 | — |
Offers in CN · EU · GLOBAL · US from 8 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 3 | 60 | — |
| Software | 1 | — | — |
| Motor setup | 4 | — | 3 |
| Follower arm | 4 | — | — |
| Leader arm | 2 | — | — |
| Calibration | 2 | — | 1 |
| First motion | 1 | — | 1 |
| Cameras | 1 | — | — |
| Policy | 3 | — | 1 |
Fabrication: FDM print ×17
Firmware
- Targets
- Feetech STS3215 servo (EEPROM: ID 1-6 and bus baudrate, written by lerobot-setup-motors), Waveshare / Seeed serial bus servo driver board (USB serial bridge, no user firmware)
- Repo
- github.com/huggingface/lerobot
- Calibrate
- lerobot-calibrate --robot.type=so101_follower --robot.port=<port> --robot.id=<id>, then lerobot-calibrate --teleop.type=so101_leader --teleop.port=<port> --teleop.id=<id>. Middle-of-range pose, Enter, sweep all joints except wrist_roll, Enter.
- Notes
- No custom firmware: servos keep Feetech firmware and LeRobot (lerobot.robots.so_follower, lerobot.teleoperators.so_leader) talks to them over the serial bus. so100_follower and so101_follower are the same config class in LeRobot 0.6.x. Optional debug tools: Feetech FD software (Windows, https://www.feetechrc.com/software.html) or FT_SCServo_Debug_Qt (Ubuntu). The repo also has a WebUI 3-point calibration guide (Software/WEBUI_CALIBRATION.md) that references a pi_servo_studio.py script and a --webui flag not found in the repo or in lerobot 0.6.2.
Policies
- Generalist SO-101 pick and place (world action model, fine-tune with the included LoRA recipe) · LeRobot (Flux3Policy) · huggingface.coBlack Forest Labs FLUX 3 Action, 7B. Trained on the SO-101 episodes of lerobot/community_dataset_v3. Two cameras (scene + wrist), 6-D joint-delta actions with absolute gripper, 30 Hz. FLUX Kommunity License: non-commercial use unless you are a qualifying user; needs a large GPU.
- SO-100/101 language-conditioned manipulation (VLA, zero-shot or fine-tune) · LeRobot (MolmoAct2) · huggingface.coLeRobot port of allenai/MolmoAct2-SO100_101, fine-tuned by Ai2 on an SO-100/101 mixture with absolute joint-pose control. Cameras map to cam0/cam1 via --rename_map. The processor includes the joint sign/offset fix for the pre-0.5 calibration convention. No license field on either model card.
- SmolVLA base (pretrained VLA to fine-tune on your own SO-101 dataset) · LeRobot (SmolVLA) · huggingface.co450M. Per the SmolVLA paper (arXiv 2506.01844), pretrained on community LeRobot datasets that are mostly SO-100 recordings; not meant to run zero-shot. Fine-tune with `lerobot-train --policy.path=lerobot/smolvla_base`. Apache-2.0.
Caveats · stated by the package
- BOM USD unit prices are the upstream README figures (two-arm total $229.88, €226.3, ¥1343.16, ¥44,530) and exclude printed parts and cameras. Alibaba and Amazon listings change often.
- The follower comes in two servo options: 7.4 V STS3215 (16.5 kg·cm stall at 6 V, less on the 5 V supply) or 12 V STS3215 (30 kg·cm), which also needs a 12 V 5 A+ supply. The SO-101 leader is always 7.4 V. Upstream found 7.4 V sufficient.
- Leader gear ratios are easy to mix up. C001 (1/345) is also the follower part; the leader needs 2x C044 (1/191) on joints 1 and 3 and 3x C046 (1/147) on joints 4-6. Upstream lists no CN (TaoBao) link for C044 or C046.
- The upstream BOM has no fastener line. Assembly uses M2x6 and M3x6 screws, and the optional mount guides refer to the M2 screws 'that came with your Feetech servos'. Check your servos include horn and case screws before ordering.
- Cameras are not in the core BOM, but you need at least one to record datasets or run vision policies. The camera lines here come from the optional mount guides and are marked optional.
- Japanese vendor links (Akizuki Denshi, Amazon.co.jp) are shown as region GLOBAL because the registry has no JP region.
- Kits exist (RobotEd CH, Robonine, PartaBot US, ForgeMotion Labs US, Seeed Studio, WowRobo, RoboSEasy KR, NeoBot CN, Autodiscovery EU), sold as frame, electronics, complete or assembled kits. See the README 'Kits' list; this package covers the DIY path.
- Hub policies: flux-3-action-so101 is non-commercial by default (FLUX Kommunity License). MolmoAct2 SO100_101 states no license. smolvla_base is a base model that must be fine-tuned. None of them report success rates on your setup, so each needs matching camera names and a calibrated arm.
- The repo's Software/WEBUI_CALIBRATION.md describes a WebUI calibration (`python pi_servo_studio.py` / `lerobot-calibrate --webui`) that is in neither the SO-ARM100 repo nor lerobot 0.6.2. Use the standard lerobot-calibrate flow.
Package therobotstudio/so-101@0.1.0 · upstream TheRobotStudio/SO-ARM100@5f6d2b876a53a4872e405b991dd925556c9e38a4 (2026-09-23); huggingface/lerobot@e624f3f7f8411ec3a02635d06e79373341e5ef35 (2026-09-24, lerobot 0.6.2): docs/source/so101.mdx, il_robots.mdx, smolvla.mdx; huggingface.co/docs/lerobot/so101 as of 2026-09-25 · 16 package sources
Models, repositories, links
8 links- URDFgithub.com/TheRobotStudio/SO-ARM100/tree/main/Simulation/SO101model
- MJCFgithub.com/google-deepmind/mujoco_menagerie/tree/main/robotstudio_so101model
- Menageriemujoco_menagerie/robotstudio_so101model
- Repogithub.com/TheRobotStudio/SO-ARM100github.com
- Repogithub.com/huggingface/lerobotgithub.com
- Sitegithub.com/TheRobotStudio/SO-ARM100github.com
- Docshuggingface.co/docs/lerobot/so101huggingface.co
- Buyseeedstudio.com/SO-101-Low-Cost-AI-Arm-Kit-Pro-p-6427.htmlseeedstudio.com
News and papers
0 stories · 0 papersNews mentioning SO-101 (SO-ARM101)
Papers using SO-101 (SO-ARM101)
20251
- Open source
Hugging Face and The Robot Studio launch SO-101
SO-101 succeeded the SO-100 as the low-cost, 3D-printable leader-follower arm for LeRobot, with improved wiring and easier assembly.
Hugging FaceThe SO-101 (SO-ARM101)The SO-100 (SO-ARM100)hackster.iogithub.com
Sources
last checked 2026-09-25- [1]GitHub repo (Apache-2.0, BOM)github.com/TheRobotStudio/SO-ARM100checked 2026-09-24
- [2]Hackster: SO-101 launchhackster.io/news/hugging-face-launches-the-so-101-an-upgraded-low-cost-3d-printable-autonomous-robot-arm-532360f441ebchecked 2026-09-24
- [3]CNX Software: SO-ARM101 kit pricingcnx-software.com/2025/05/02/so-arm101-open-source-dual-robotic-arm-kit-works-with-hugging-faces-lerobot/checked 2026-09-24
- [4]LeRobot SO-101 docshuggingface.co/docs/lerobot/so101checked 2026-09-25
Suggest a correction
Related
Nearest by size (height, mass)
Also by The Robot Studio / Hugging Face
Compare
Cite this page
humanoidrobots.systems. “The SO-101 (SO-ARM101) specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/therobotstudio/so-101
Machine-readable: /data.json (record therobotstudio/so-101).