hyperspawn/dropbear · spec sheet Flagship open platform · featured placement, scores computed
Hyperspawn Dropbear specs
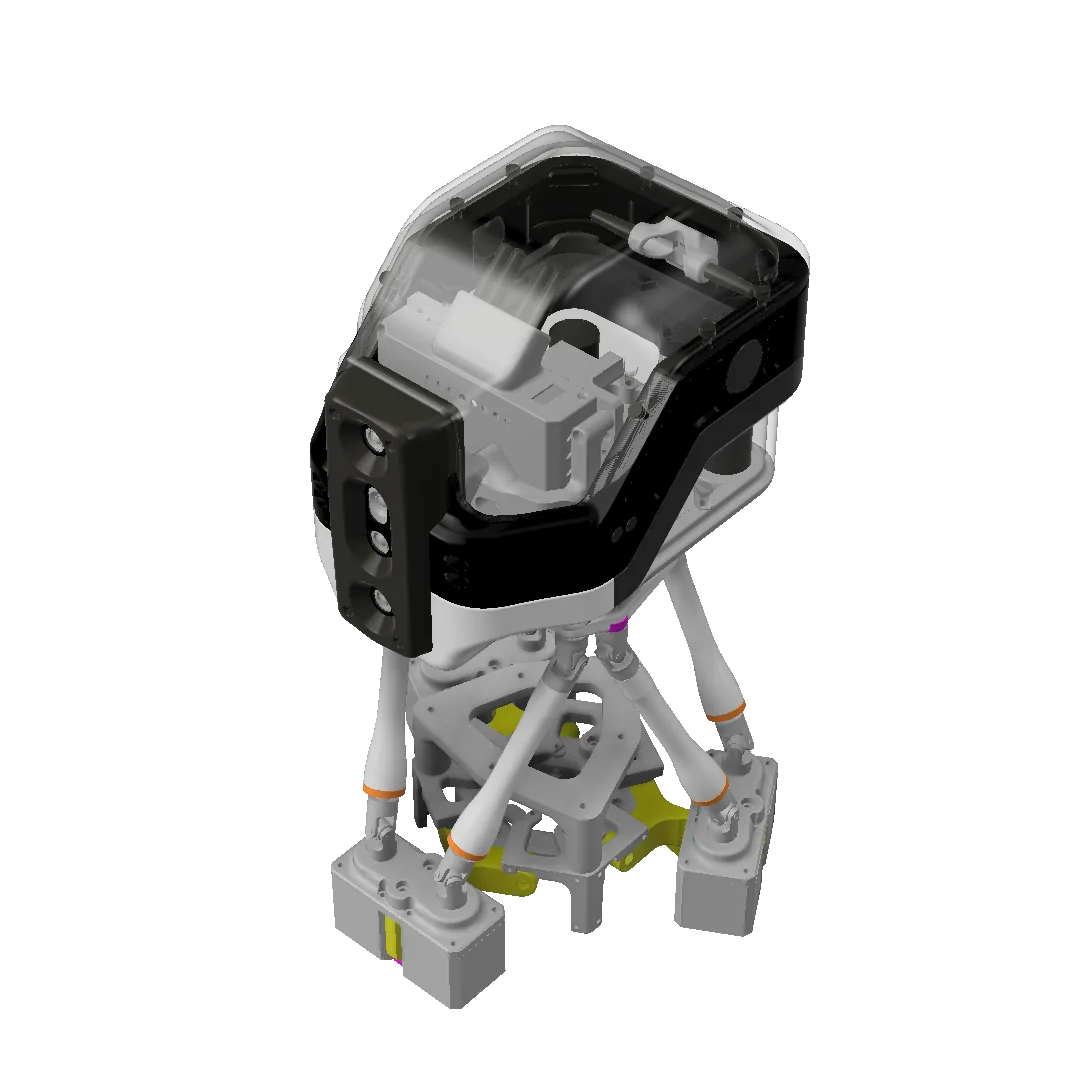
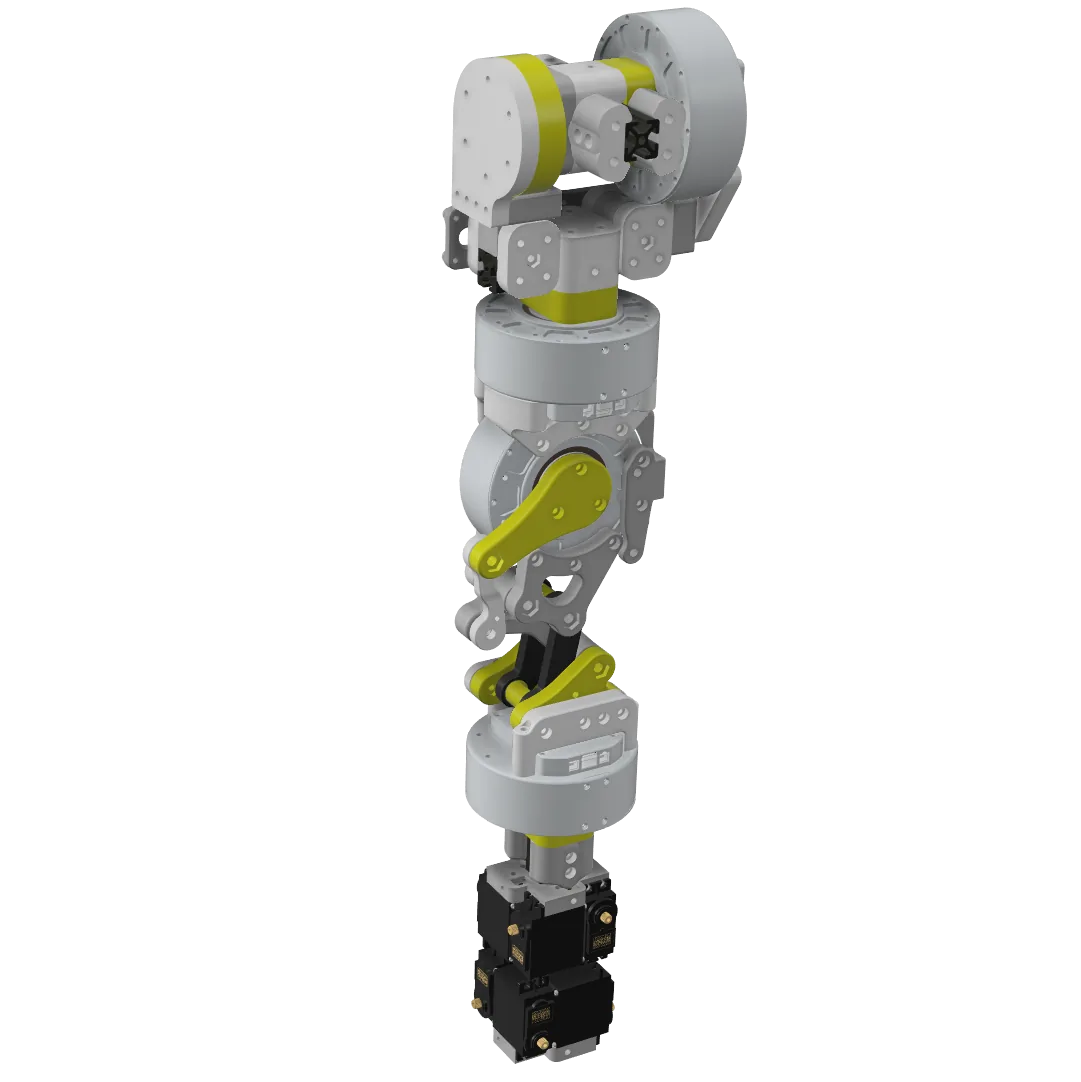
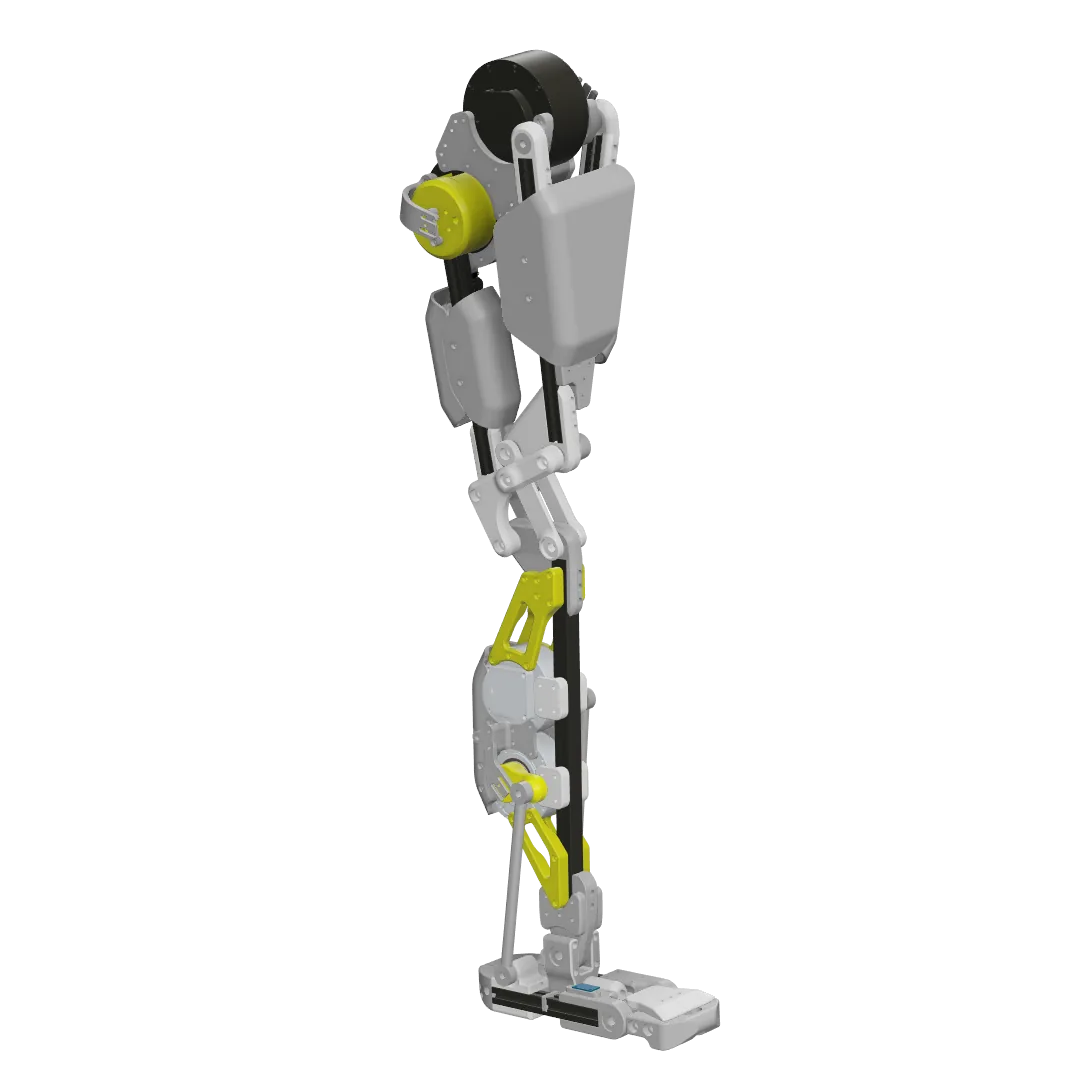
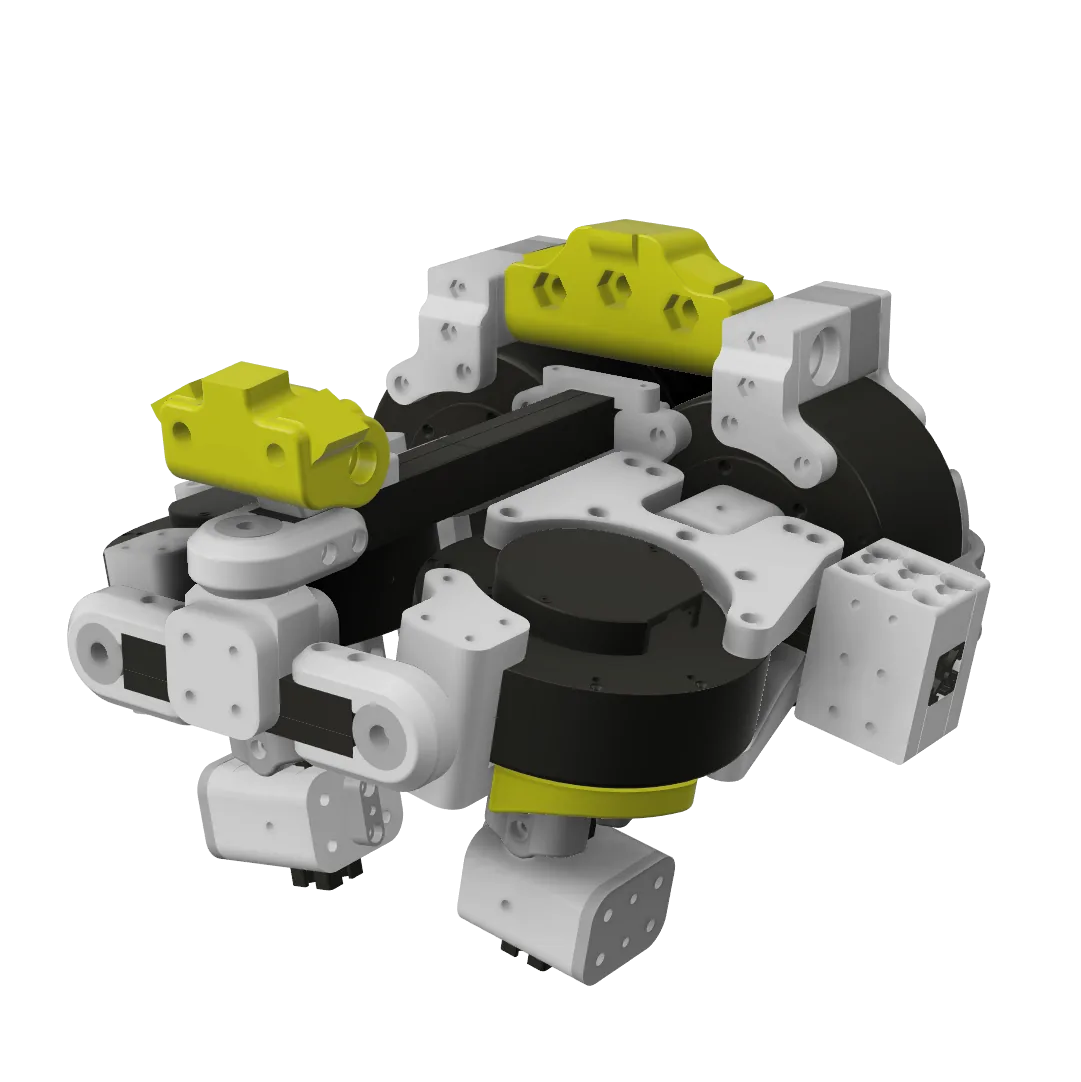
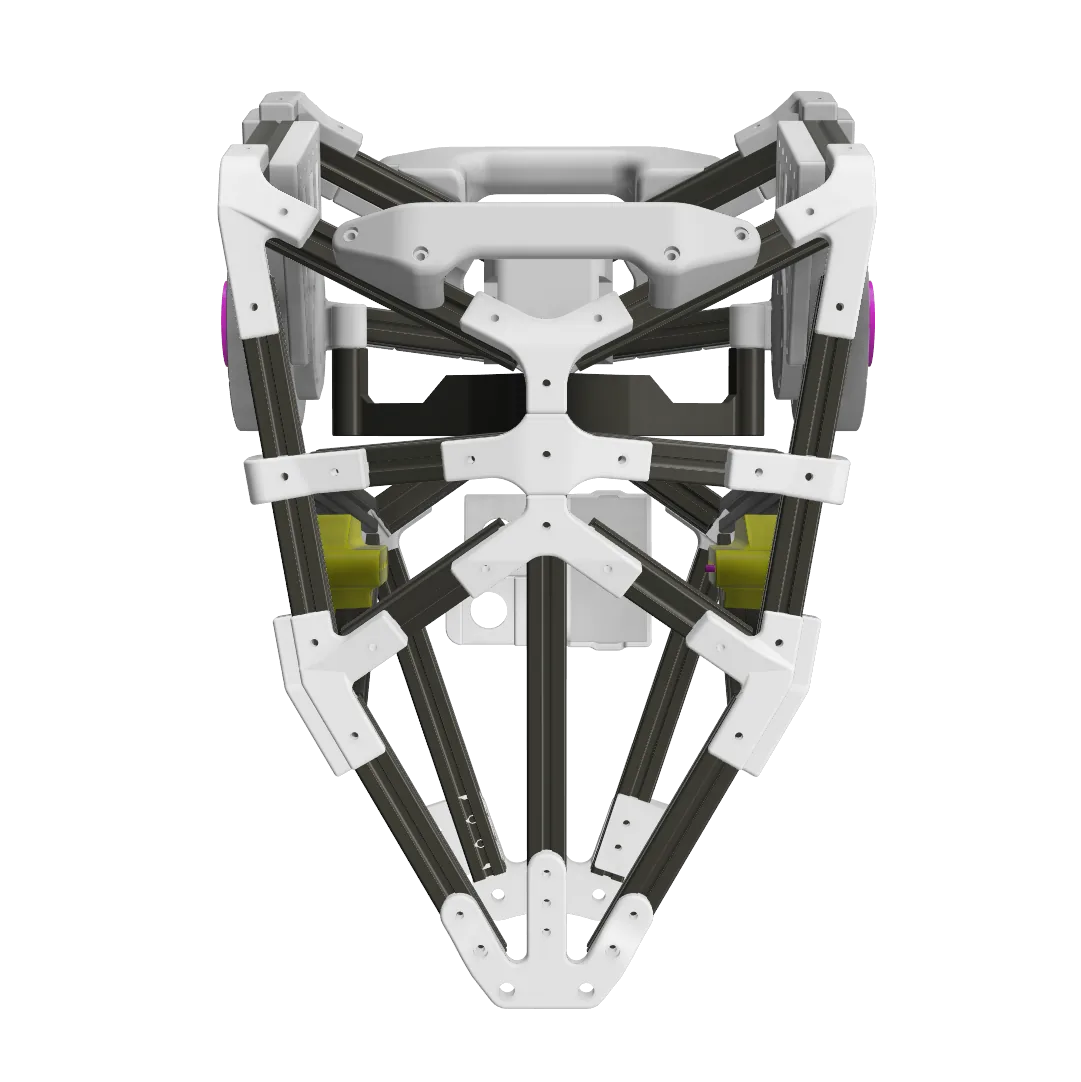
Full-size open-source humanoid from Hyperspawn and Pointblank: FDM-printed structure on 20x20 aluminium extrusion, MyActuator CAN actuators, an ESP32 node per limb and a Jetson Orin brain. CAD, BOM, printables, firmware, URDF/MJCF/USD and simulation walking policies are public; a pre-assembled kit is on preorder.
Media
16 items · credited and licensed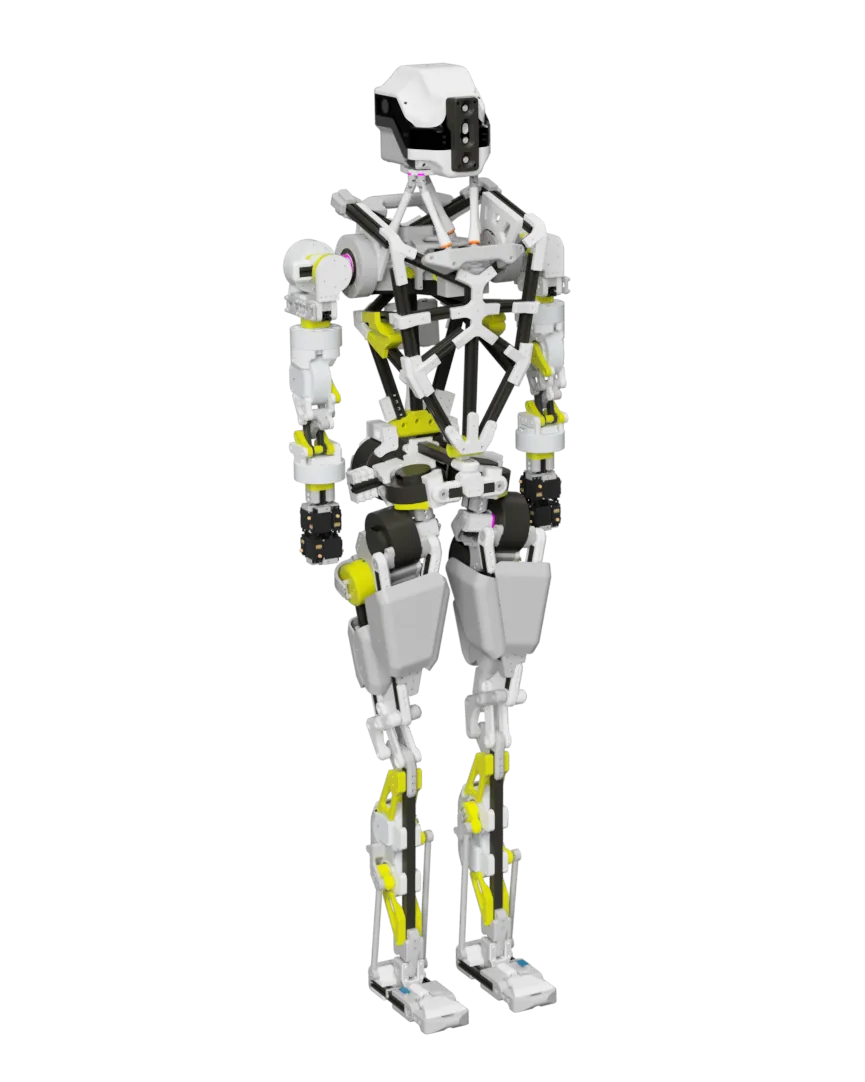 render
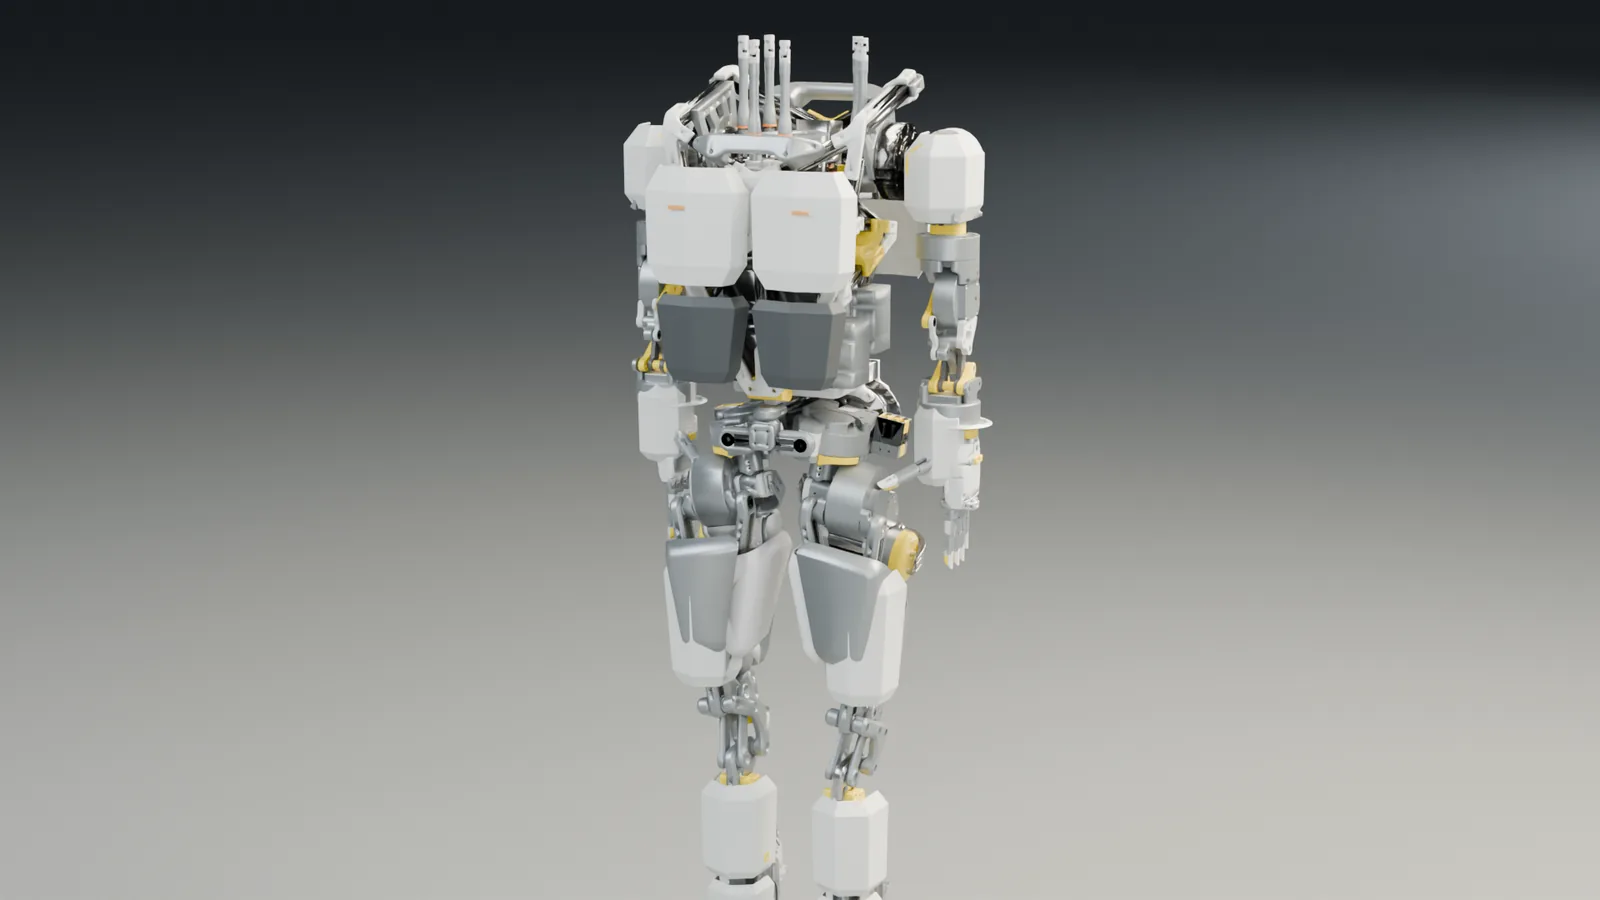 render
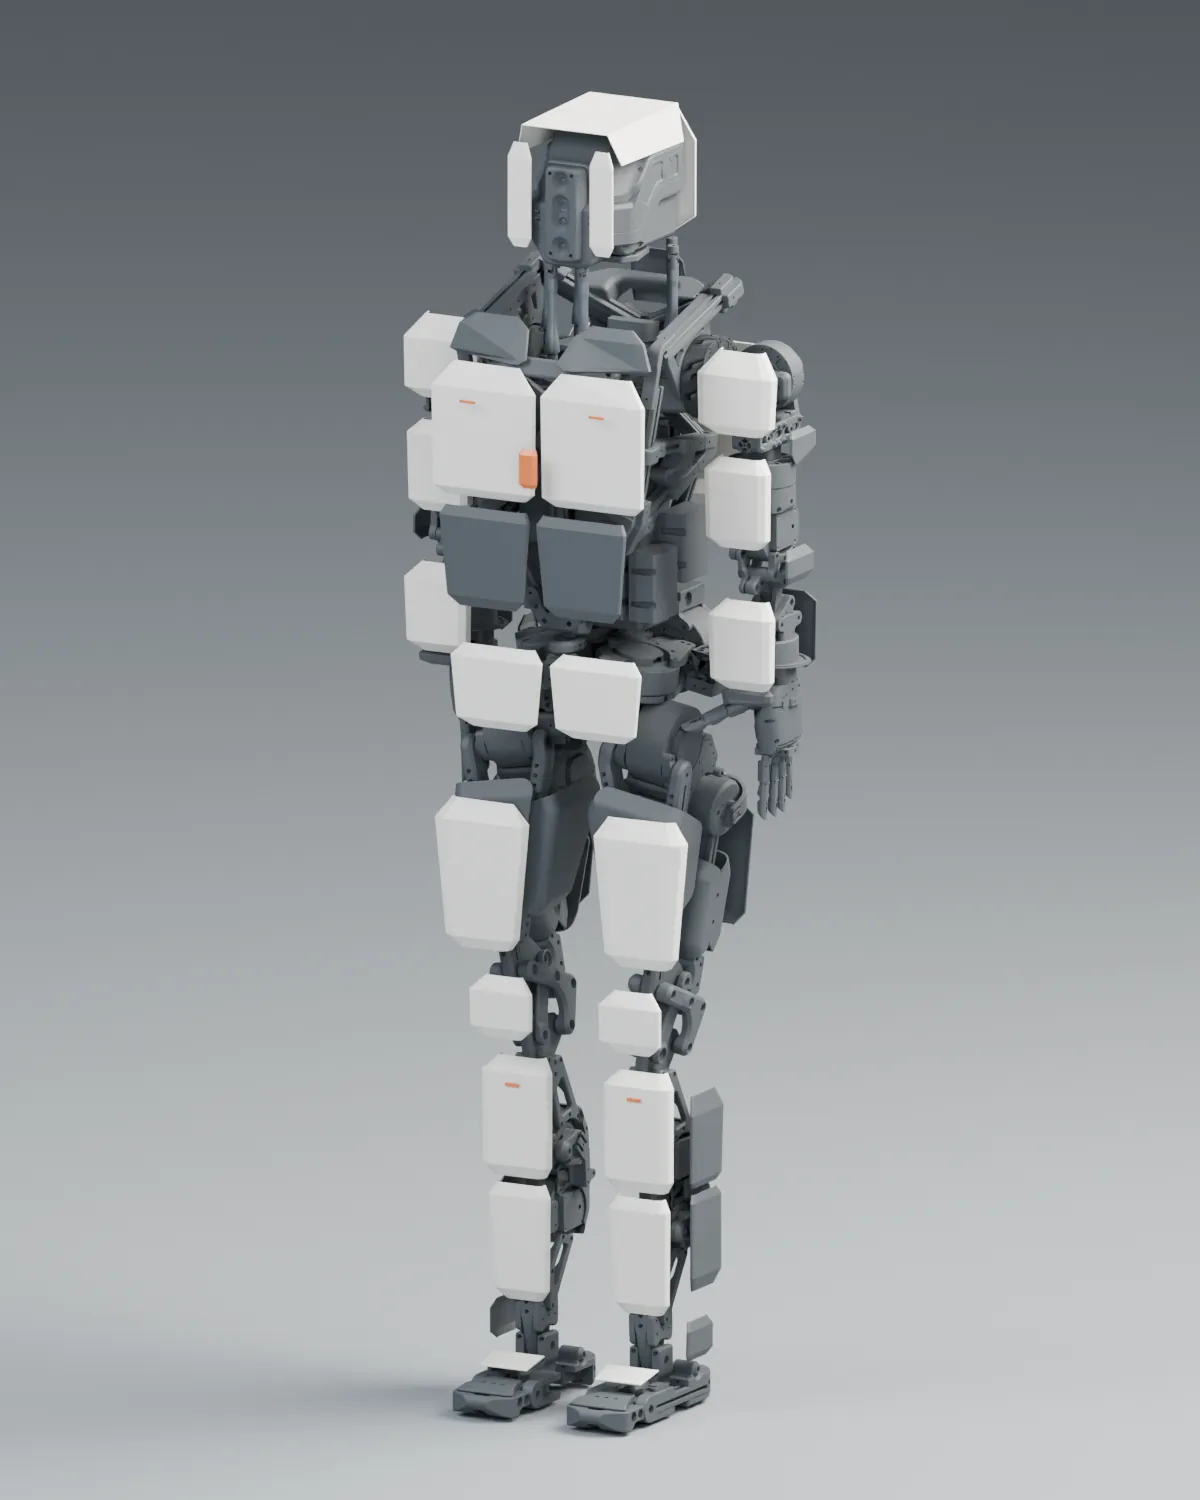 render
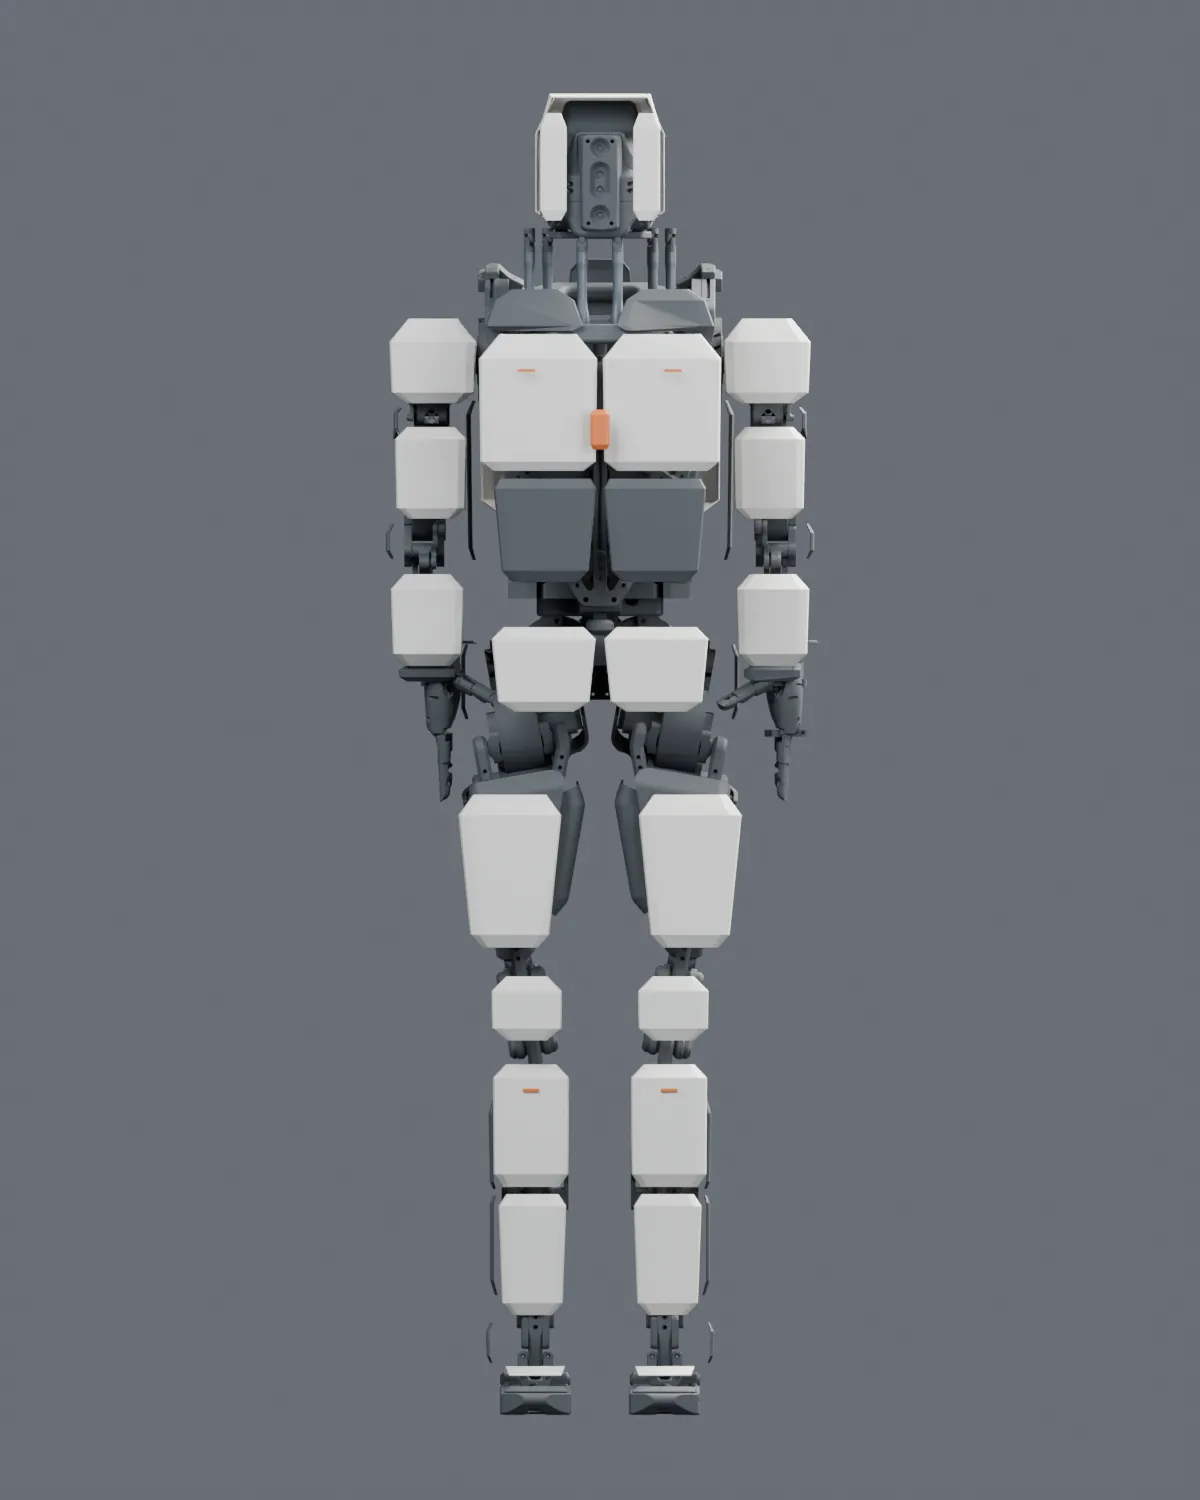 render
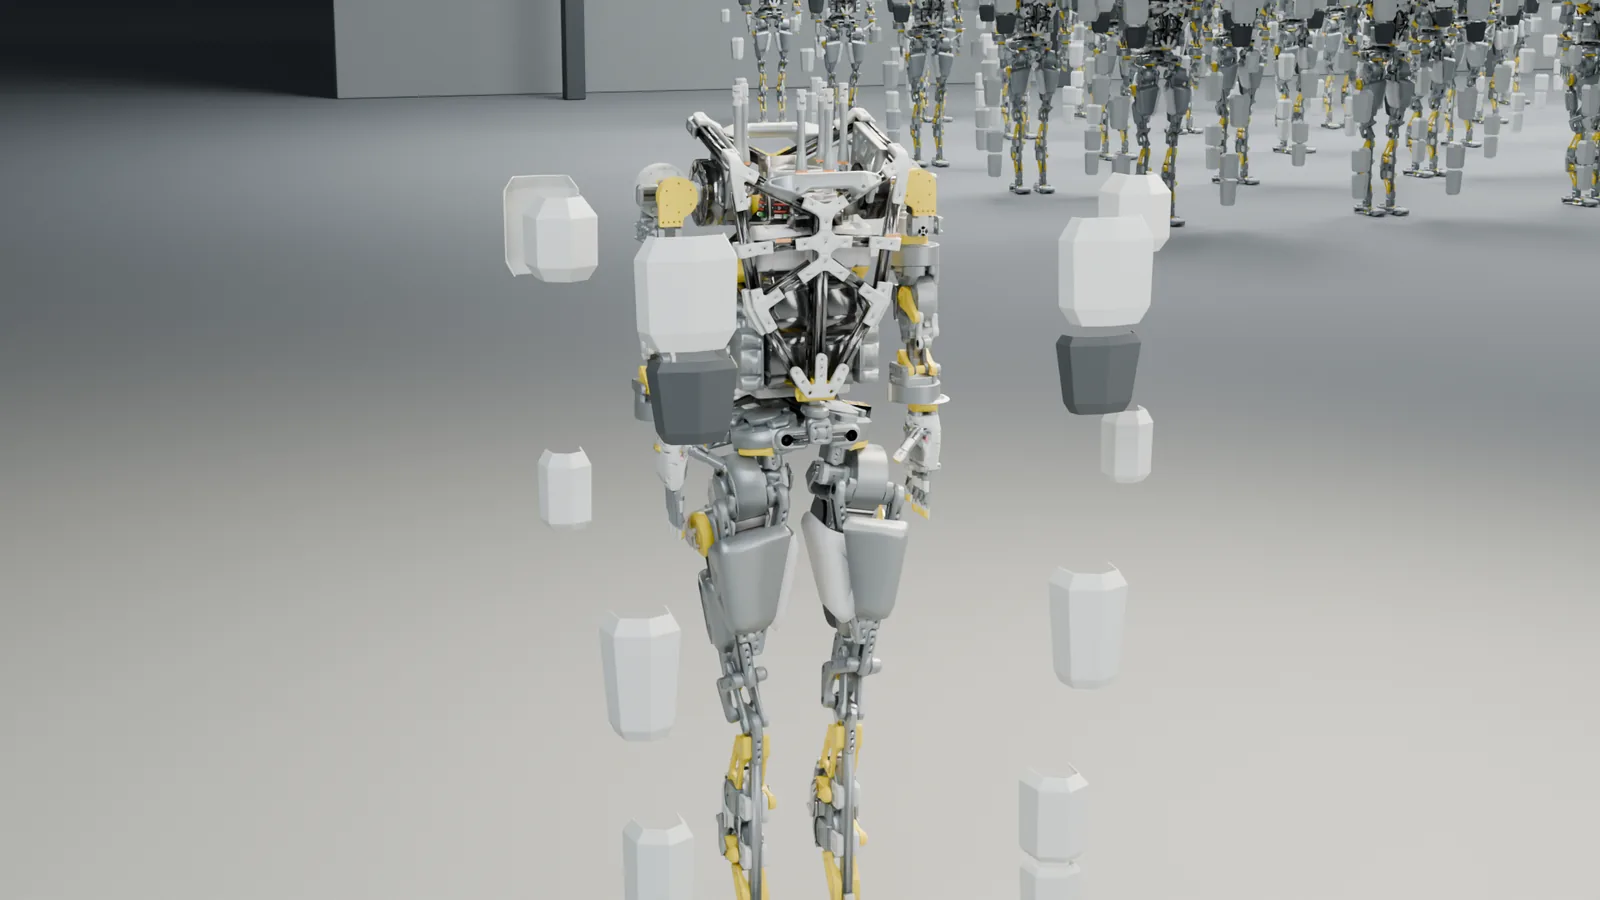 render
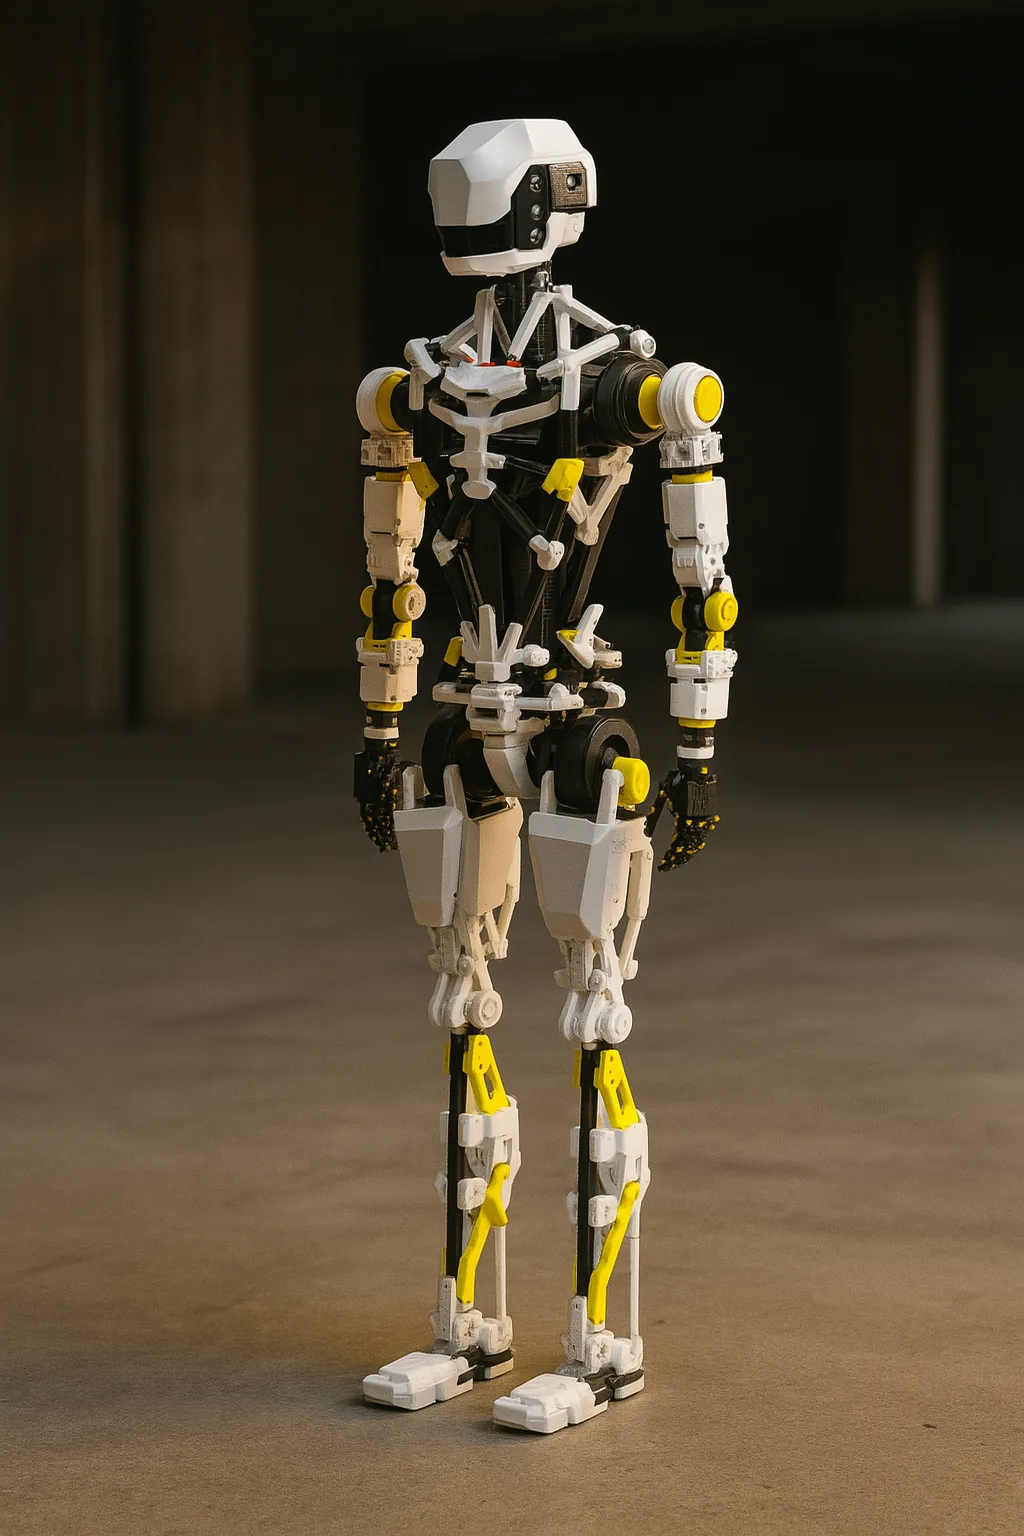 render
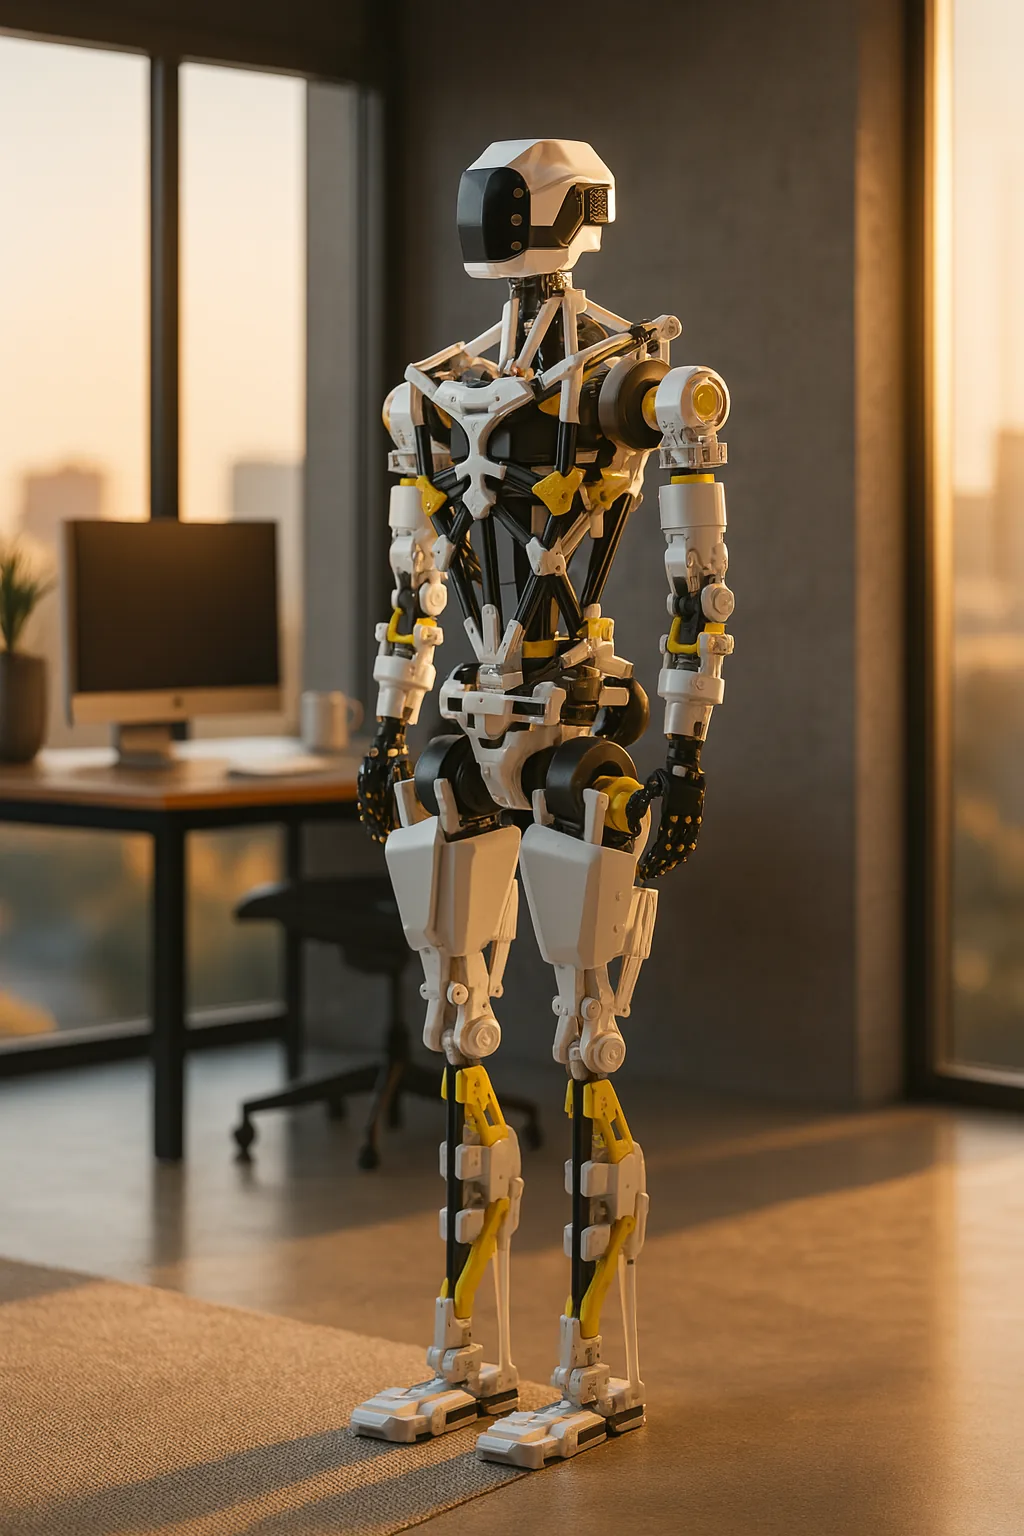 render
 render
 render
 render
 render
 render
Specifications
11/12 fields sourced| Heightspecs.heightCm | 180cm |
|---|---|
| Massspecs.massKg | 45kg |
| Degrees of freedomspecs.dof | 32 |
| Payloadspecs.payloadKg | 5kg |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | 120min |
| Battery capacityspecs.batteryWh | 960Wh |
| Pricespecs.priceUsd | 9,999USDPre-assembled kit, $500 refundable deposit, ships Q2 2027 (first 500 units) per hyperspawn.ai. Options: five-finger hand +$1,000, Jetson Orin compute +$2,000, advanced policies +$4,000, covered shell +$500. Self-sourced BOM ~$10,400 (~$8,900 with a Jetson Orin NX); hyperspawn.ai quotes $1.5–3k in parts for a source build, which does not match the BOM. |
| Actuatorsspecs.actuators | MyActuator RMD-X10, RMD-X8, RMD-X6 and CEM-60 over 1 Mbit/s CAN (18 per the 2026 BOM; myactuator-can lists 12 RMD-X8 Pro, 4 RMD-X10 V3, 6 CEM-60); 6 NEMA 17 lead-screw steppers in the Stewart-platform neck. hyperspawn.ai: servo + QDD. |
| Computespecs.compute | NVIDIA Jetson AGX Orin 64GB (BOM; Orin NX 16GB alternative) plus one ESP32-DevKitC-V4 CAN node per limb. Kit: Raspberry Pi 5 base, Jetson Orin advanced. |
| Sensorsspecs.sensors | Intel RealSense D455f depth camera, IMU (center-IMU controller role), foot load cells (4x HX711 per foot, dropbear-feet), actuator encoders; five AS5600 magnetic angle sensors per leg controller (observation-safe firmware) |
| Year introducedyear | 2023 |
| Licenselicense.hw / .sw / .docs | Hardware: MIT AND LicenseRef-Hyperspawn-LicenseSoftware: MIT AND CC-BY-NC-SA-4.0Docs: MIT |
Note · Reference implementation of the ORP spec; gets no ranking advantage anywhere in the suite. Three ways to get one: preorder the assembled kit ($9,999, $500 deposit, Q2 2027), self-source from the open BOM, or print and build from the repos. Level 2 (sim-verified), not 4: no physical walking is published and the locomotion repo calls its policies simulation releases; the v0.1.0 policy passed 128/128 zero-fall 20 s trials at 0.20 m/s in sim, so no top speed is listed. Spec sources conflict and the most recent official statement (hyperspawn.ai, 2026) is used: 1.8 m (home page says 6 ft), 45 kg (URDF sums to 47.7 kg, MJCF to 34.0 kg), 32 DOF (dropbear_firmware configures 31 joints across 6 limb nodes; the locomotion policy drives 14), 48 V battery (home-page label reads 24 V), 2–4 h runtime (lower bound stored). Battery energy is the BOM's 48 V 20 Ah pack. Licenses: most sub-repos are MIT (bom.md's footer says CC BY 4.0); the main Dropbear repo uses the non-commercial Hyperspawn License; dropbear-locomotion (code, weights, USD, media) is CC BY-NC-SA 4.0.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 100 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 5 | 24 | 6,630 |
| Compute | 1 | 1 | 1,999 |
| Sensors | 2 | 9 | 399 |
| Power | 6 | 7 | 293 |
| Structure | 16 | 132 | 238 |
| Electronics | 12 | 45 | 238 |
| Fasteners | 44 | 1,298 | 104 |
| Cabling | 8 | 23 | 47 |
Offers in CN · EU · GLOBAL · IN · US from 13 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 10 | 570 | 1 |
| Left leg | 3 | 450 | — |
| Right leg | 1 | 420 | — |
| Feet | 2 | 480 | — |
| Pelvis | 3 | 210 | — |
| Torso | 4 | 420 | 1 |
| Arms | 3 | 780 | — |
| Head | 3 | 240 | — |
| Electrical | 3 | 420 | 2 |
| Firmware | 3 | 165 | 1 |
| Bring-up | 5 | 540 | 4 |
Fabrication: FDM print ×256
Firmware
- Targets
- left_arm, right_arm, left_leg, right_leg, head, torso, neck (Dropbear-Neck-Assembly), feet (dropbear-feet pressure.ino)
- Repo
- github.com/Hyperspawn/dropbear_firmware
- Calibrate
- Set actuator IDs (0x79) and zero (0x64) with myactuator-can, then verify joint directions against the URDF using the observation-safe image before any motion.
- Notes
- dropbear_firmware: PlatformIO / Arduino on ESP32-DevKitC-V4, SN65HVD230 transceivers, one shared 1 Mbit/s CAN bus, node IDs 0x10-0x15, 500 Hz joint state, 1 Hz heartbeat; CI builds all six limb environments. Per-limb joints: arms 7, legs 6, head 3, torso 2 (31 total). The main Dropbear repo keeps the original low-level controllers: the Behemoth universal image (left leg, right leg, center IMU or head/neck role from persistent config), a hybrid PWM/CAN leg controller, an observation-only image and a legacy leg controller; its partitions.csv gives the app 2.5 MiB. robit-man/dropbear_control provides a browser digital twin and a guarded firmware uploader that checks the partition table.
Policies
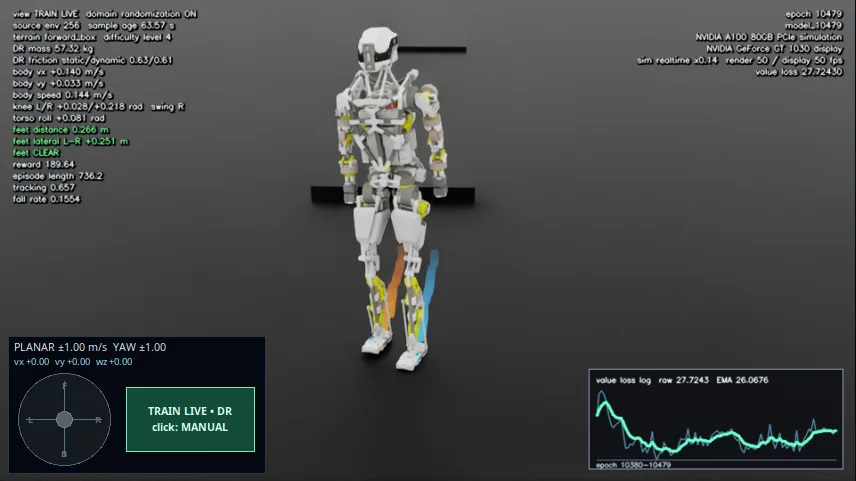
- walk, flat ground (v0.1.0, validated in sim) · Isaac Lab + RSL-RL PPO · github.comONNX actor; keep policy.onnx.data beside it. 58 inputs, 14 joint-position actions at 50 Hz. 128/128 zero-fall 20 s trials at 0.20 m/s (forward, backward, left, right) on a plane, pushes off. TorchScript policy.pt and the full model_8745.pt are alongside. CC BY-NC-SA 4.0: non-commercial.
- walk over low obstacles (v0.2.0, experimental) · Isaac Lab + RSL-RL PPO · github.comAdds a 104-value terrain-height scan (162 inputs). Trained on 3-14 cm boxes at +0.20 m/s; not converged, no deterministic evaluation yet (84.5% time-outs at the last update). CC BY-NC-SA 4.0: non-commercial.
Caveats · stated by the package
- The Dropbear README says build files, docs and control software evolve at different speeds; match revisions before ordering parts or powering anything.
- Actuator sources disagree. bom.md (2026-04) lists 4 RMD-X10, 4 RMD-X8, 4 RMD-X6 and 6 CEM-60; myactuator-can and the 2025 BOM list 12 RMD-X8 Pro, 4 RMD-X10 and 6 CEM-60; parts of dropbear_docs (hardware roll-up, pelvis guide, hands) still describe Dynamixel servos. The 2026 BOM is used for quantities and prices here.
- Joint counts disagree: hyperspawn.ai says 32 DOF, dropbear_firmware configures 31 joints on 6 nodes, the 2026 BOM supplies 18 CAN actuators plus 6 neck steppers, and the locomotion policy drives 14.
- Print totals are ours, not the maker's: slicing the seven repo plates with their embedded settings gives about 460 h and 11.6 kg of PLA for 294 parts on 41 plates. dropbear_docs estimates ~180 h and ~8 kg. Per-part hours and grams split each plate's sliced total by part volume.
- Material guidance conflicts: dropbear_docs suggests PLA+ for 90% of parts, print_settings.md validated the plates in PLA, and the printables README prefers PETG/ABS (PLA for prototypes only).
- The STLs/ folders (352 files) use different file names from the .3mf plates and include parts that are not on any plate; the plates are used here as the print list.
- bom.md prices are the maker's approximate 2024-2025 retail figures and most vendor links are search pages. Subsystem subtotals don't match the line items, and the ~$10,400 total differs from hyperspawn.ai's '$1.5-3k in parts' for a source build.
- Electronics, calibration, testing and operations docs are marked 'coming soon'. No wiring diagram or PCB is published (dropbear_electronics holds only a README).
- Feet and neck live in separate repos (dropbear-feet, Dropbear-Neck-Assembly) and are not in bom.md; their lines here come from those READMEs without prices.
- No hardware stand or walking procedure is published. The locomotion policies are simulation results only, and dropbear-locomotion (code, weights, USD) is CC BY-NC-SA 4.0, non-commercial.
- The main Dropbear repo uses the non-commercial Hyperspawn License; most sub-repos are MIT. bom.md's footer says CC BY 4.0 while the repo LICENSE is MIT.
Package hyperspawn/dropbear@0.2.0 · upstream dropbear_bom@78f932c (2026-04-07); dropbear_printables@c5ad307 (2025-07-17); dropbear_docs@1c9ebcc (2025-09-09); dropbear_firmware@main (2026-04-07); myactuator-can@main (2025-10); Dropbear-Neck-Assembly@main; dropbear-feet@main; dropbear-locomotion v0.2.1 (2026-07-27) · 16 package sources
Models, repositories, links
35 links- URDFgithub.com/Hyperspawn/dropbear_urdfmodel
- MJCFgithub.com/Hyperspawn/dropbear_mjcf/blob/main/dropbear_mjcf.xmlmodel
- USDgithub.com/Hyperspawn/dropbear-locomotion/blob/main/dropbear_walk/isaaclab_asset/dropbear.usdmodel
- Repogithub.com/Hyperspawn/Dropbeargithub.com
- Repogithub.com/Hyperspawn/dropbear_hardwaregithub.com
- Repogithub.com/Hyperspawn/dropbear_printablesgithub.com
- Repogithub.com/Hyperspawn/dropbear_bomgithub.com
- Repogithub.com/Hyperspawn/dropbear_docsgithub.com
- Repogithub.com/Hyperspawn/dropbear_electronicsgithub.com
- Repogithub.com/Hyperspawn/dropbear_firmwaregithub.com
- Repogithub.com/Hyperspawn/Dropbear-Neck-Assemblygithub.com
- Repogithub.com/Hyperspawn/dropbear-feetgithub.com
- Repogithub.com/Hyperspawn/dropbear_urdfgithub.com
- Repogithub.com/Hyperspawn/dropbear_mjcfgithub.com
- Repogithub.com/Hyperspawn/dropbear_simgithub.com
- Repogithub.com/Hyperspawn/dropbear_gazebogithub.com
- Repogithub.com/Hyperspawn/dropbear_isaacgithub.com
- Repogithub.com/Hyperspawn/dropbear_rlgithub.com
- Repogithub.com/Hyperspawn/dropbear-locomotiongithub.com
- Repogithub.com/Hyperspawn/dropbear_rosgithub.com
- Repogithub.com/Hyperspawn/dropbear_rvizgithub.com
- Repogithub.com/Hyperspawn/dropbear_braingithub.com
- Repogithub.com/Hyperspawn/dropbear_teleopgithub.com
- Repogithub.com/Hyperspawn/dropbear_sim2realgithub.com
- Repogithub.com/Hyperspawn/dropbear_testinggithub.com
- Repogithub.com/Hyperspawn/dropbear_mediagithub.com
- Repogithub.com/Hyperspawn/myactuator-cangithub.com
- Repogithub.com/Hyperspawn/actuator-testbenchgithub.com
- Repogithub.com/Hyperspawn/openqdd-hsgithub.com
- Repogithub.com/Hyperspawn/opencycloid-hsgithub.com
- Repogithub.com/robit-man/dropbear_controlgithub.com
- Sitehyperspawn.ai/hyperspawn.ai
- Docsgithub.com/Hyperspawn/dropbear_docsgithub.com
- Buyhyperspawn.ai/buyhyperspawn.ai
- Videovtv7xitynucitt4l.public.blob.vercel-storage.com/robots/hyperspawn/dropbear/sim-walk-v020.mp4vtv7xitynucitt4l.public.blob.vercel-storage.com
Videos
0 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Dropbear
Papers using Dropbear
20262
- Company
Hyperspawn takes Dropbear kit reservations
As checked on 2026-09-25, hyperspawn.ai offers the Dropbear kit at $9,999 with a $500 refundable deposit, limited to 500 first-edition units shipping in Q2 2027. The site does not state when reservations opened. Building from the open files remains free.
Hyperspawn Dropbearhyperspawn.aihyperspawn.ai - Open source
Hyperspawn publishes Dropbear locomotion policies
Hyperspawn published dropbear-locomotion, Isaac Lab and RSL-RL PPO training for Dropbear walking, with a v0.1.0 checkpoint. Its published evaluation runs 128 simulated episodes with a fall rate of 0. These are simulation results; no physical walking is published.
Hyperspawn Dropbeargithub.comgithub.com
20252
- Open source
Hyperspawn publishes Dropbear Isaac Sim and Isaac Lab repos
Hyperspawn created dropbear_isaac and dropbear_rl on GitHub for training and simulating Dropbear in NVIDIA Isaac Sim and Isaac Lab.
Hyperspawn Dropbeargithub.comapi.github.com - Open source
Hyperspawn splits Dropbear into per-subsystem repositories
Hyperspawn created separate GitHub repositories for Dropbear's CAD (dropbear_hardware), bill of materials (dropbear_bom), printable parts (dropbear_printables), firmware, electronics, build docs, URDF and MJCF models (all MIT) and a Gazebo simulation, plus a MyActuator CAN driver (myactuator-can, MIT).
Hyperspawn Dropbeargithub.comapi.github.comapi.github.com
20231
- Open source
Hyperspawn opens the Dropbear repository
Hyperspawn created Hyperspawn/Dropbear on GitHub, the public home of its open-source, 3D-printed Dropbear humanoid.
Hyperspawn Dropbeargithub.comapi.github.com
Sources
last checked 2026-09-25- [1]hyperspawn.ai: configure & preorder (price, deposit, ship date, specs)hyperspawn.ai/buychecked 2026-09-25
- [2]hyperspawn.ai: Dropbear spec sheethyperspawn.ai/docs/robots/dropbearchecked 2026-09-25
- [3]hyperspawn.ai home (6 ft / 45 kg / 32 joints)hyperspawn.ai/checked 2026-09-25
- [4]hyperspawn.co (legacy domain, same site)hyperspawn.co/checked 2026-09-25
- [5]Dropbear main repo READMEgithub.com/Hyperspawn/Dropbearchecked 2026-09-25
- [6]dropbear_bom / bom.md (2026-04 pricing)github.com/Hyperspawn/dropbear_bom/blob/main/bom.mdchecked 2026-09-25
- [7]dropbear_docsgithub.com/Hyperspawn/dropbear_docschecked 2026-09-25
- [8]dropbear_printables (.3mf plates, print settings)github.com/Hyperspawn/dropbear_printableschecked 2026-09-25
- [9]dropbear_firmware CAN config (6 limb nodes, 31 joints)github.com/Hyperspawn/dropbear_firmware/blob/main/docs/can_config.mdchecked 2026-09-25
- [10]myactuator-can (actuator list, CAN IDs, limits)github.com/Hyperspawn/myactuator-canchecked 2026-09-25
- [11]Dropbear-Neck-Assembly (6-DOF stepper neck)github.com/Hyperspawn/Dropbear-Neck-Assemblychecked 2026-09-25
- [12]dropbear-feet (load-cell feet)github.com/Hyperspawn/dropbear-feetchecked 2026-09-25
- [13]dropbear-locomotion (policies, evaluations)github.com/Hyperspawn/dropbear-locomotionchecked 2026-09-25
- [14]v0.1.0 evaluation: 128 trials, 0 fallsgithub.com/Hyperspawn/dropbear-locomotion/blob/main/evaluation/cardinal_0.20_strict_128.jsonchecked 2026-09-25
- [15]dropbear_urdfgithub.com/Hyperspawn/dropbear_urdfchecked 2026-09-25
- [16]dropbear_mjcfgithub.com/Hyperspawn/dropbear_mjcfchecked 2026-09-25
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “Hyperspawn Dropbear specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/hyperspawn/dropbear
Machine-readable: /data.json (record hyperspawn/dropbear).